Modeling the Action-Perception loop and its role in phantom limb pain using active inference
Related Experiment Video
Updated: Nov 3, 2026
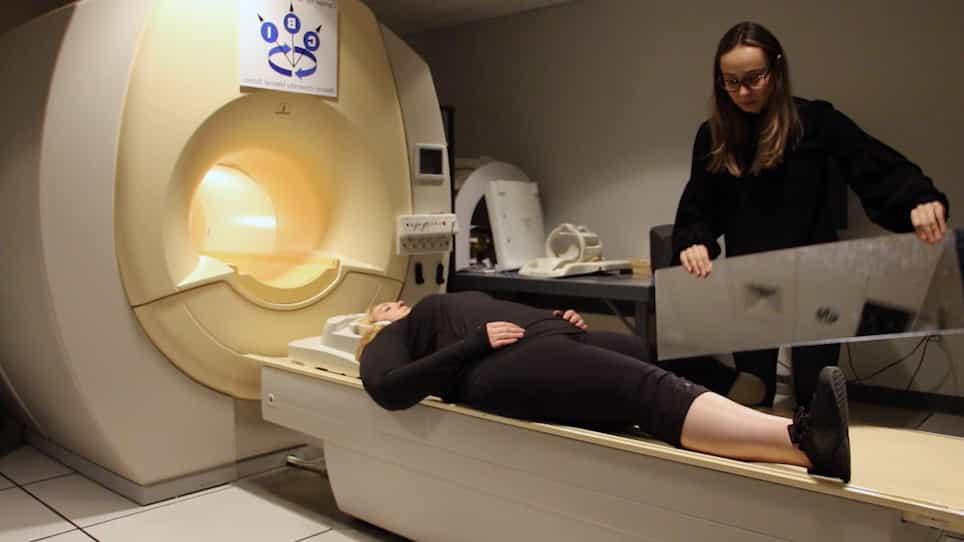
Real-time Video Projection in an MRI for Characterization of Neural Correlates Associated with Mirror Therapy for Phantom Limb Pain
Published on: April 20, 2019
Malin Ramne1, Torbjörn Lundh2, Jon Sensinger3
1Department of Electrical Engineering, Chalmers University of Technology, Gothenburg, Sweden.

Abstract:
Mathematical models grounded in the Bayesian inference framework have been used to describe various aspects of pain perception. However, pain is not only passively inferred but actively shaped through interactions with the environment - a dimension that classical Bayesian approaches typically do not capture. Here, we investigate the role of the action-perception loop in phantom limb pain using a model within the active inference framework, which extends Bayesian inference to include action selection. Despite being one of the most prevalent and distressing consequences of limb amputation, theories regarding the underlying mechanisms of phantom limb pain remain disputed. Because amputation disrupts both sensory input related to the limb and the ability to perform actions, a model incorporating both sensory and active components of pain may provide new mechanistic insight into this condition. The presented model provides a conceptual account of how loss of limb control, ambiguity in sensory input pertaining to limb position, residual noxious input, and pre-amputation pain may contribute to the emergence and persistence of phantom limb pain. Furthermore, the model offers insight into the possible mechanisms underlying common interventions and may help account for their variable efficacy across individuals.