Real-time XR-based 6-DOF catheter tracking enhances cardiac intervention navigation efficiency and depth perception
Related Experiment Video
Updated: Nov 4, 2026
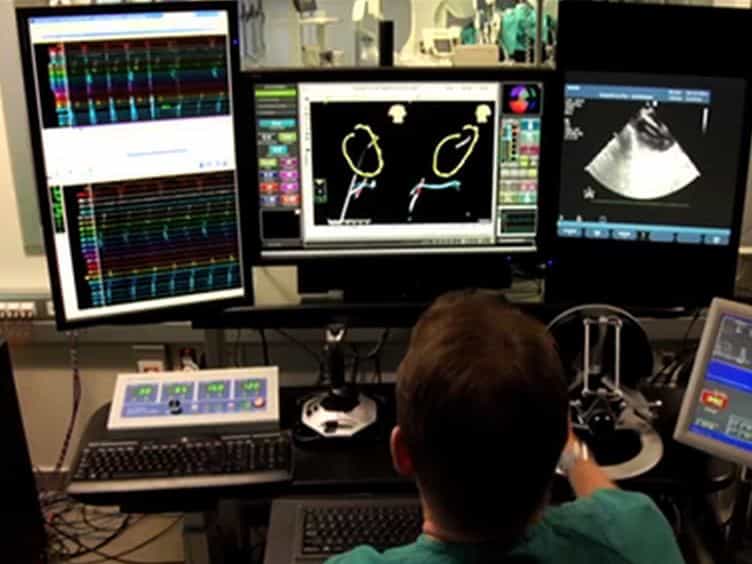
Remote Magnetic Navigation for Accurate, Real-time Catheter Positioning and Ablation in Cardiac Electrophysiology Procedures
Published on: April 21, 2013
Mohsen Annabestani1, Sandhya Sriram2,3, Andrew Kuzemczak1
1Dalio Institute of Cardiovascular Imaging, Department of Radiology, Weill Cornell Medicine, New York, NY, USA.

Abstract:
Despite advances in 3D ultrasound, most percutaneous cardiac interventions still rely on 2D visualization, limiting depth perception and spatial understanding. To address this challenge, we developed an Extended Reality (XR)-based platform that enables real-time six-degree-of-freedom (6-DOF) catheter tracking and visualization within a patient-specific 3D heart model. The system combines a custom machine-vision algorithm for 5-DOF catheter tracking with a 3D-printed electromechanical encoder that measures catheter roll, providing complete 6-DOF motion reconstruction. In a proof-of-concept study, 20 novice medical students navigated an intracardiac echocardiography (ICE) catheter to six anatomical targets using either immersive 3D visualization or a conventional 2D cathlab-style view. Participants in the 3D condition completed the task in 54.6 seconds and traveled 1939 mm on average, compared with 263.5 seconds and 7854 mm in the 2D condition. The ratio of cohort means was 4.8× for completion time and 4.1× for travel length (means of subject-level ratios: 5.1× and 4.9×). The 3D mode also produced more direct and less variable approach trajectories. Participants consistently rated immersive visualization higher for accuracy, speed, usability, and clinical value. Exploratory kinematic analysis suggested that 3D users distributed motion more evenly along the depth axis, whereas 2D users relied more on lateral and vertical adjustments. These findings demonstrate that XR-based visualization can substantially improve procedural training efficiency and motor control.