Closed-loop control of broadband-source-driven resonant fiber-optic gyroscopes using a bipolar digital serrodyne waveform
Related Experiment Video
Updated: Nov 4, 2026
Automation of Mode Locking in a Nonlinear Polarization Rotation Fiber Laser through Output Polarization Measurements
Published on: February 28, 2016
Lingyu Li1, Guochen Wang1, Kaidi Tian1
1School of Instrumentation Science and Engineering, Harbin Institute of Technology, Harbin 150001, China.

Abstract:
Open-loop broadband-source-driven resonant fiber-optic gyroscopes (RFOGs) suffer from a limited dynamic range and scale-factor drift. Conventional serrodyne feedback can improve long-term stability, but its frequency-dependent reset timing may degrade short-term noise performance. This paper proposes a unified closed-loop control method based on a bipolar digital serrodyne waveform. By differentially adjusting the positive and negative phase-ramp slopes, the proposed method simultaneously provides phase modulation and a feedback frequency shift that compensates for the Sagnac shift. Its fixed timing relative to the synchronous-demodulation reference enables gated integration over the stable linear ramp segments, thereby excluding the reset intervals and suppressing the associated transients. Static tests and quasi-rotation calibration are performed using an experimental broadband-source-driven RFOG system. Compared with open-loop operation, the proposed closed-loop scheme maintains comparable short-term performance while reducing the bias instability from 0.09°/h to 0.045°/h. The quasi-rotation calibration results show that the equivalent input range over which the system maintains an approximately linear response is extended from approximately ±50°/s to ±220°/s, while the scale-factor nonlinearity is reduced from approximately 5% to 0.4%. The proposed method simplifies the modulation and control architecture and provides an effective solution for stable closed-loop operation in broadband-source-driven RFOGs.
Related Concept Videos
 01:24
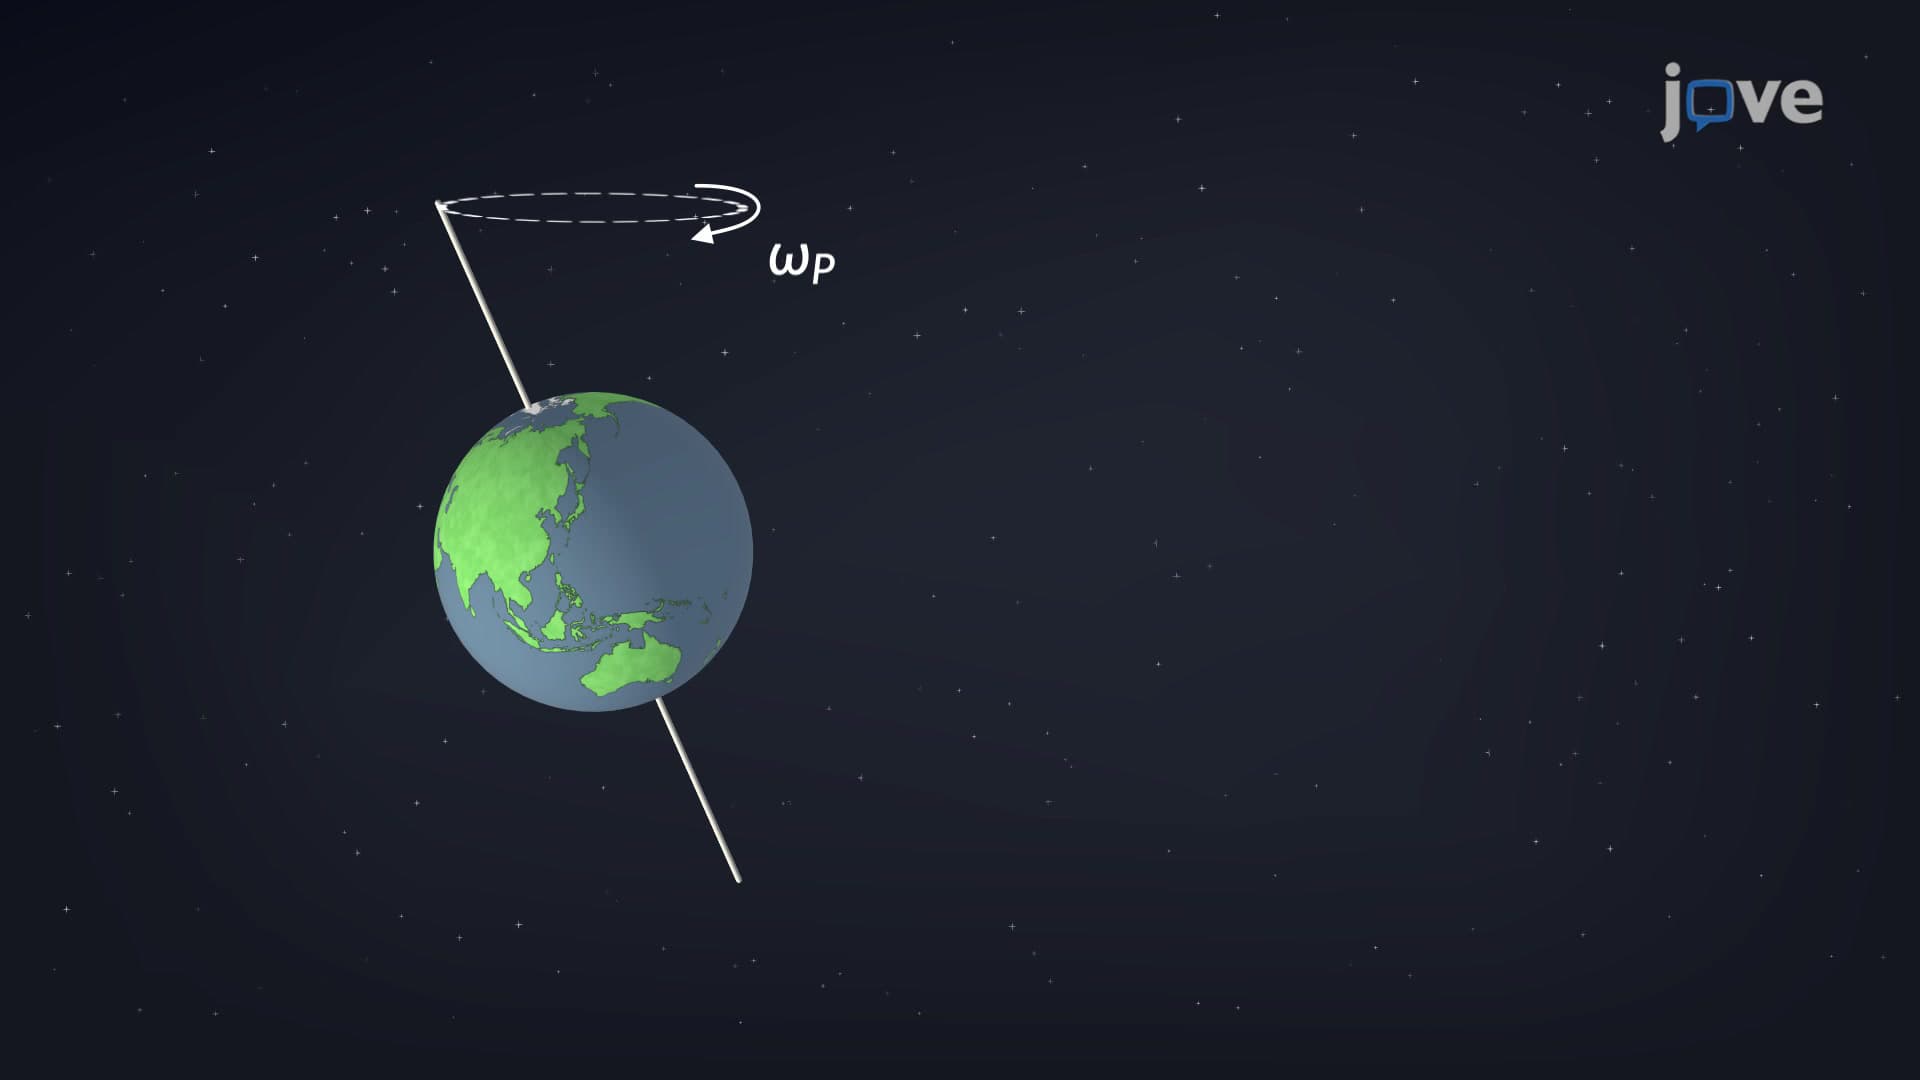
Gyroscope: Precession
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...