Forceps Load During Robot-Assisted Colorectal Surgery Using the da Vinci 5: A Single-Center Analysis of Force Feedback Data
Related Experiment Video
Updated: Nov 7, 2026
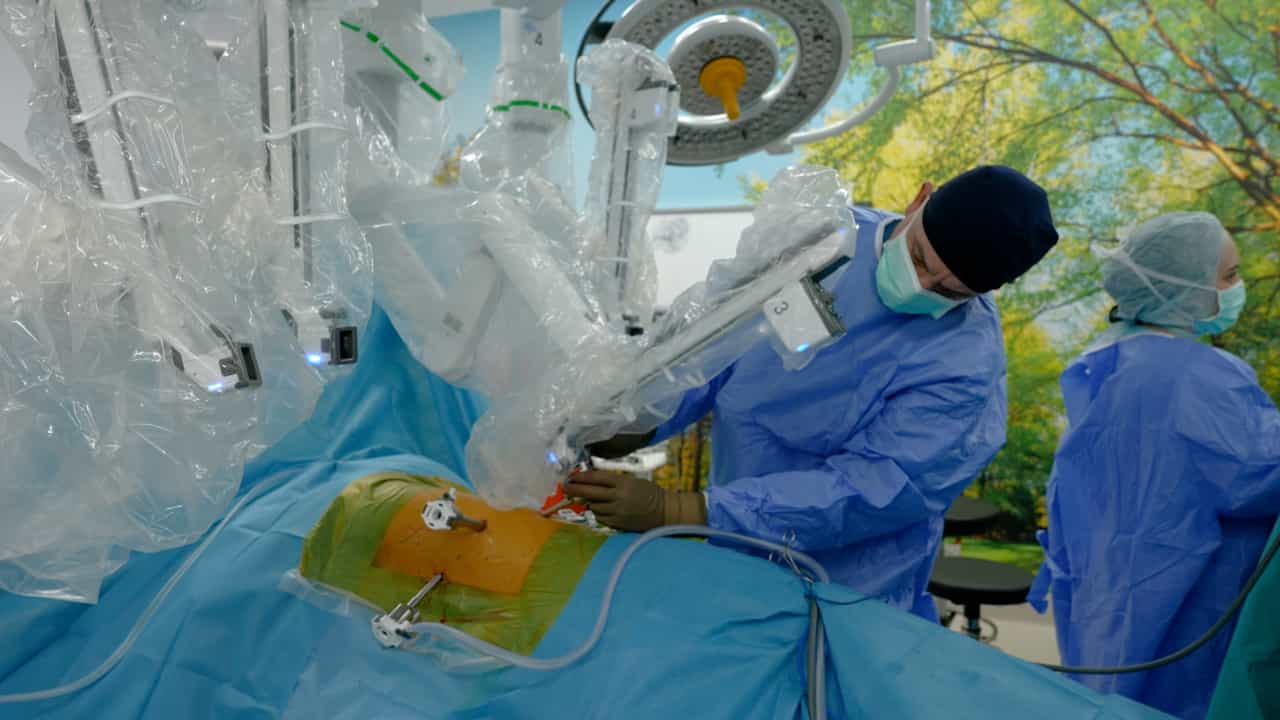
Subcostal Specimen Removal in Completely Portal Robotic Lobectomy
Published on: April 19, 2024
Hidekazu Takahashi1, Ichiro Takemasa1, Satoshi Ishikawa1
1Department of Gastroenterological Surgery, Osaka International Medical and Science Center, Osaka Keisatsu Hospital, Osaka, Japan.

Abstract:
In robotic surgery, surgeons estimate tissue tension based on visual information. However, tactile sensation is essential for surgical manipulation, and its absence may limit surgical performance. Although advances in da Vinci 5 software allow for real-time monitoring of forceps, its clinical significance is not yet clear. The initial analysis of 31 cases performed by skilled surgeons was conducted. Patient factors, short-term outcomes, and oncological factors were obtained from medical records. The mean force applied to each forceps throughout surgery was analyzed. Verification using the least-squares method revealed a correlation between the load applied to the Cadiere forceps on the fourth arm and factors such as sex, body mass index (BMI), and surgical procedures (including right colectomy, left colectomy, and rectal resection), with a correlation coefficient R2 = 0.64, and an adjusted R-square value of 0.58. This study may serve as the first step toward quantifying the loads applied to forceps during robot-assisted surgery and identifying correlations with surgical procedures and patient factors.
Related Concept Videos
 01:30
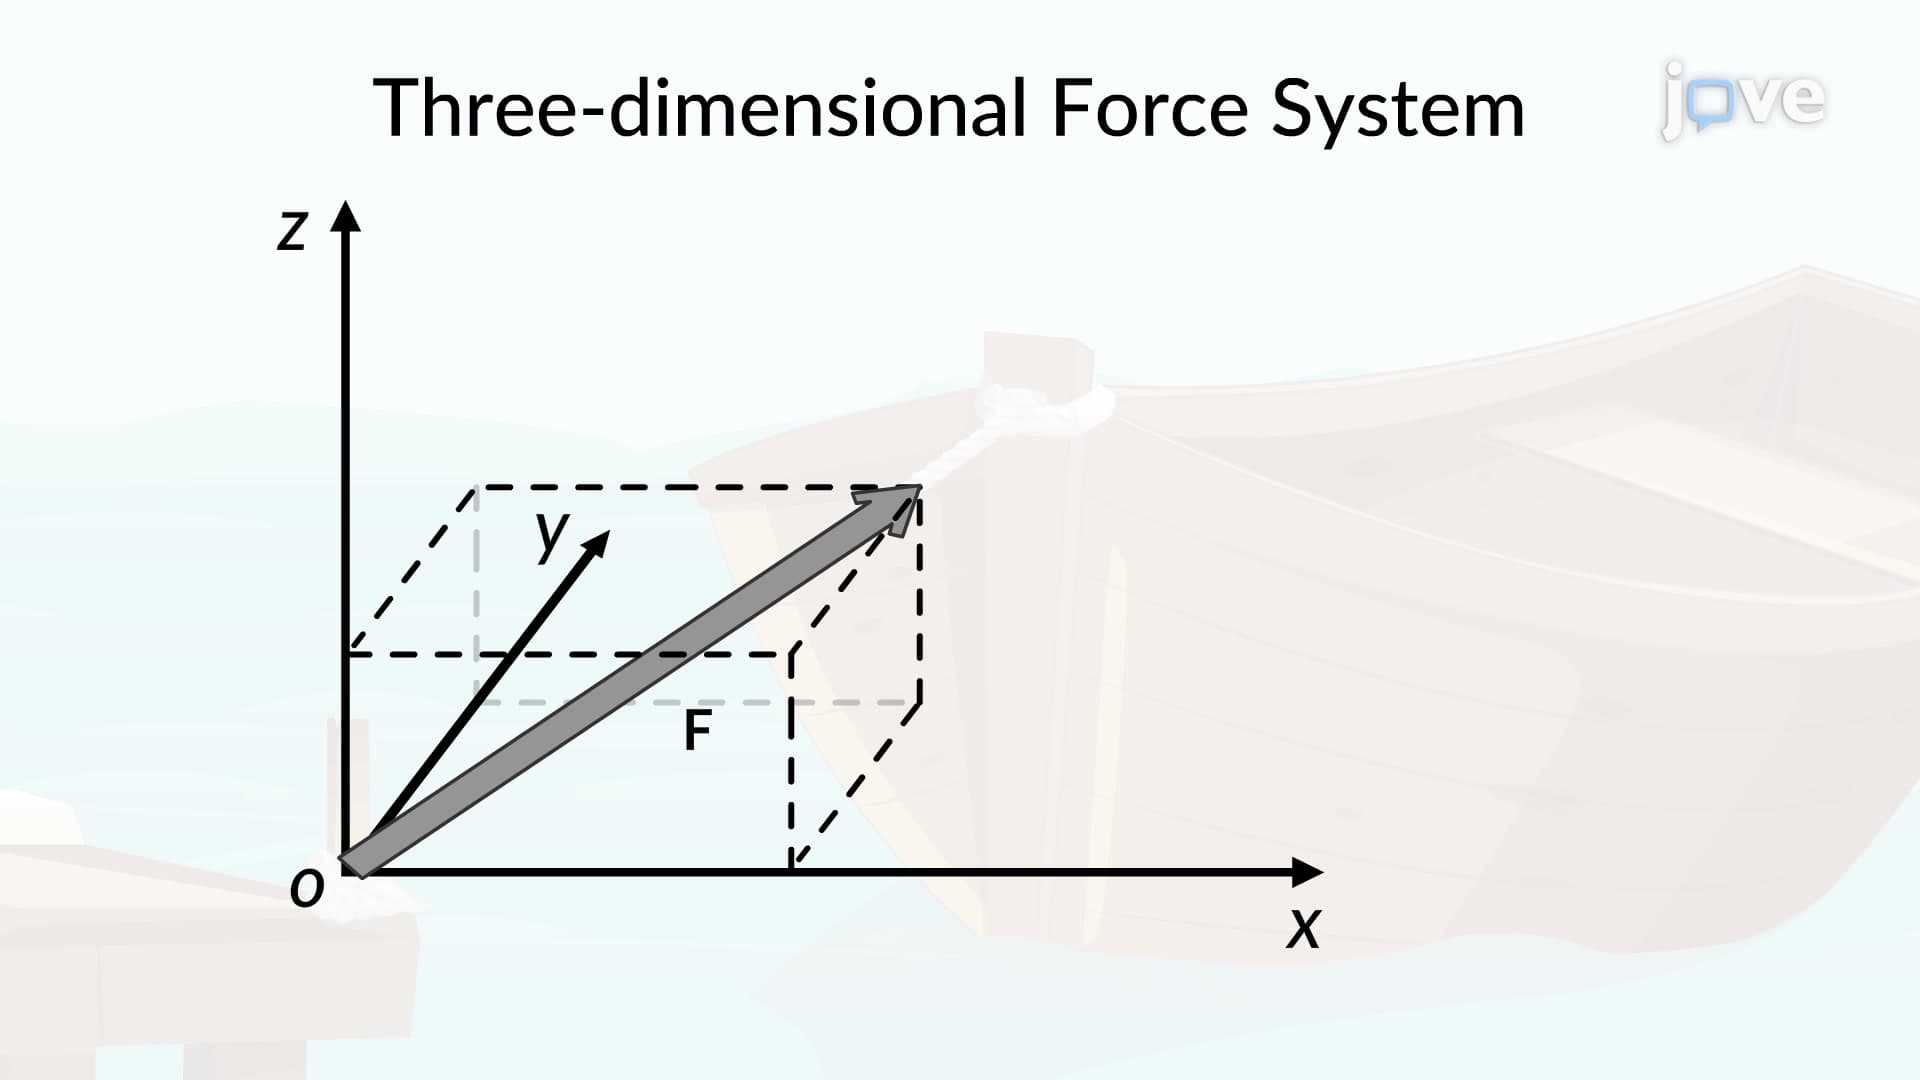
Three-Dimensional Force System
 01:26
Endoscopic Studies II: Thoracocentesis
Description
Excess pleural fluid or air may accumulate in some respiratory disorders in the thoracic cavity. To treat pleural effusion, a physician conducts thoracentesis by carefully piercing the chest wall and entering...