Modeling and controlling a half-car model suspension system using an ANFIS controller
Related Experiment Video
Updated: Nov 7, 2026
Structural Design and Manufacturing of a Cruiser Class Solar Vehicle
Published on: January 30, 2019
Sisay Ewunetie Fisha1, Amanuel Gebisa Aga2, Tatek Mamo Wachamo1
1Department of Motor Vehicle Engineering, Engineering College, Ethiopian Defence University, Bishoftu, Ethiopia.

Abstract:
Passive suspension systems (PSS) use fixed spring and damping characteristics and cannot adapt to changing road disturbances and operating conditions. Active suspension systems (ASS) address this limitation by generating additional control forces, but controller design must balance ride comfort, road holding, model uncertainty, and control effort. This study develops a four-degree-of-freedom (4-DOF) longitudinal half-car model and evaluates an Adaptive Neuro-Fuzzy Inference System (ANFIS) controller against PSS and PID-controlled ASS under double-bump and ISO-classified random Type A and Type C Road profiles at 10 and 20 m/s. The ANFIS controller is trained using PID-generated input-output data with two inputs, five Gaussian membership functions per input, 25 Takagi-Sugeno rules, and 150 training epochs. For the double-bump case at 10 m/s, ANFIS reduces body vertical displacement from 0.0435 to 0.0084 m (80.6%), vertical acceleration from 2.40 to 0.77 m/s2 (67.9%), and front suspension travel from 0.0652 to 0.0090 m (86.2%) relative to PSS. Compared with PID, the corresponding reductions are 53.6%, 49.3%, and 43.8%, respectively. Settling time is reduced by 38.8% for body vertical displacement and 38.6% for pitch acceleration relative to PSS. The result meets all the qualifications for riding comfort of the ISO 2631 standard. The study identifies limitations related to PID-supervised training, linear modeling, and actuator-energy assessment by employing simulation. Experimental evaluation is required to establish robustness to parameter uncertainty, sensor noise, actuator delay, and implementation energy requirements.

Related Concept Videos
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:20
Second Order systems I
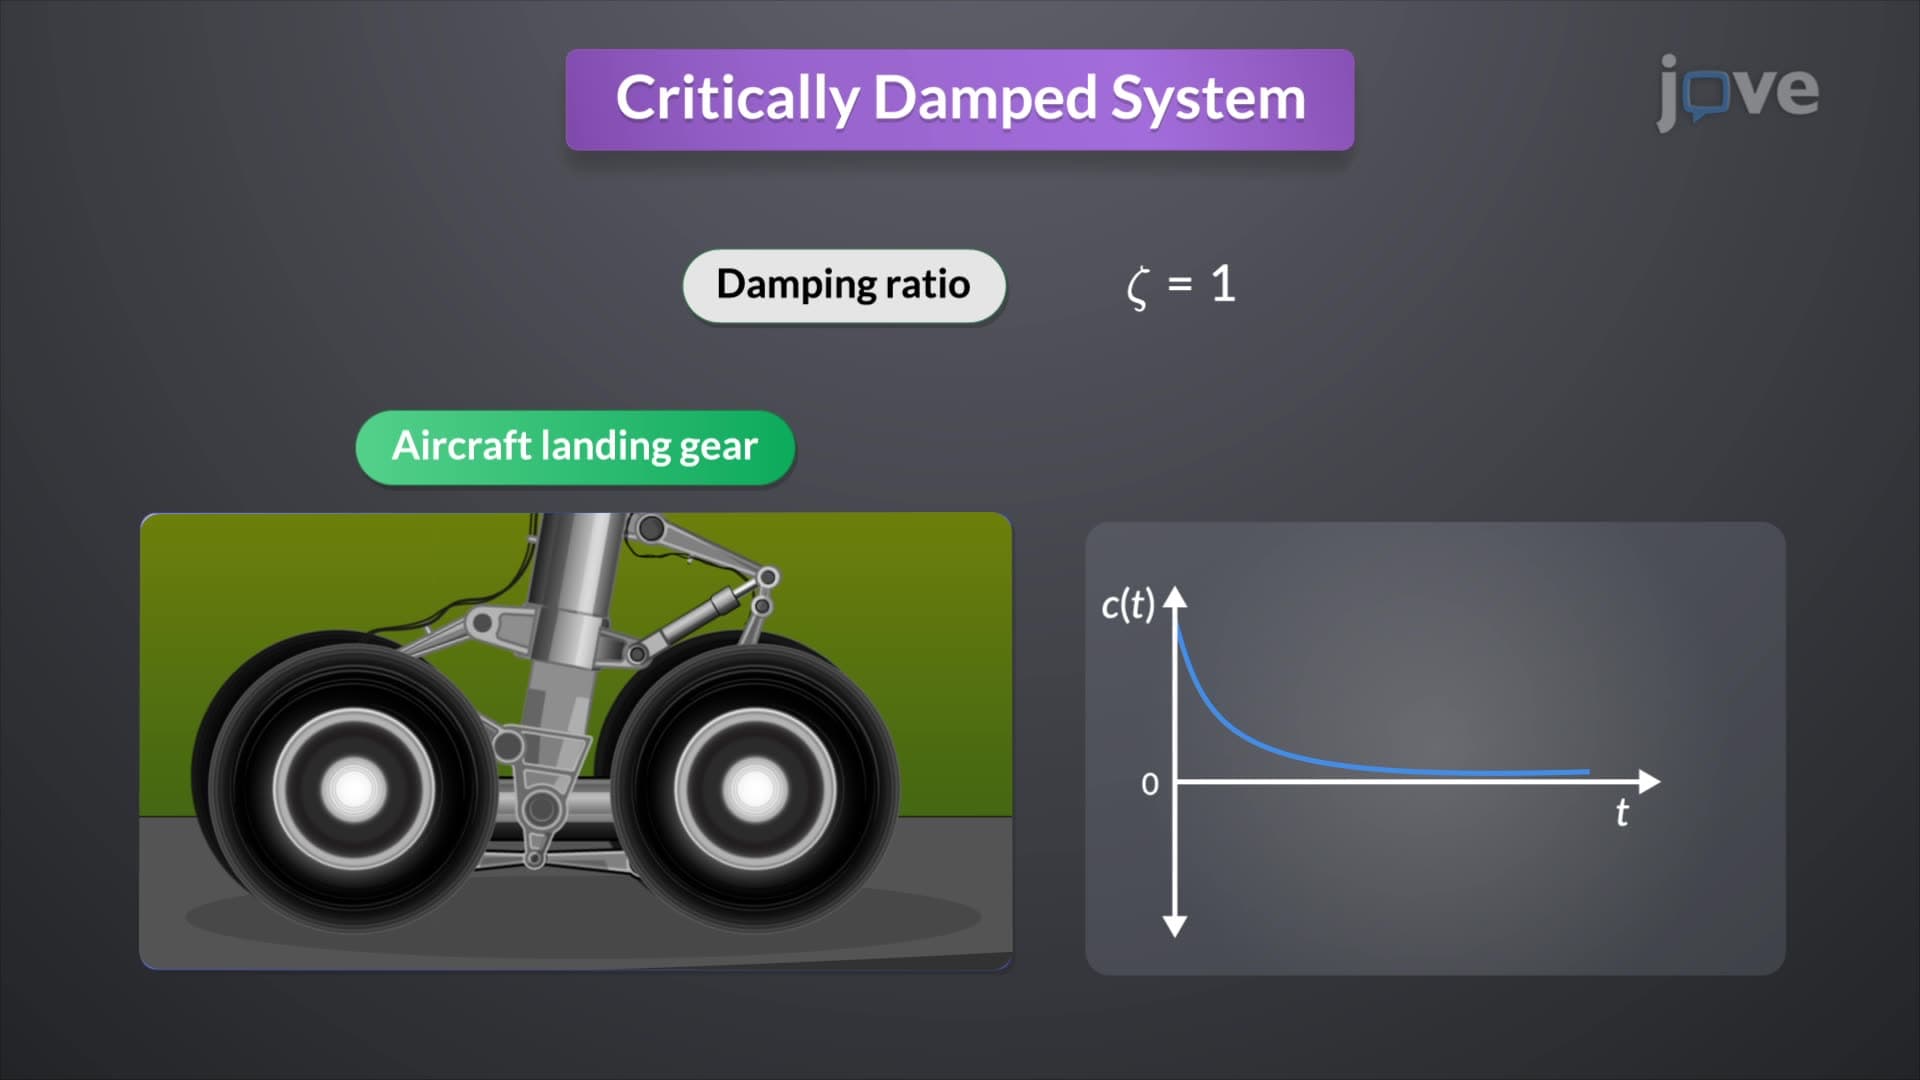
By reinterpreting the system, one can derive the closed-loop transfer function, which...