Mamba-FETrack V2: Revisiting state space model for frame-event based visual object tracking
Related Experiment Video
Updated: Nov 7, 2026
Utilizing vmTracking to Improve the Accuracy of Multi-Animal Pose Estimation in Rodent Social Behavior Studies
Published on: November 7, 2025
Shiao Wang1, Ju Huang1, Qingchuan Ma2
1School of Computer Science and Technology, Anhui University, Hefei, 230601, China.

Abstract:
Combining traditional RGB cameras with bio-inspired event cameras for robust object tracking has garnered increasing attention in recent years. However, most existing multimodal RGB-Event tracking algorithms depend heavily on high-complexity Vision Transformer architectures for feature extraction and fusion across modalities. This not only leads to substantial computational overhead but also limits the effectiveness of cross-modal interactions. In this paper, we propose an effective RGB-Event object tracking framework based on the linear-complexity Vision Mamba network, termed Mamba-FETrack V2. Specifically, we first design a lightweight Prompt Generator that utilizes embedded features from each modality, together with a shared prompt pool, to dynamically generate modality-specific learnable prompt vectors. These prompts, along with the modality-specific embedded features, are then fed into a Vision Mamba-based FEMamba backbone, which facilitates prompt-guided feature extraction, cross-modal interaction, and fusion in a unified manner. Finally, the fused representations are passed to the tracking head for accurate target localization. Extensive experimental evaluations on multiple RGB-Event tracking benchmarks, including short-term COESOT dataset and long-term datasets, i.e., FE108 and FELT, demonstrate the superior performance of the proposed tracking framework. The source code and pre-trained models will be released on https://github.com/Event-AHU/Mamba_FETrack.
Related Concept Videos
 01:26
Frames: Problem Solving II
 01:24
Frames: Problem Solving I
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
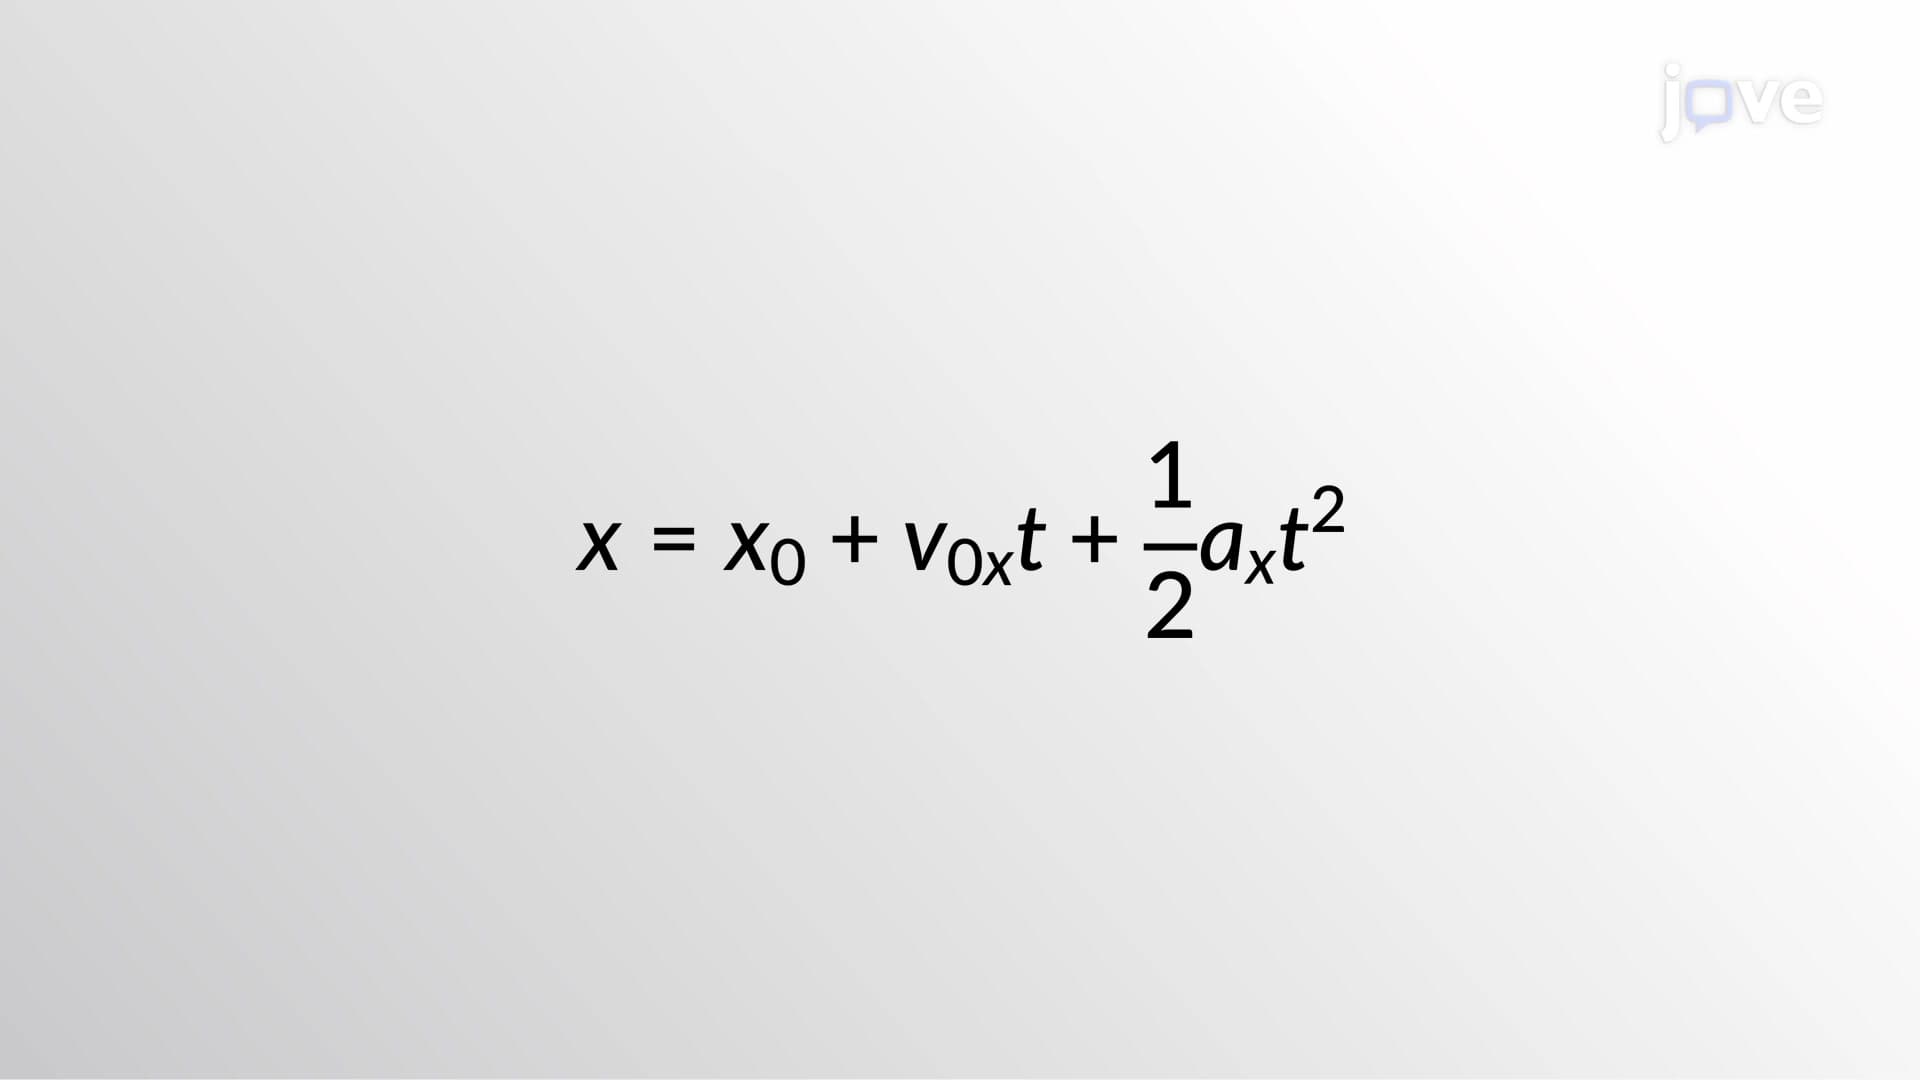 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...