A theory of noisy linear recurrent neural network learning dynamics
Related Experiment Videos

Abstract:
Biological neural networks are noisy: their dynamics involve difficult-to-predict fluctuations which are likely due not just to chaos, but also to a variety of low-level biophysical processes. Despite the omnipresence of intrinsic noise, its theoretical consequences are incompletely understood, especially in the context of learning. For example, does noise meaningfully shape representation learning, or is it better viewed as a nuisance factor whose presence or absence changes little about what solution is found and when? Here, we argue that intrinsic noise can significantly modulate representation learning in recurrent neural networks (RNNs), since it can strongly break solution-space degeneracies and in some cases control whether a non-degenerate solution exists at all. We show that this is true for an analytically tractable model of noisy RNN learning with a linear activation function and white noise inputs. We find that, in the so-called rich regime (where weights are initialized with small values), noise strongly modulates the directions in which the read-in, readout, and recurrent weights align. Moreover, we find that noise produces a kind of phase transition: for sufficiently high noise, a non-degenerate solution is not even optimal if parameter scales are limited (e.g., via regularization). These results extend recent analytic work on RNN representation learning and show that noise can act as a fundamental determinant of representations.
Related Concept Videos
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:26
Classification of Systems-I
Homogeneity dictates that if an input x(t) is multiplied by a constant c, the output y(t) is multiplied by the same constant. Mathematically, this is expressed as:
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
 01:30
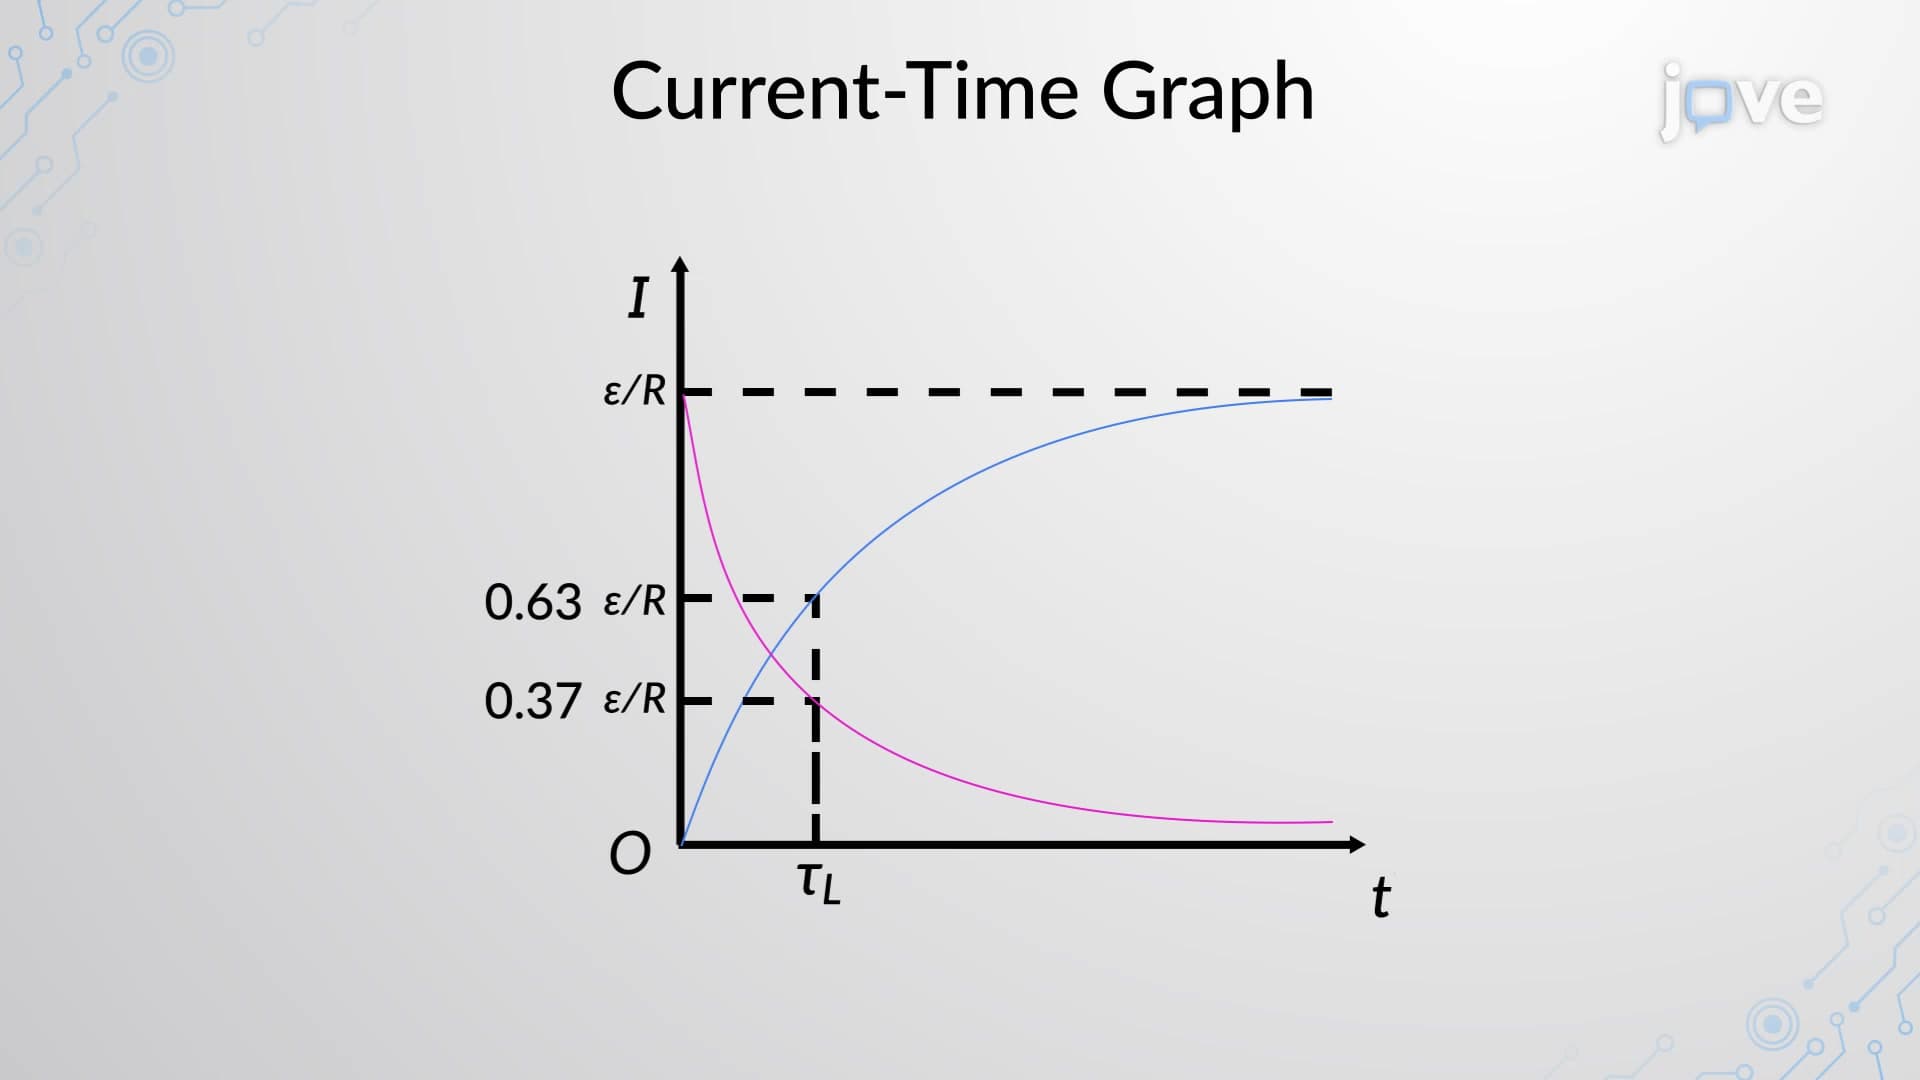
Current Growth And Decay In RL Circuits
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:18
Second Order systems II
If ζ...