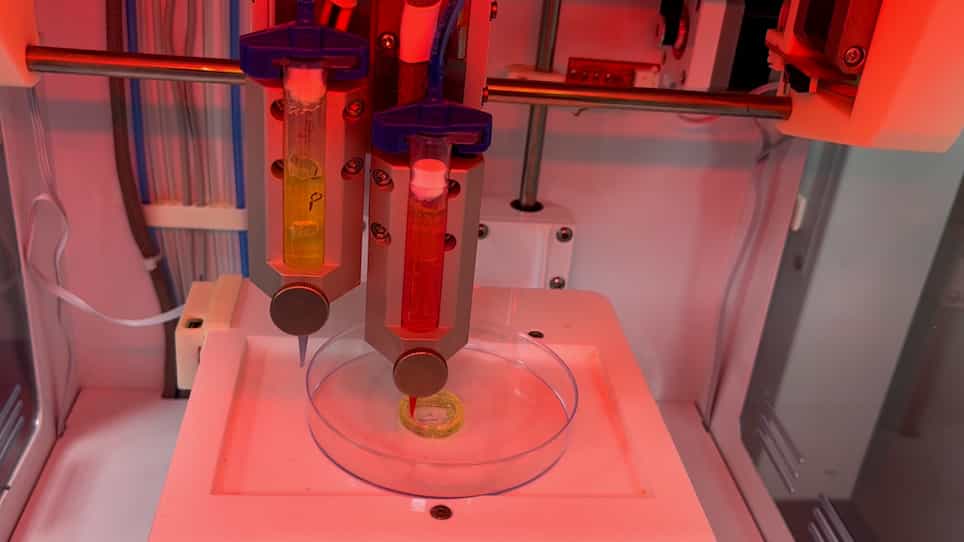
Controlled crosslink cleavage and phase separation enable highly stretchable and strong 3D-printed hydrogel for soft robotics
Related Experiment Video
Updated: Nov 12, 2026
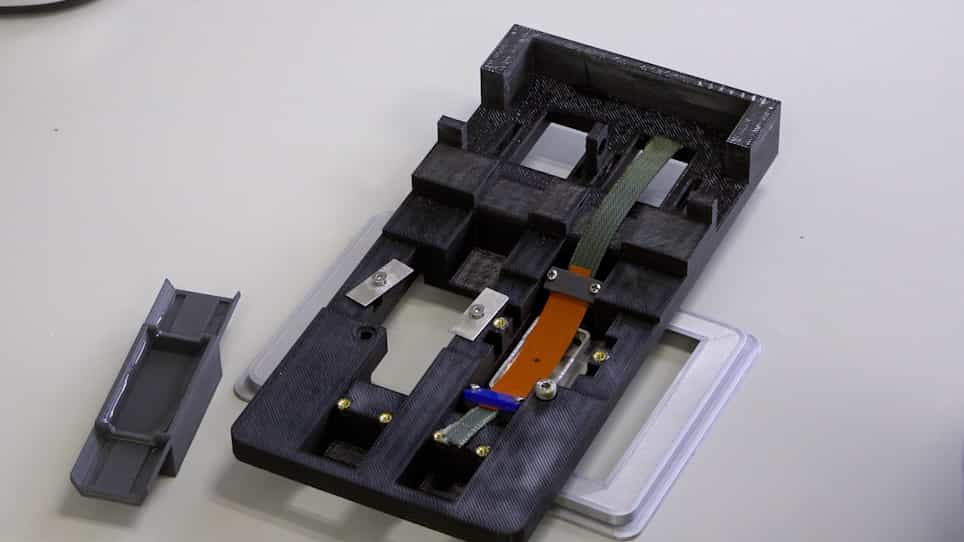
Controlled Strain of 3D Hydrogels under Live Microscopy Imaging
Published on: December 4, 2020
Liangshen Zhao1, Jianrong Cai1, Qilin Qian1
1School of Biomedical Engineering, Shanghai Jiao Tong University, Shanghai, China.

Abstract:
Soft robots operate safely in delicate, confined environments and require materials that combine softness and large deformation in complex architectures. Digital light processing (DLP) 3D printing enables such structures, but rapid curing fixes networks with short strands, limiting extensibility of printed hydrogels. Here we report a controlled post-print decrosslinking strategy that decouples shape fixation from network maturation to yield highly stretchable, strong DLP-printed hydrogels. In this design, photo-triggered, base-cleavable coupling between o-nitrobenzyl acetal and (meth)acrylate groups establishes a dense network for printing and shape fixation. Subsequent alkaline cleavage restores chain mobility and lengthens network strands, while hydrophobic side-group modification induces phase-separated domains that enhance strength. The resulting hydrogels reach 1100% strain at break and 3.7 MPa tensile strength, combining high stretchability with high strength. This performance enables pneumatic actuators with 8-fold volumetric expansion and payload transport in confined fluidic environments. Our strategy provides a soft material platform for 3D-printed soft robotic systems requiring large, reversible deformation.