Related Experiment Video
Updated: Oct 17, 2026
Four-Dimensional CT Analysis Using Sequential 3D-3D Registration
Published on: November 23, 2019
Tomographic localization of motion axes

Abstract:
Localization of motion axes within joints and junctures in living humans has been carried out by means of roentgen stereophotogrammetry. Another technique is presented here, in which the localization of the axis is carried out by means of tomography. The field of application for this technique has been examined in a series of phantom experiments. It may be employed in certain situations where roentgen stereophotogrammetry is not useful. No other equipment is needed than a pluridirectional tomograph and conventional dark-room facilities.
More Related Videos
 07:43
In Vivo Quantification of Hip Arthrokinematics during Dynamic Weight-bearing Activities using Dual Fluoroscopy
Published on: July 2, 2021
 05:41
Synchronous Triplanar Reconstruction Integrated with Color Doppler Mapping for Precise and Rapid Localization of Thyroid Lesions
Published on: February 9, 2024
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:15
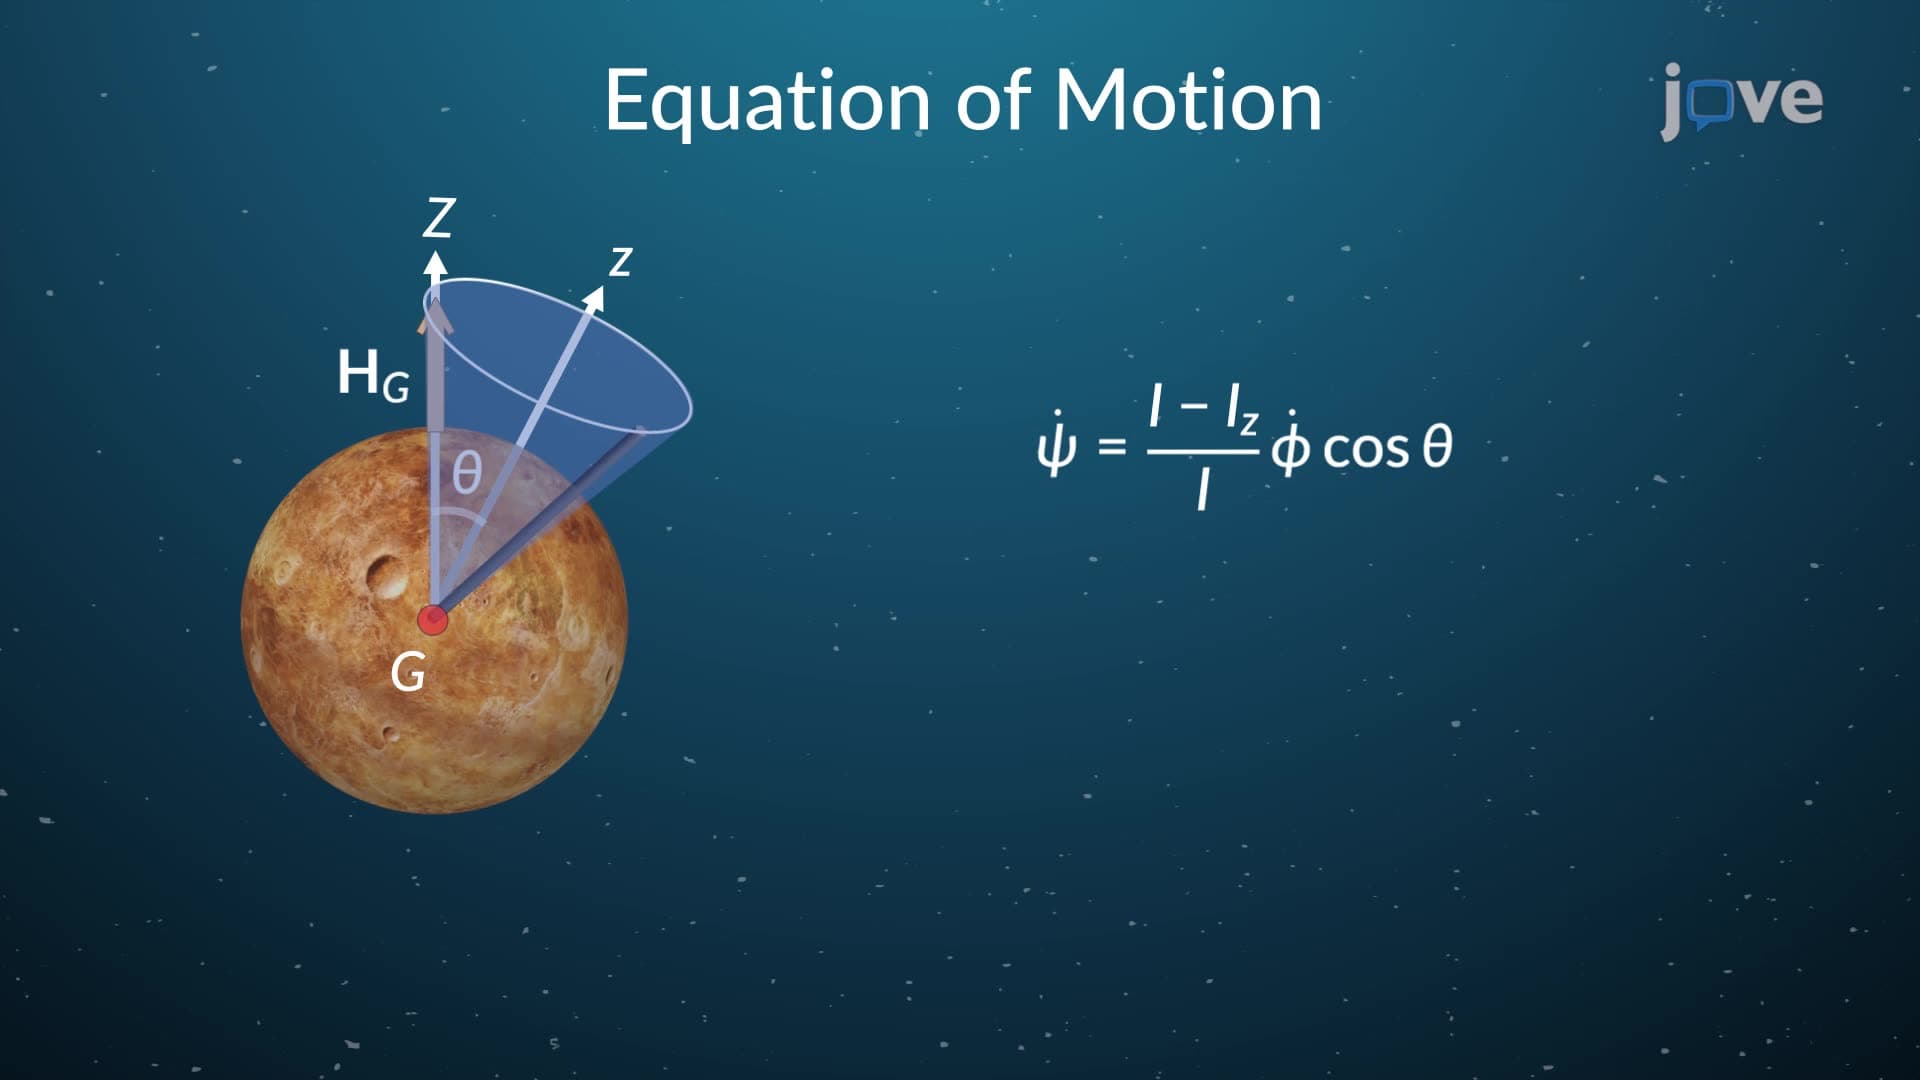
Torque Free Motion
 01:27
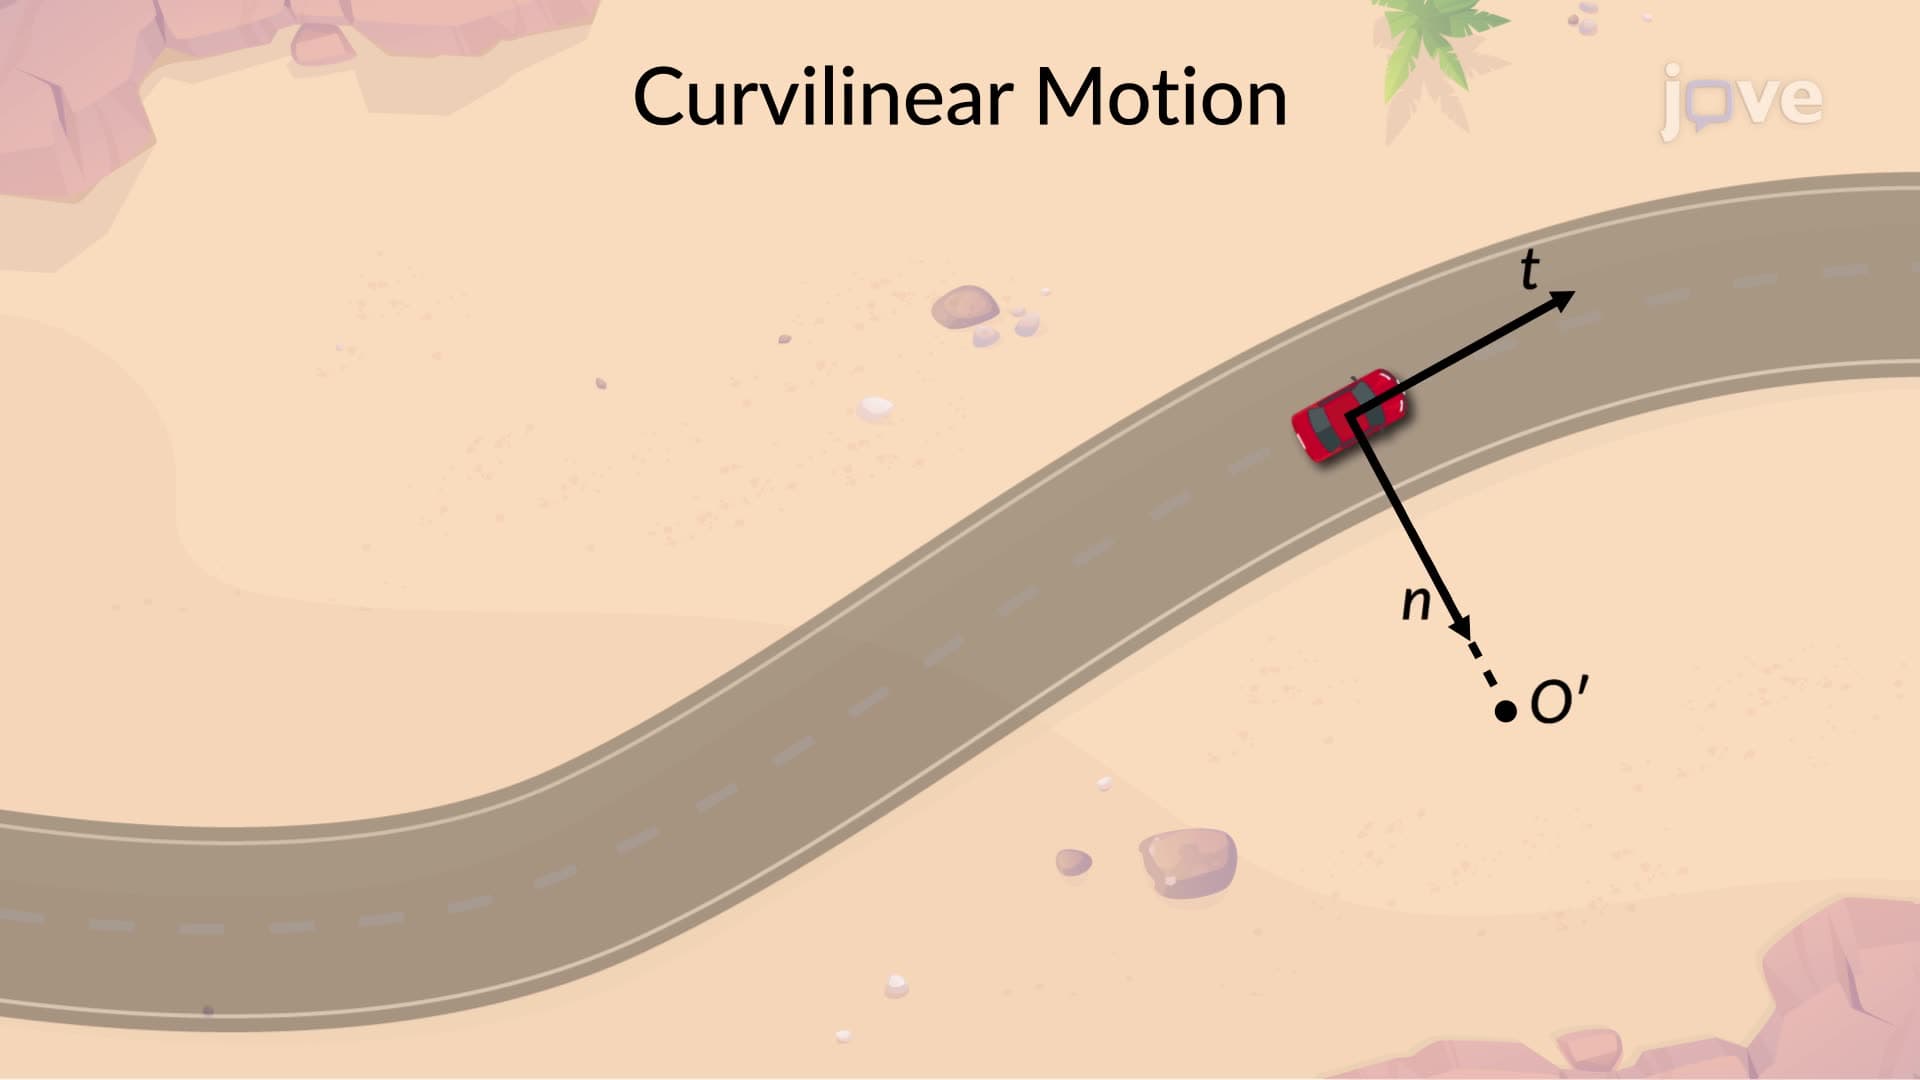
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...