Related Experiment Video
Updated: Sep 22, 2026
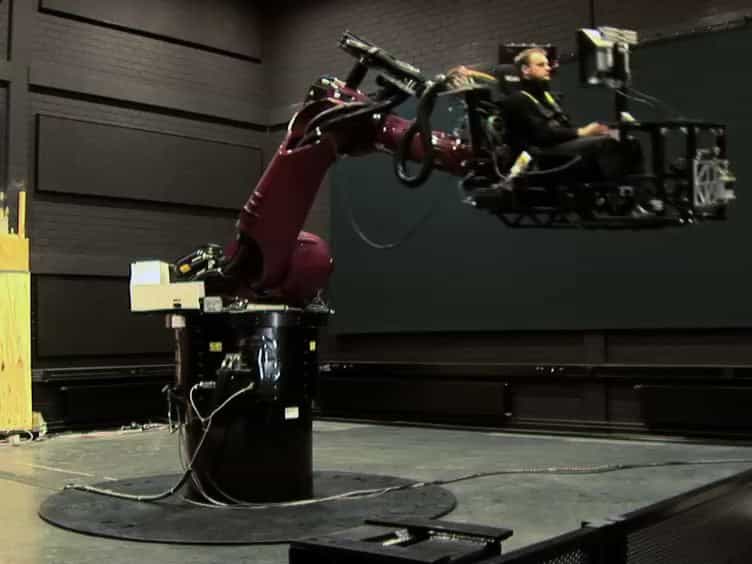
MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
A computational aspect of kinetic depth effect

Abstract:
A method is proposed to determine the rigid structure as well as the three dimensional motion of an object from a sequence of orthographically projected images. It is assumed that the velocities as well as the positions of the points attached to the object are observable in the images. The "instantaneous rigidity condition" wich states that the relative position vector between any two points is orthogonal to the corresponding relative velocity vector is derived from the condition of rigidity. Assuming further that the rotational velocity component is constant throughout the period of observation, each of the projected relative velocity vectors is shown to move along one of the elliptical trajectories, all of which are similar to one another. The orientations of the longer axes are common to every trajectory. Then one can determine the equations of the ellipses by observing only two points in three views or three points in two views. The solution is obtained from a set of linear equations. The length of the longer axis enables one to determine the relative velocity. The instantaneous rigidity condition is then used to obtain the relative position. The special cases where the rotational axis is either perpendicular to or parallel with the image plane are discussed. The above results are discussed in relation to the relevant psychophysical observations as well as theoretical studies.

Related Concept Videos
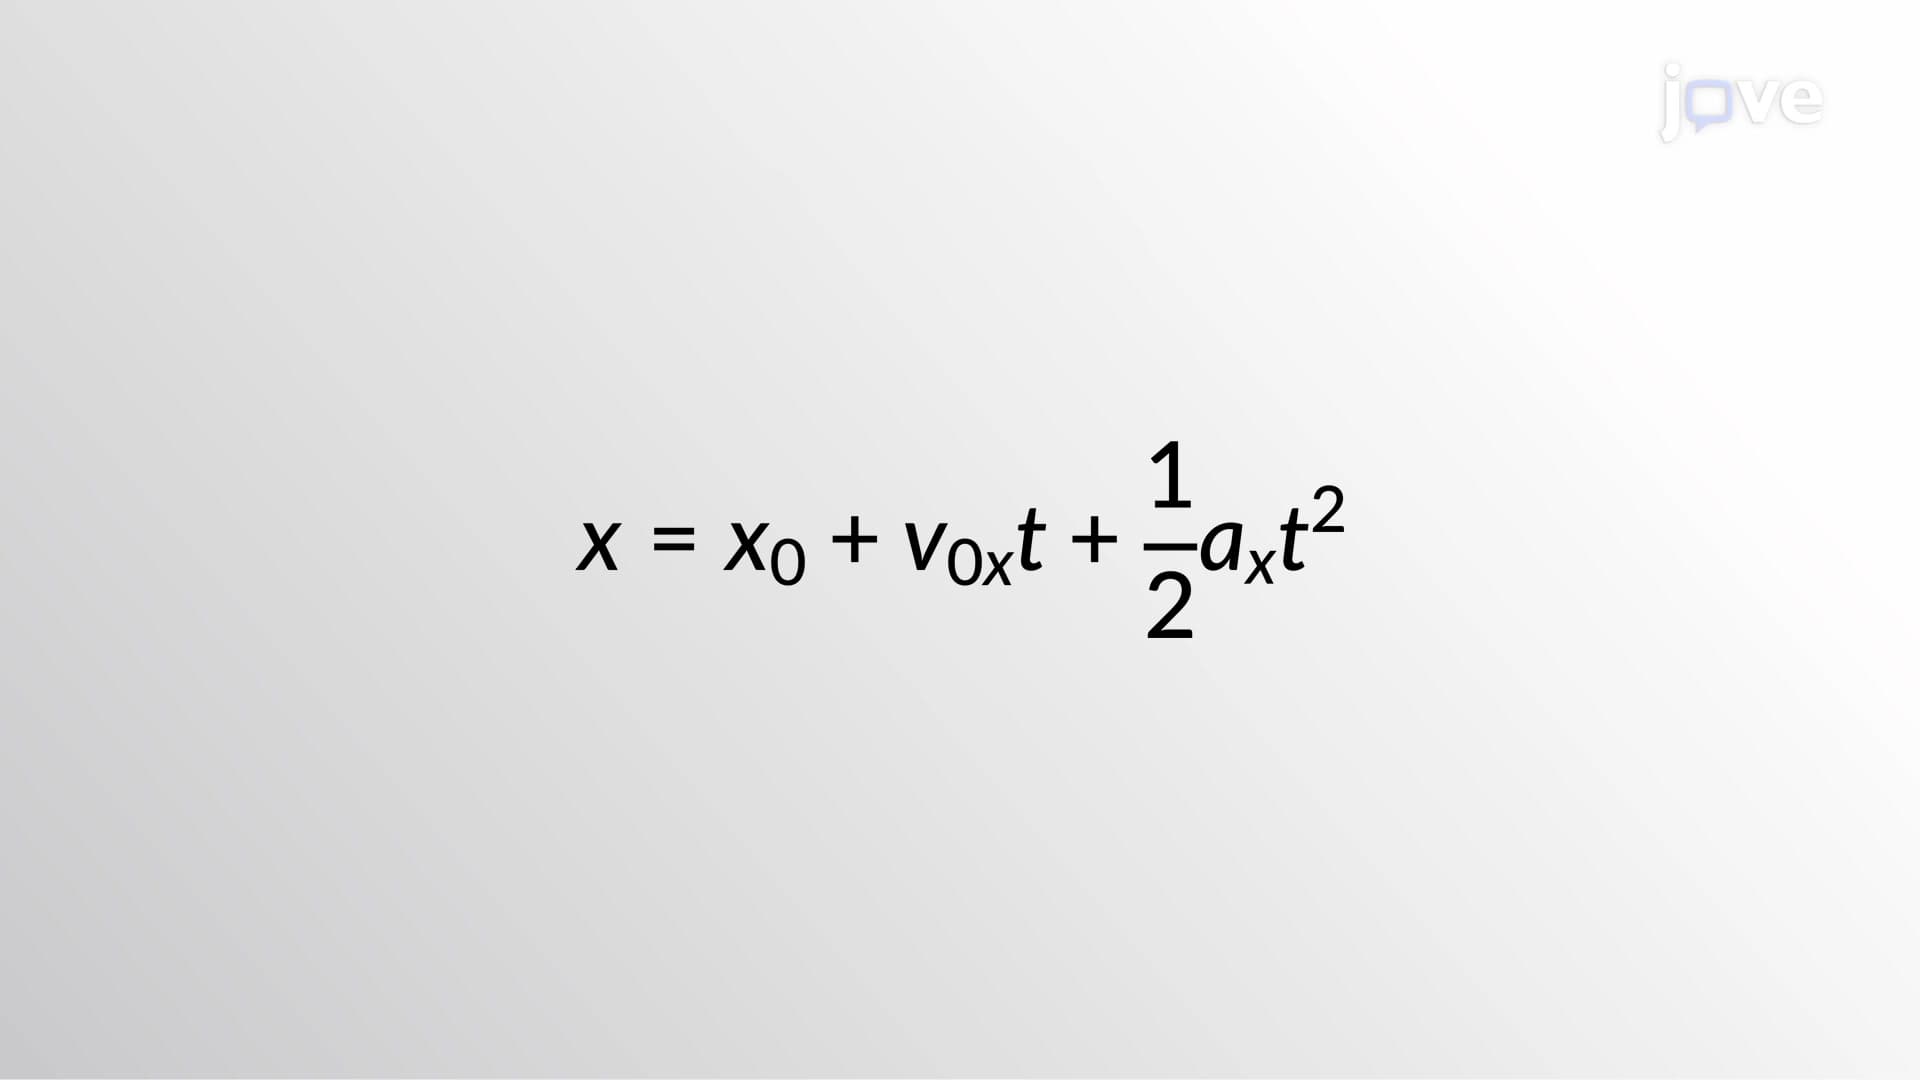 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:26
Kinetic Friction
 01:13
Kinetic Energy for a Rigid Body
 01:15
Depth Perception and Spatial Vision
 01:27
Uniform Depth Channel Flow
 01:18
Uniform Depth Channel Flow: Problem Solving