Related Experiment Video
Updated: Aug 15, 2026
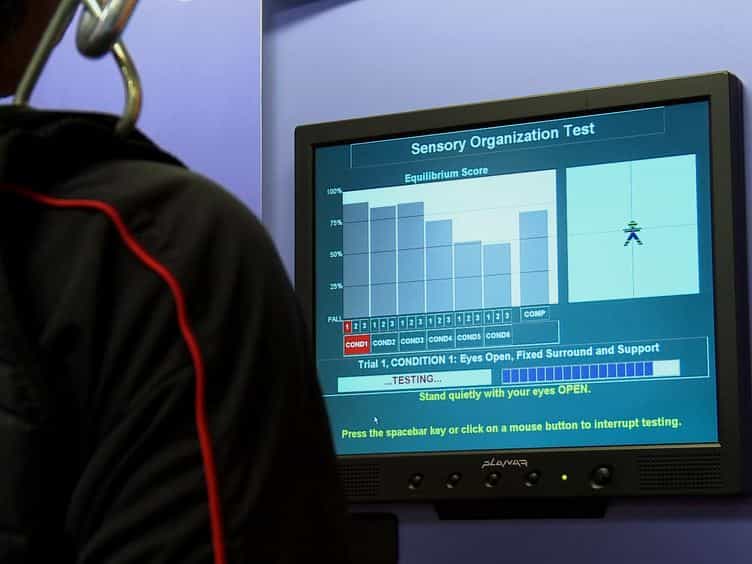
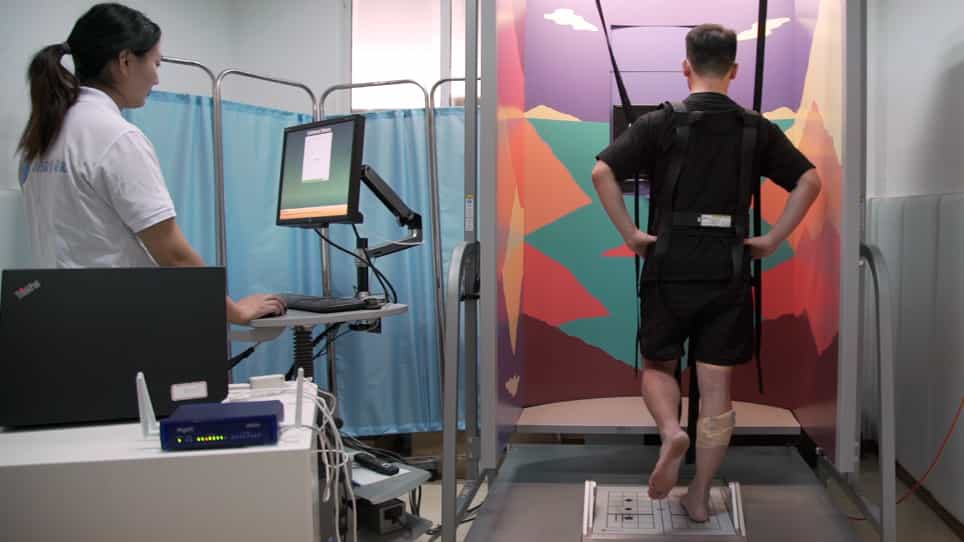
Computerized Dynamic Posturography for Postural Control Assessment in Patients with Intermittent Claudication
Published on: December 11, 2013
Optimal and adaptive control in canine postural regulation

Abstract:
For analytic purposes, dogs trained to stand quietly on an oscillating platform can be likened to a fixed-length inverted pendulum with a point mass. Describing function analysis permitted derivation of torque and error values as functions of phase and gain relative to platform movement. A phase criterion was determined for minimization of either control torque at a given error amplitude or error at a given control torque amplitude. Describing functions for dogs with and without vision approached optimal phase. Stretch reflex control involving proportional-plus-rate feedback is not sufficient to account for the approach to optimal phase. Blindfolded labyrinthectomized dogs did not exhibit optimal behavior and the phase constraint for stretch reflex control was satisfied at most frequencies. The observed behavior is best accounted for by a model involving both otolith and visual feedforward (pursuit-precognitive) control processes. Reductions in phase lag by blindfolded dogs during the first few cycles of platform motion provide evidence of adaptive control.

Related Concept Videos
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:22
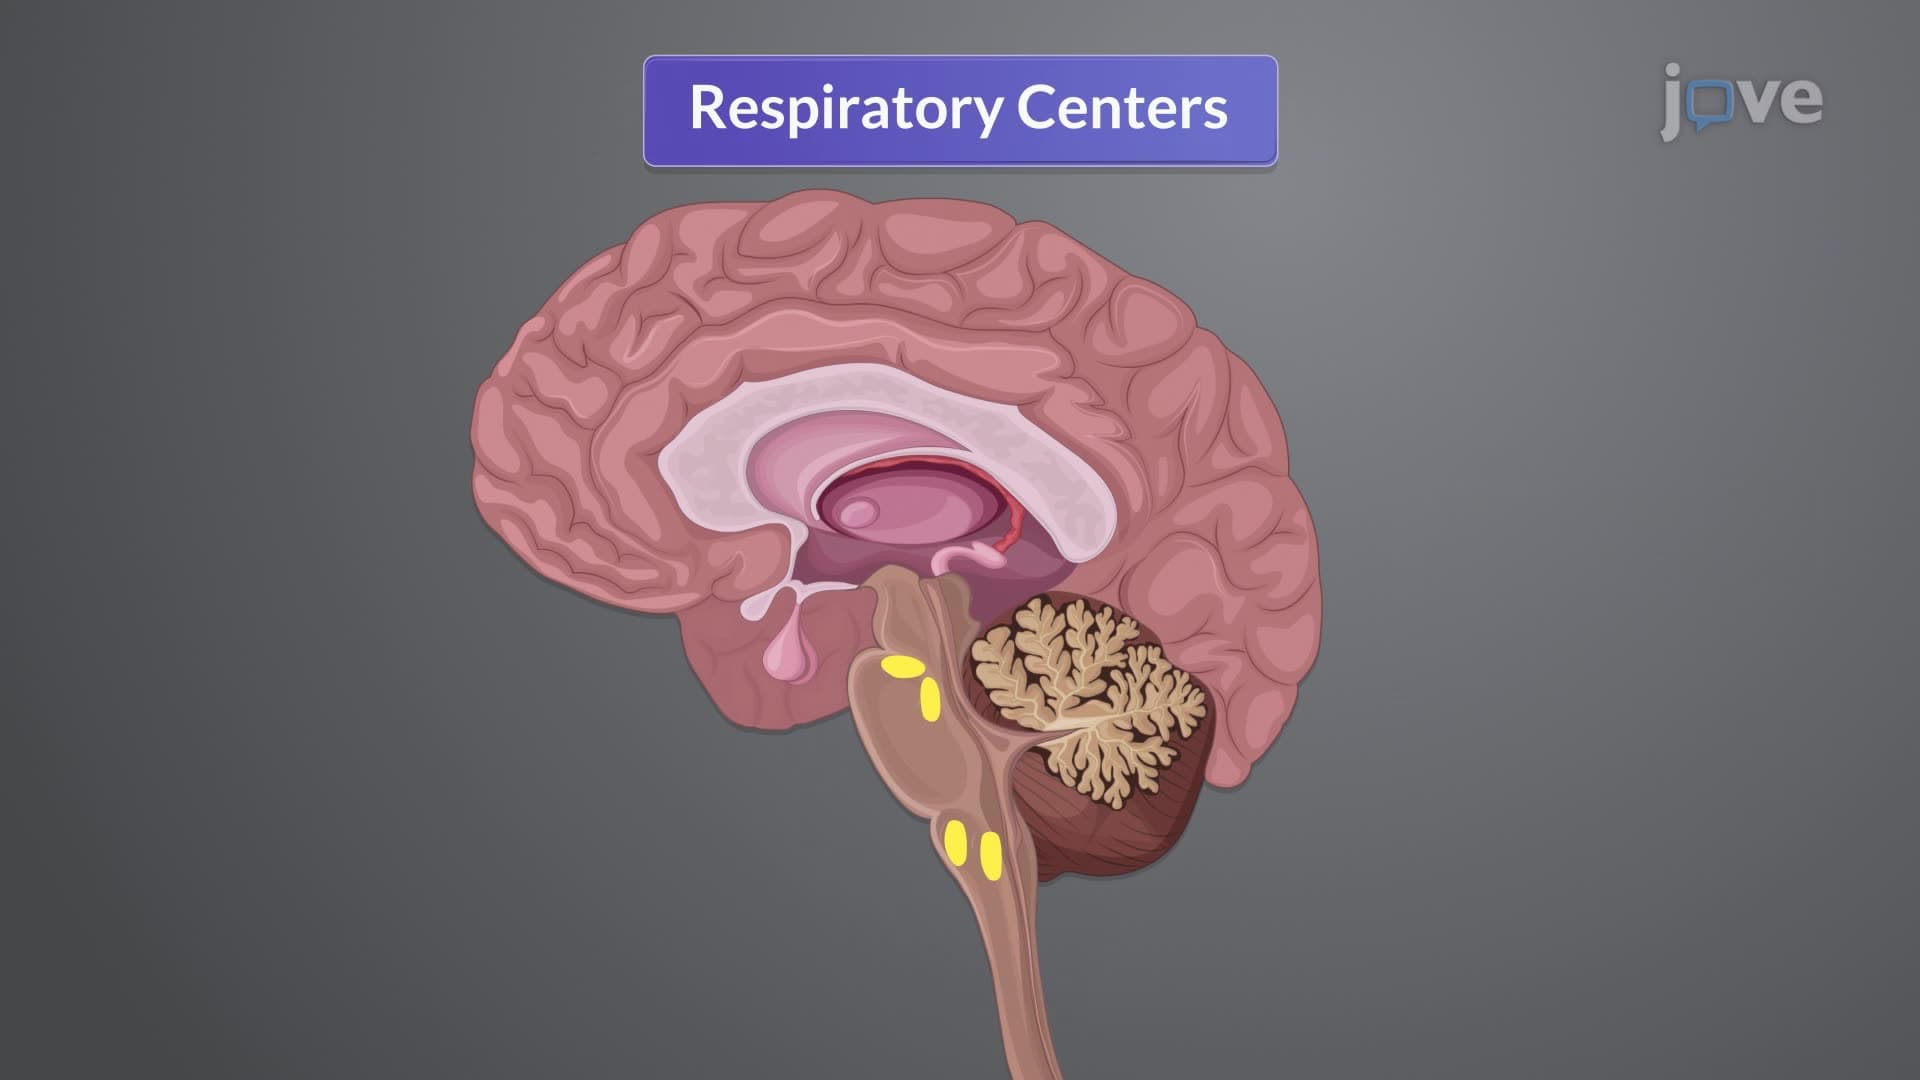
Physiology of Respiration II: Neurogenic Control of Respiration
Central Control
The brainstem is the primary site of central control, hosting respiratory centers: