Related Experiment Video
Updated: Aug 19, 2026
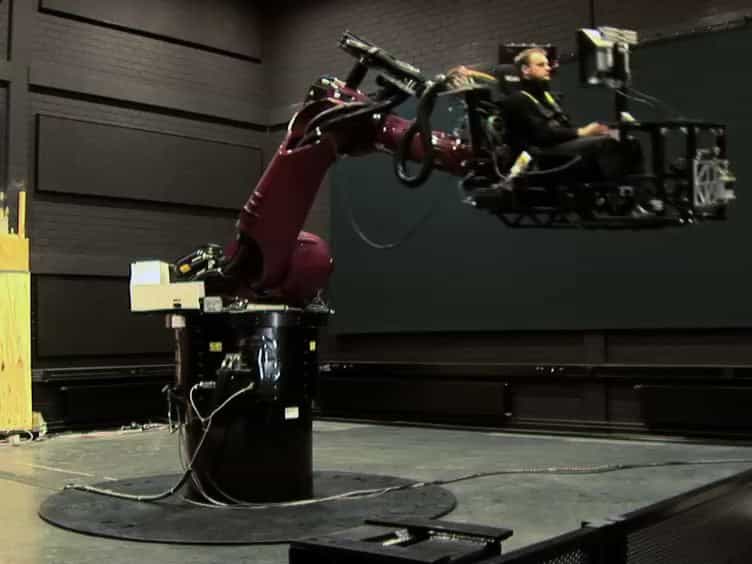

MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
The contribution of motion, the visual frame, and visual polarity to sensations of body tilt
1Human Performance in Space Laboratory, York University, Ontario, Canada.

Abstract:
Three types of visual information contribute to the sense of self orientation with respect to gravity: visual polarity of objects with a distinct top and bottom, the principal vertical and horizontal lines of the visual environment, and visual motion. Three visual displays were designed to investigate the contribution of each visual feature to illusory self tilt: a large sphere lined with dots, a cubic room lined with dots, and a furnished room with floor and ceiling. In experiment 1 the dotted room and the furnished room were tilted to various angles about the roll axis of the erect subject who set a visual line and an unseen rod to the apparent vertical. In the dotted room, settings were made either with respect to the nearest surface to the horizontal or with respect to the nearest diagonal of the room. In the furnished room, settings were made with respect to the nearest horizontal wall but not with respect to diagonals. In experiment 2 each of the three displays was rotated at constant velocity and subjects' responses were classified into four categories: illusory self tilt at a constant angle, alternating self tilt with the body becoming erect each time a surface became horizontal, continuous head-over-heels self rotation, and a feeling that the body was supine. Almost all responses were of constant tilt in the sphere. Constant and alternating tilt were the most common responses in the dotted room. In the furnished room 60% of subjects experienced full head-over-heels self rotation.
Related Concept Videos
 01:29
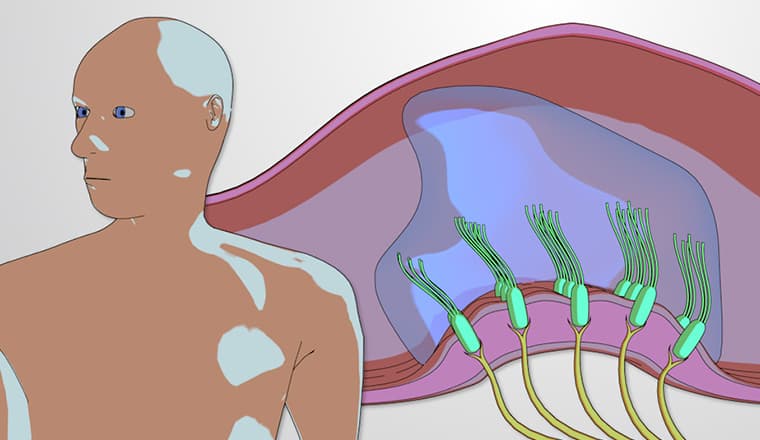
The Vestibular System
 01:28
Major Somatic Sensory Pathways
 01:15
Equilibrium and Balance
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...