Movement aftereffect of bi-vectorial transparent motion
Related Experiment Video
Updated: Nov 9, 2026
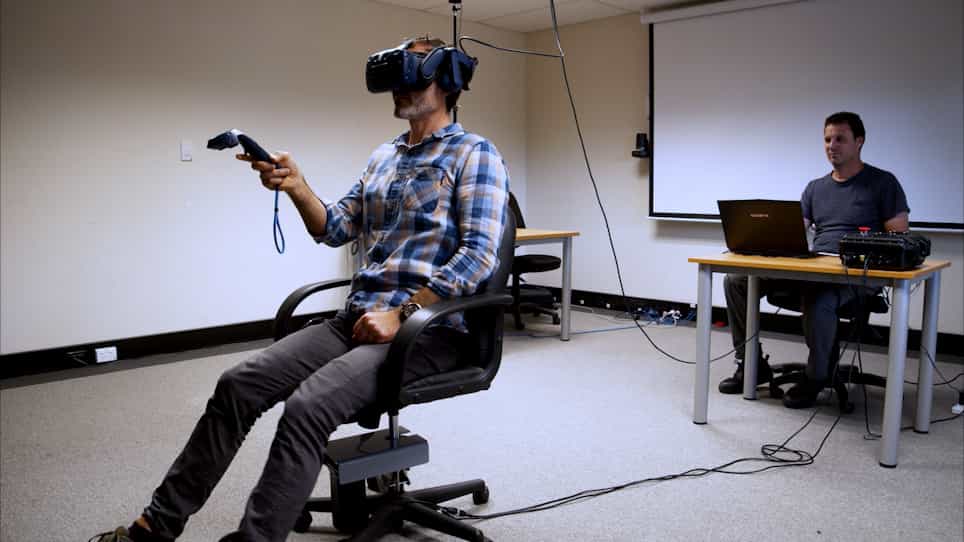
Controlled Rotation of Human Observers in a Virtual Reality Environment
Published on: April 21, 2022
F A Verstraten1, R E Fredericksen, W A van de Grind
1Department of Comparative Physiology, Utrecht University, The Netherlands.

Abstract:
Two moving random-pixel arrays (RPAs) were presented simultaneously in the same target field. These RPAs are perceived as two superimposed transparent moving sheets. Although two directions are perceived simultaneously during stimulus presentation, the movement aftereffect (MAE) is unidirectional. The visual system averages both motion signals in the MAE. For motion vectors of equal magnitude and perpendicular direction the MAE direction is the inverse of the sum of both vectors. In the first experiment we measured perceived direction of the MAE of transparent motion for a range of speed combinations. Results indicate that vector summation only predicts the correct MAE direction for combinations of equal speeds. It is suggested that the direction of the MAE of transparent motion is a resultant of the weighted summation of the component inducing vectors. The question then arises what determines the weighting factors. Directional sensitivity and MAE duration of the individual vectors under transparent conditions were measured and used to weigh the vectors and predict the MAE direction of transparent motion. Statistical analyses showed that MAE duration is a better basis to determine the weighting factors predicting the direction of the MAE of transparent motion than component sensitivity. The direction of the MAE of transparent motion thus seems to be determined by the amount of adaptation to the component vectors as reflected by MAE duration. The results suggest that this gain control cannot be located in the individual motion detectors and must be situated at or after some subsequent cooperation stage of the human motion analysis system.
More Related Videos


Related Concept Videos
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:10
Relative Motion Analysis - Acceleration
 01:30
Vector Functions and Motion: Problem Solving
 01:00
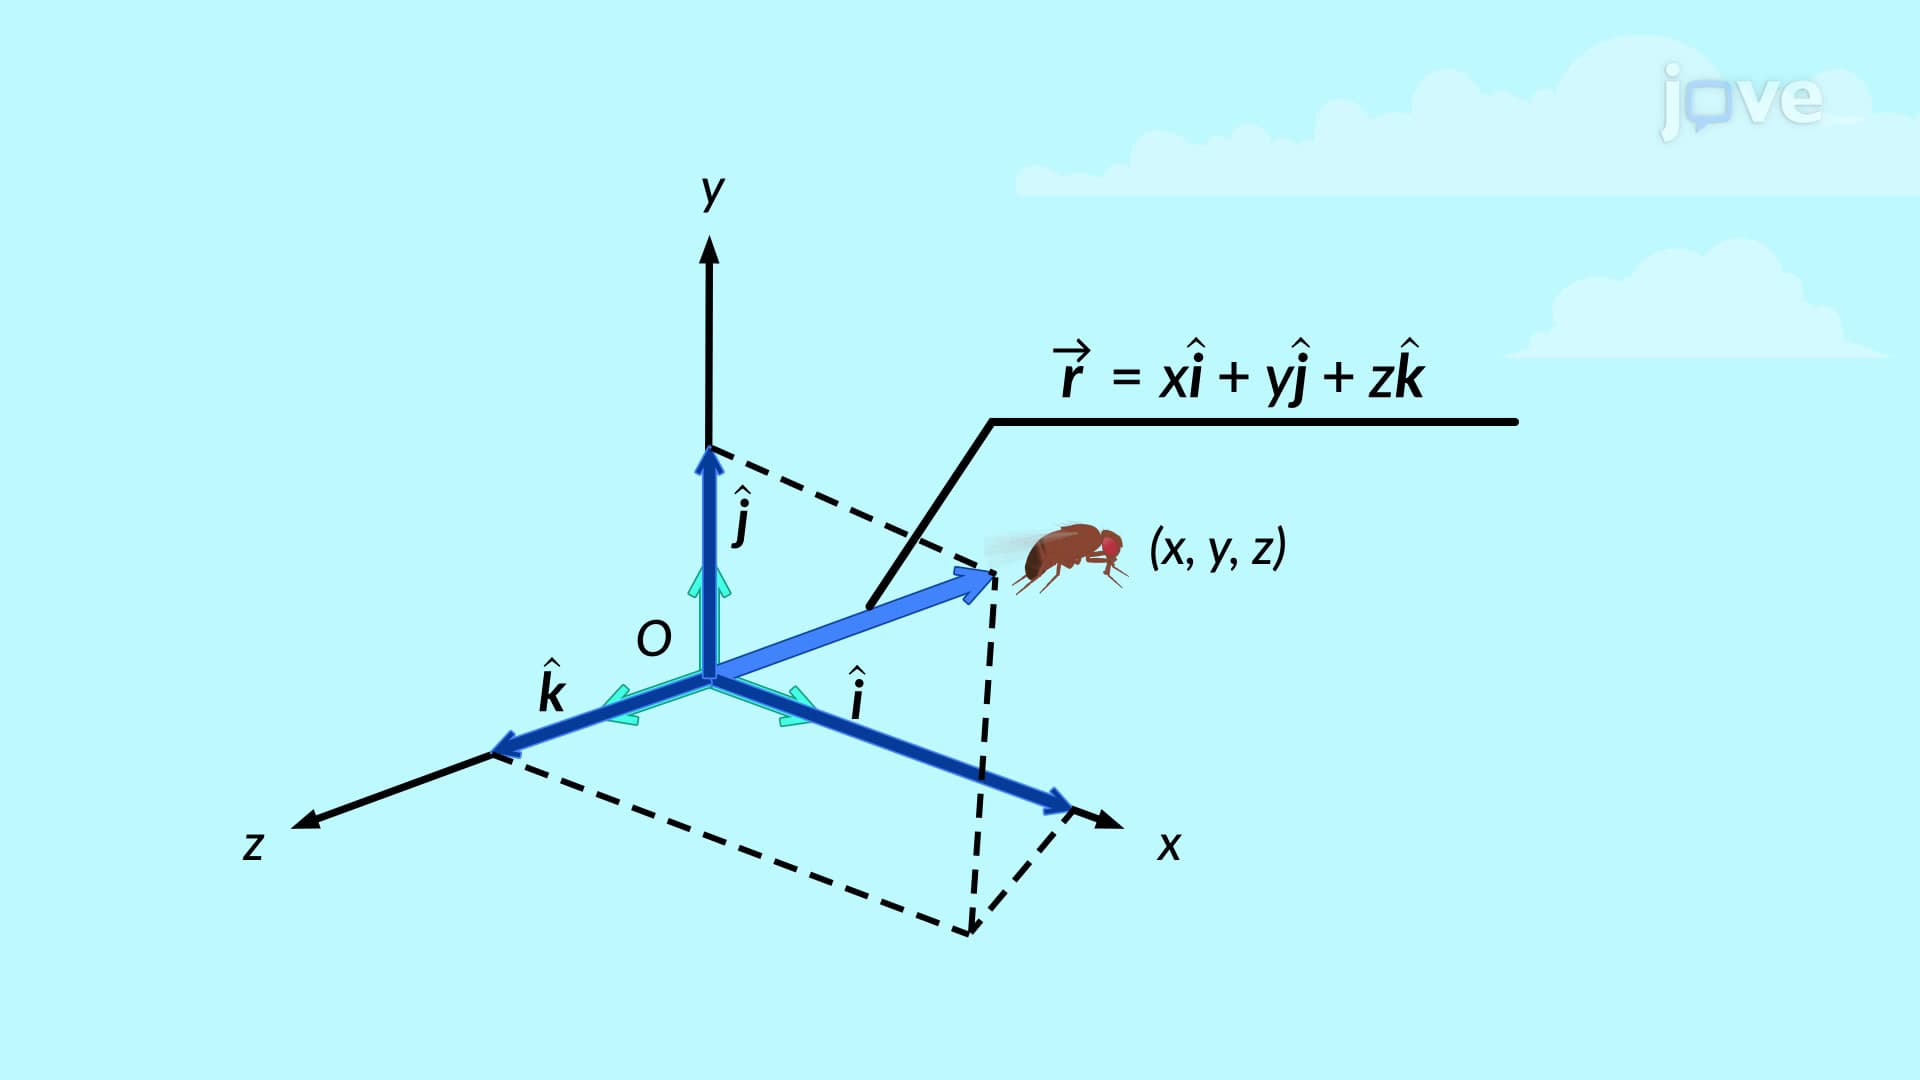
Position and Displacement Vectors
Further, several important kinds of...
01:00Position and Displacement Vectors
Further, several important kinds of...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...