A model of synchronization of motor acts to a stimulus sequence. II. Stability analysis, error estimation and simulations
Related Experiment Video
Updated: Nov 9, 2026
Bouncing Ball with a Uniformly Varying Velocity in a Metronome Synchronization Task
Published on: September 21, 2017
1Max Planck Institute for Psychological Research, Munich, Germany.

Abstract:
In Part I (Mates 1994), a linear model of timing and error-corrections was constructed that aims at an explanation of the mechanisms underlying a subject's performance in an experimental paradigm, in which the task is to synchronize a sequence of motor acts to a sequence of stimuli. The model consists of two error-corrective mechanisms: (1) corrections of period (inverted frequency) of the sequence of responses; (2) corrections of phase shift of that sequence (synchronization error). In this paper, the influence of the physiologically justifiable model variables and of initial conditions on the steady-state response sequence as well as the stability of performance of the model are analyzed. The model is stable for error-correction gains in the range from 0 to 2. Comparison with known empirical data supports the assumption that reasonable values are less than 1. Furthermore, an alternative to the basic linear model is introduced in which the possible character of the process of subjective acquisition of the synchronization error is discussed. On the basis of findings from other experimental paradigms (fusion and order threshold) it can be assumed that the subjective estimate is a nonlinear function of the difference between the temporal central availability of internal representations of the stimulus and response-feedback events. Some other known synchronization data are simulated by the nonlinear modification of the model in this paper. A good fit of the simulation results achieved further justifies the model structure proposed. Finally, the possible effect of the subjective synchronization-error estimation on empirical data is discussed.
Related Concept Videos
 01:25
Multimachine Stability
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
 01:30
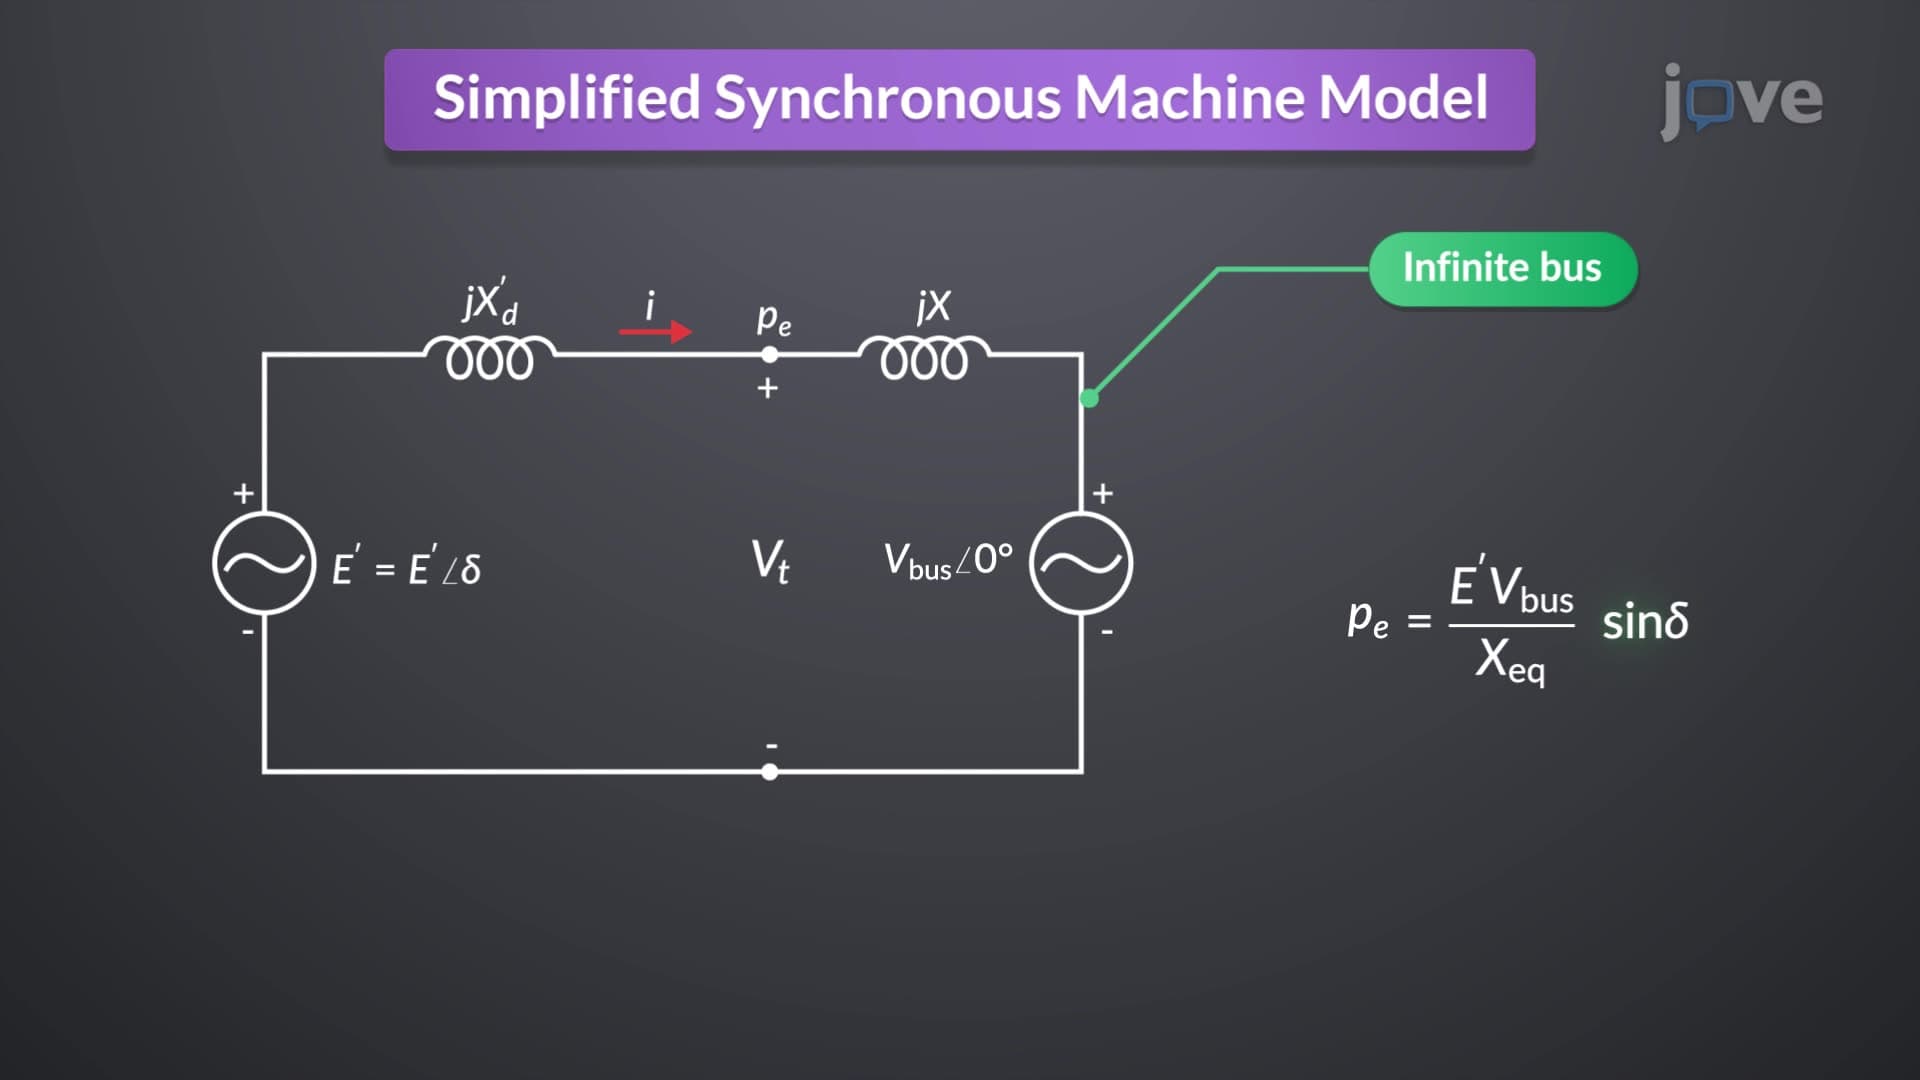
Simplified Synchronous Machine Model
In this model, each generator is connected to a...
 01:18
Hierarchy of Motor Control
 01:22
Muscle Stimulation Frequency
Wave summation
At low firing rates, motor neurons induce individual twitch contractions in muscle fibers. These twitches...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system.
 01:13
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...