A study of the stability of generalized wave gaits
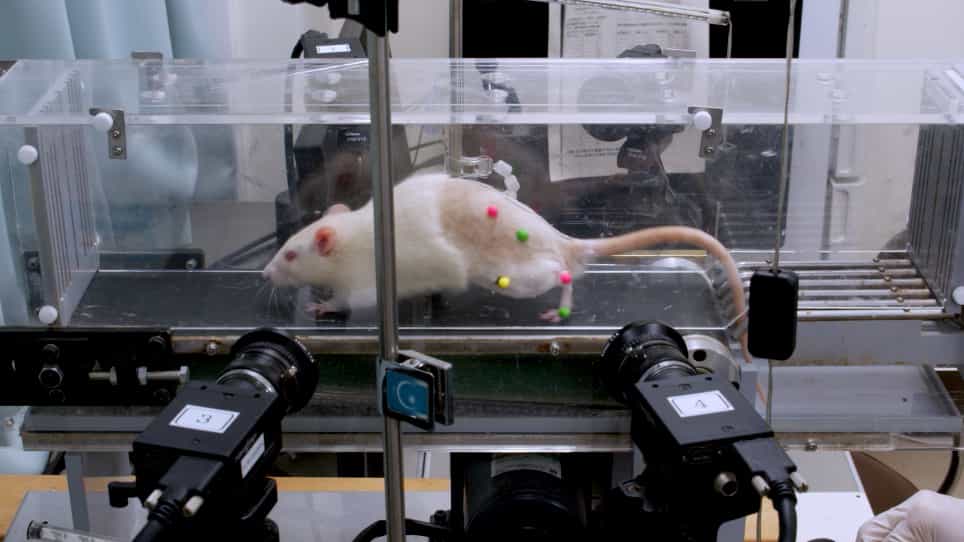
Related Experiment Video
Updated: Nov 6, 2026
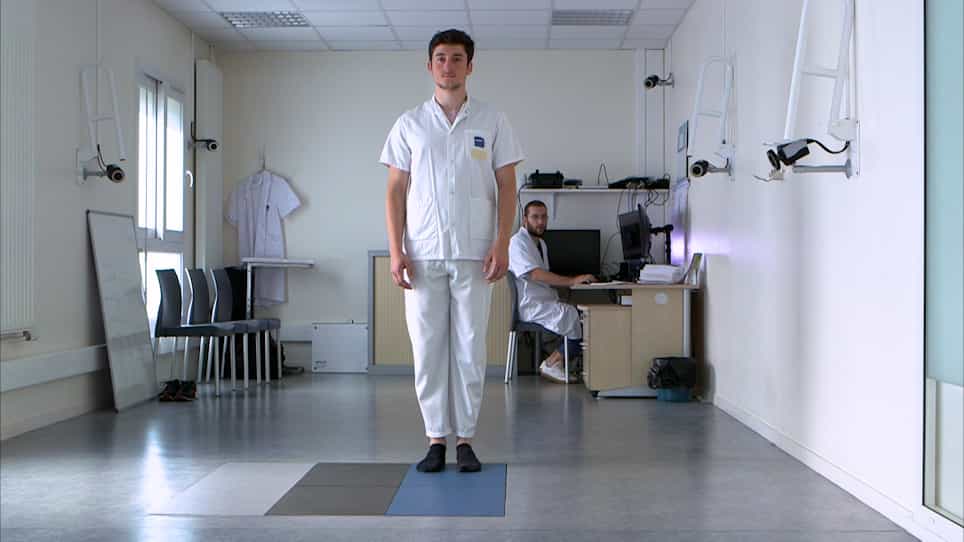
Postural Organization of Gait Initiation for Biomechanical Analysis Using Force Platform Recordings
Published on: July 26, 2022

Abstract:
The wave gait has been observed in animal and insect walking and has been widely implemented in the control of walking machines. It has been proved that the wave gait possesses the optimum stability among all periodic gaits under the geometrical condition that R/P < or = 1, where R and P are respectively the stroke and pitch of a walking machine. Recently, based on numerical results, a generalized hexapodal wave gait was reported to be more stable than the wave gait for R/P > 1. In this paper, in order to understand more about the generalized wave gait, an analytical method is applied to study its stability in three categories of multilegged systems: quadrupeds, hexapods, and 2n-legged systems (n > or = 4). Two optimal generalized wave gaits are found for quadrupeds, and three optimal gaits are found for each of the other two categories. For all three categories, one of the optimal generalized wave gaits is the wave gait. The stability and geometrical conditions of these optimal gaits are derived and verified numerically. Furthermore, it is shown that the quadrupedal generalized wave gaits have the optimum stability among all periodic gaits with the stepping sequence 1-4-2-3.
Related Concept Videos
 01:28
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's response.
 01:04
Oscillations about an Equilibrium Position