Neural network based dynamic controllers for industrial robots
Related Experiment Video
Updated: Nov 6, 2026

Closed-loop Neuro-robotic Experiments to Test Computational Properties of Neuronal Networks
Published on: March 2, 2015
1Department of Electrical Engineering, Pohang University of Science and Technology, South Korea.

Abstract:
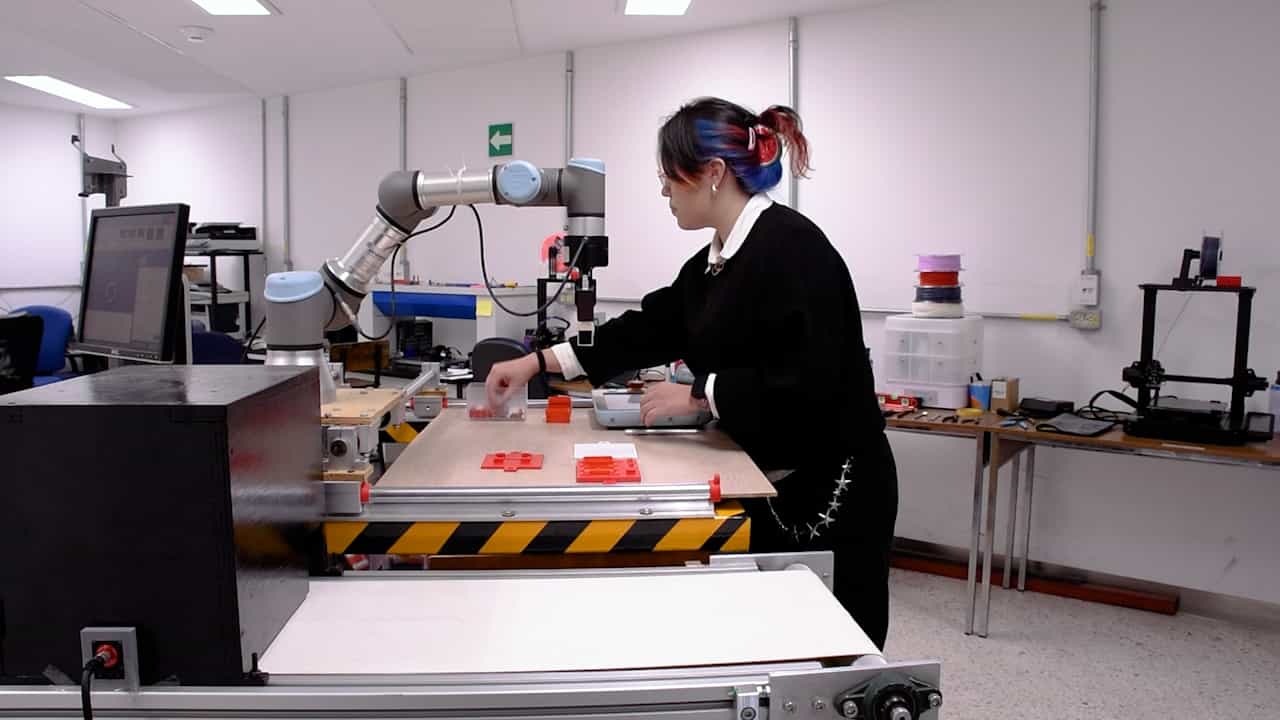
The industrial robot's dynamic performance is frequently measured by positioning accuracy at high speeds and a good dynamic controller is essential that can accurately compute robot dynamics at a servo rate high enough to ensure system stability. A real-time dynamic controller for an industrial robot is developed here using neural networks. First, an efficient time-selectable hidden layer architecture has been developed based on system dynamics localized in time, which lends itself to real-time learning and control along with enhanced mapping accuracy. Second, the neural network architecture has also been specially tuned to accommodate servo dynamics. This not only facilitates the system design through reduced sensing requirements for the controller but also enhances the control performance over the control architecture neglecting servo dynamics. Experimental results demonstrate the controller's excellent learning and control performances compared with a conventional controller and thus has good potential for practical use in industrial robots.
Related Concept Videos
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:22
PID Controller
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The direction...
 01:24
Sequence Networks of Rotating Machines
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...