Predictive smooth pursuit of complex two-dimensional trajectories in monkey: component interactions
Related Experiment Video
Updated: Nov 4, 2026
Design and Use of an Apparatus for Presenting Graspable Objects in 3D Workspace
Published on: August 8, 2019
R E Kettner1, H C Leung, B W Peterson
1Institute for Neuroscience, Northwestern University Medical School, Chicago, IL 60611, USA. r-kettner@nwu.edu

Abstract:
Smooth pursuit eye movements were studied in monkeys tracking target spots that moved two-dimensionally. Complex target trajectories were created by applying either two or three sinusoids to horizontal and vertical axes in various combinations. The chance of observing predictable performance was increased by repeated training on each trajectory. Data analyses were based upon repeated presentations of each trajectory within sessions and on successive days. We wished to determine how accurately monkeys could pursue targets moving along these trajectories and to observe interactions among frequency components. At intermediate frequencies, tracking performance was smooth and consistent during repeated presentations with saccadic corrections that were well integrated with smooth pursuit. The mean gain for eight different sum-of-sines trajectories was 0.83 and the mean magnitude (absolute value) of the phase error was 6 degrees. In light of the long delays that have been associated with the processing of visual information, these values indicate that the monkeys were pursuing predictively. Five factors influenced predictive pursuit performance: (1) there was a decline in performance with increasing frequency; (2) horizontal pursuit was better than vertical pursuit; (3) high-frequency components were tracked with higher gains and phase lags, while lower-frequency components were tracked with lower gains and phase leads; (4) the gain of sinusoidal pursuit was always reduced when a second sinusoid was applied to the same axis or, to a lessor extent, when a second sinusoid of higher frequency was applied to the orthogonal axis; (5) the phase of sinusoidal pursuit shifted from a phase lag to a phase lead when combined with a second sinusoid of higher frequency, but was not affected by the addition of a lower-frequency sinusoid. Findings 1 and 2 confirm, in monkeys, results reported for humans, and 3 extends to monkeys and to two-dimensional pursuit results based upon human subjects. All of these findings demonstrate that complex predictive tracking is controlled by a nonlinear and nonhomogeneous system that uses predictive strategies in concert with feedback control to generate good pursuit.
Related Concept Videos
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:26
Orthogonal Trajectories
 01:27
Curvilinear Motion: Normal and Tangential Components
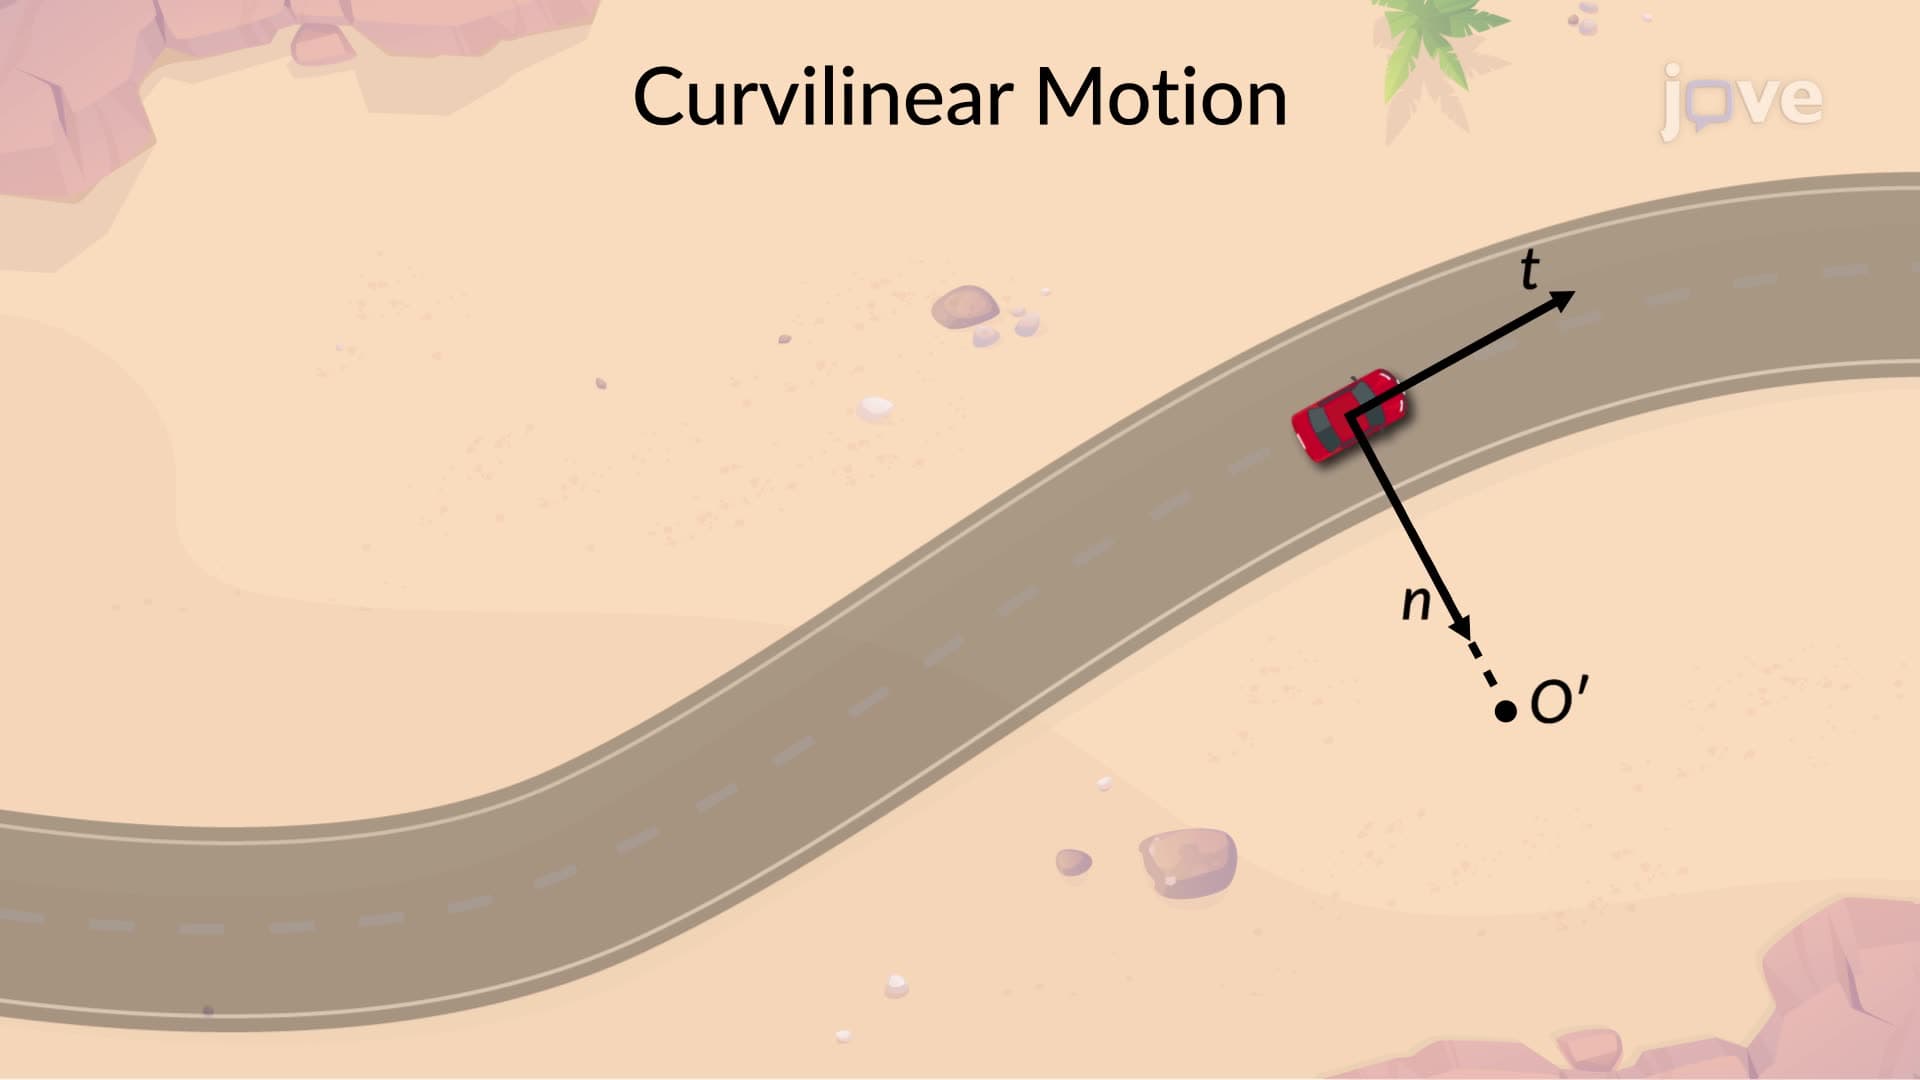
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...