Related Experiment Video
Updated: Aug 15, 2026


A Structured Rehabilitation Protocol for Improved Multifunctional Prosthetic Control: A Case Study
Published on: November 6, 2015
The sense of effort and two models of single-joint motor control
P R Burgess1, T A Cooper, G L Gottlieb
1Department of Physiology, University of Utah Medical School, Salt Lake City 84108, USA.

Abstract:
Two sets of experiments were carried out. In the first set, human subjects were asked to make the same effort with the elbow flexors at different joint angles under isometric conditions. In some experiments, the subjects were standing with the arm in a vertical (parasagittal) plane; in others, they were seated with the arm in a horizontal (transverse) plane. When muscular torque at a given effort level (ordinate) was plotted as a function of elbow joint angle (abscissa), the resulting isoeffort torque-angle profiles tended to be flat or negatively sloping over a range from 45 degrees to 135 degrees, and they were often nonmonotonic. Increases in effort up to near-maximal levels caused the isoeffort torque-angle profiles to shift upward with little alteration in shape. In the second set of experiments, seated subjects with the arm horizontal resisted baseline torques produced by a motor that acted to extend the elbow joint. Unexpected increases and decreases in torque were superimposed on the baseline torque. The subjects either were instructed to intervene and return the elbow to the initial (90 degree) position, or were told, "Do not intervene voluntarily; let the motor move your arm." Effort was reported both under baseline conditions and after the changes in torque. It was found that changes in effort were a function of the changes in torque opposed by the elbow flexors, and were similar whether the subject had repositioned the arm or allowed it to be moved by the motor. In the latter case, the arm came to rest after displacements that were a function of the size and direction of the torque change. For individual subjects, the largest angular displacements ranged from +/- 10 degrees to +/- 20 degrees for changes in torque of +/- 10 N.m. There was no evidence for any angular dependence of the effort judgements at a given torque over this angular range. Depending on whether effort is primarily an efferent perception proportional to voluntary motor activity or also has a significant afferent (involuntary) component, different models of motor control are supported by these data.
Related Concept Videos
 00:46
Motor Units
 01:13
Motor Units
Motor units come in different sizes, with smaller units...
 01:20
Motor Unit Stimulation
The latent period of contraction marks the onset of excitation-contraction coupling, when the action potential propagates across the sarcolemma, preparing the muscle fibers for contraction. As the fibers enter the contraction phase, the...
 01:24
Muscle Coordination and Action
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement.
 01:18
Hierarchy of Motor Control
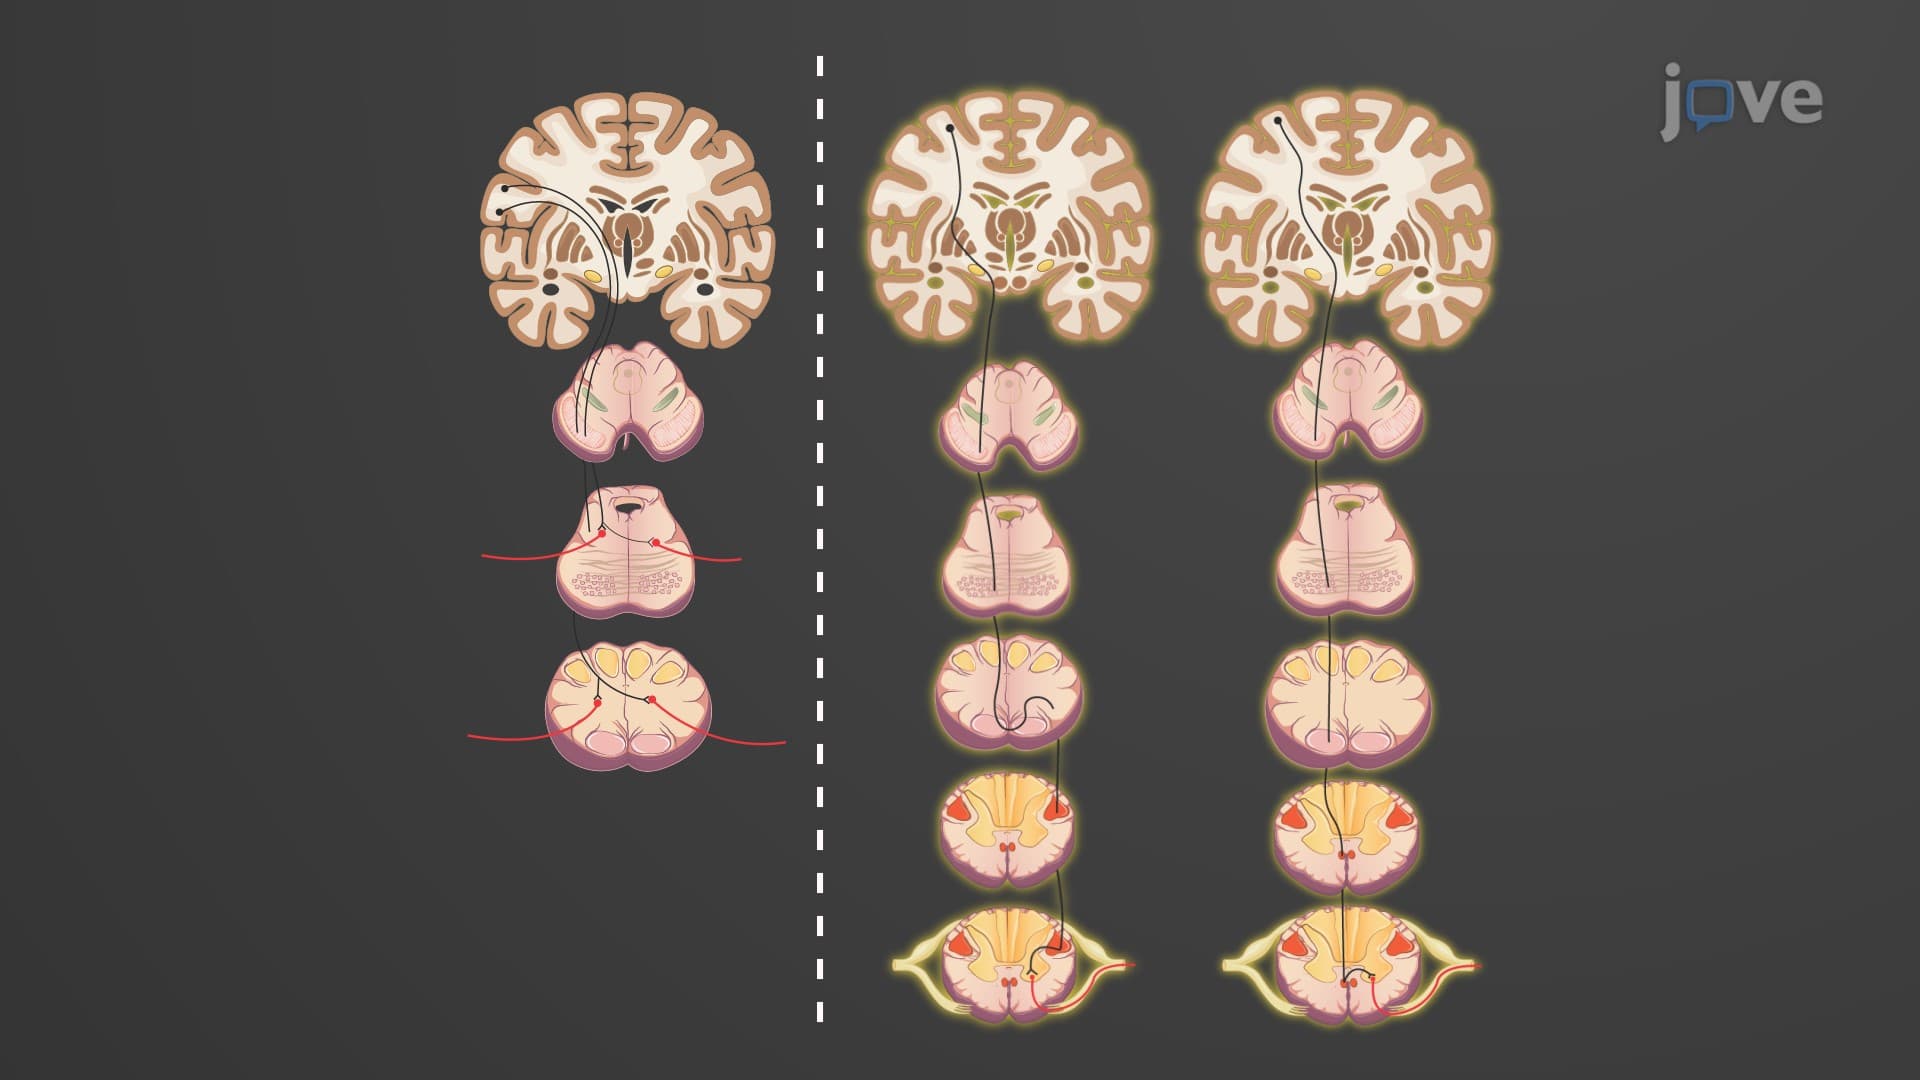 01:11
Direct Motor Pathways
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and the...