Related Experiment Video
Updated: Aug 19, 2026

Sample Drift Correction Following 4D Confocal Time-lapse Imaging
Published on: April 12, 2014
Spatial phase differences can drive apparent motion
1University of Toronto, Ontario, Canada. Sekuler@psych.utoronto.ca

Abstract:
Can shape differences drive apparent motion? Results from previous research are equivocal. Much of the confusion may be due to the use of relatively complex stimuli: letters or geometric shapes, comprising many spatial frequencies, phases, orientations, and contrasts. We focus on relatively simple stimuli: Gaussian damped f+nf compound sinewave gratings. We examine whether relative phase differences, which are critical for shape perception, can drive apparent motion. We find that some, but not all, phase differences can drive apparent motion. Specifically, stimuli that are easily discriminable and perceptually dissimilar can affect the solution of the correspondence problem. In this case, observers consistently perceive stimuli in one frame moving to the position of perceptually similar stimuli in the next frame. This general result holds over a wide range of spatial frequencies, orientations, and contrasts. Implications for theories of motion processing are discussed.
More Related Videos
Related Concept Videos
 01:10
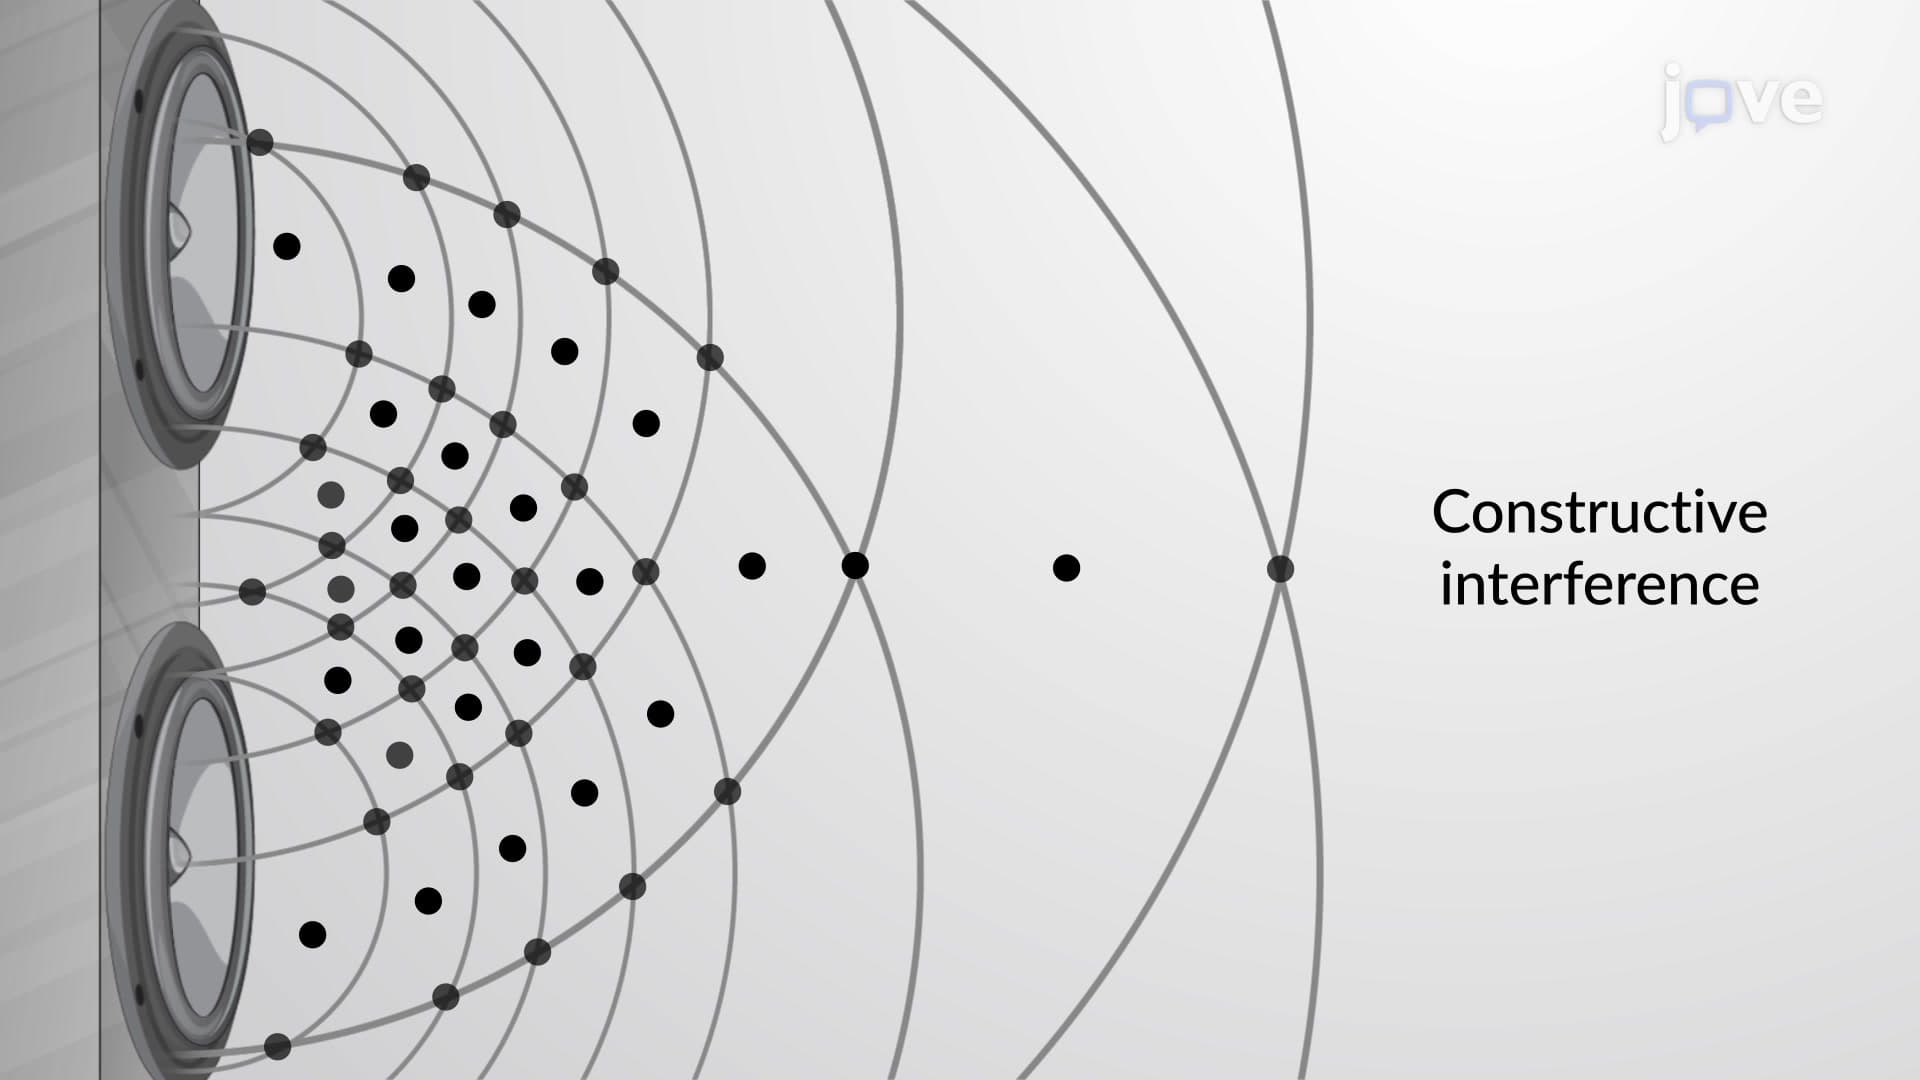
Interference: Path Lengths
Two special sources may be considered when they are in phase. This can be easily achieved by feeding the two sources from the same source. An example would be synchronizing the two speakers by feeding them with the same source, such as the sound waves produced by a tuning fork. This setup ensures that the two sources have the same frequency and are...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:10
Relative Motion Analysis - Acceleration
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:15
Depth Perception and Spatial Vision