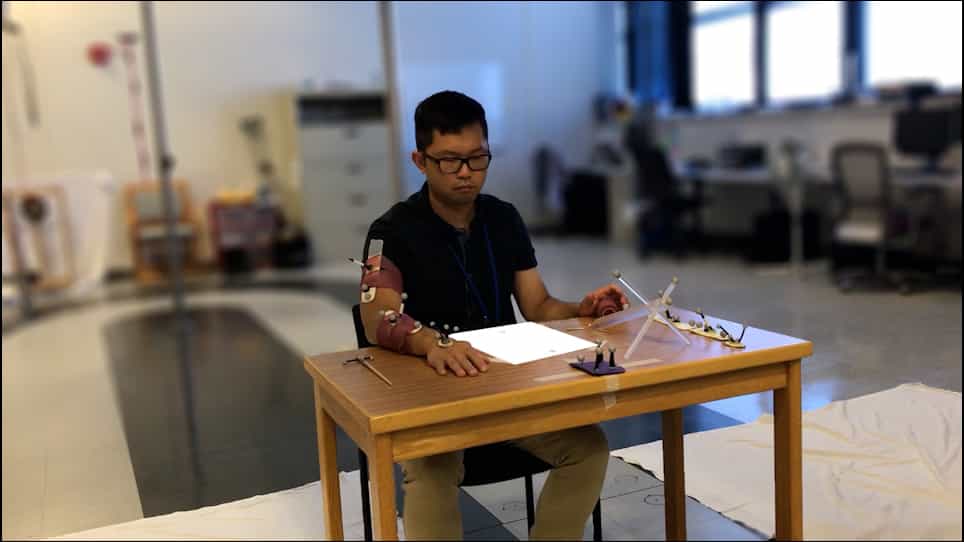
Two-arm trajectory planning in a manipulation task
Related Experiment Video
Updated: Nov 2, 2026

Operation of the Collaborative Composite Manufacturing (CCM) System
Published on: October 1, 2019
G J Garvin1, M Zefran, E A Henis
1GRASP Laboratory, University of Pennsylvania,Philadelphia 19104-6228, USA.

Abstract:
This paper addresses the trajectory planning problem for a task which requires positioning and orienting an object firmly grasped by two hands at a visually specified goal configuration in the horizontal plane. The motor task involves three degrees of freedom (two translational and one rotational), and the motions of the arms are constrained by the physical coupling through the held object. Experimentally measured trajectories of two arms in the coordinated positioning/orienting task are presented. The hypothesis that the rotational and translational components of motions are decoupled and independently planned is tested. Two explicit mathematical models to account for the kinematic features of the two-arm motions are formulated, and the predictions of the models are compared with the experimental data. Both models extend the minimum-jerk model to the two-arm coordinated motions case. The trajectories predicted by the models were found to be in qualitative agreement with the experimental data. However, neither model could account for the observed configuration dependence of the motions, nor for some of the properties of the measured velocity components of the motions. Our findings support the idea that the rotational and translational components of two-arm motions in the positioning/orienting task are independently planned in extra-personal space, and are further combined in a hierarchical fashion to produce the observed motions. The tested models may serve as a basis for further investigations of issues pertinent to the generation of two-arm trajectories.
Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:26
Orthogonal Trajectories
 01:30
Vector Functions and Motion: Problem Solving