Related Experiment Video
Updated: Aug 2, 2026


Sit-to-stand-and-walk from 120% Knee Height: A Novel Approach to Assess Dynamic Postural Control Independent of Lead-limb
Published on: August 30, 2016
The hysteresis loop as a model for low back motion analysis
M J Warner1, J A Mertz, A S Zimmerman
1Department of Osteopathic Sciences, University of Medicine and Dentistry of New Jersey-School of Osteopathic Medicine (UMDNJ-SOM), USA.

Abstract:
The human low back is highly susceptible to dysfunction. Many diagnostic and treatment modalities for low back problems are used subjectively in clinical practice. Availability of a quantitative reference of back motion could improve practice efficiency. This article describes hysteresis and the hysteresis loop as an objective measurement model of low back motion. The authors constructed an instrument that quantifies force displacement responses of the lower back in passive subjects. Hysteresis loops generated by this instrument lay a scientific foundation on which to base diagnostic procedures and therapeutic measures.
More Related Videos

Related Concept Videos
 01:17
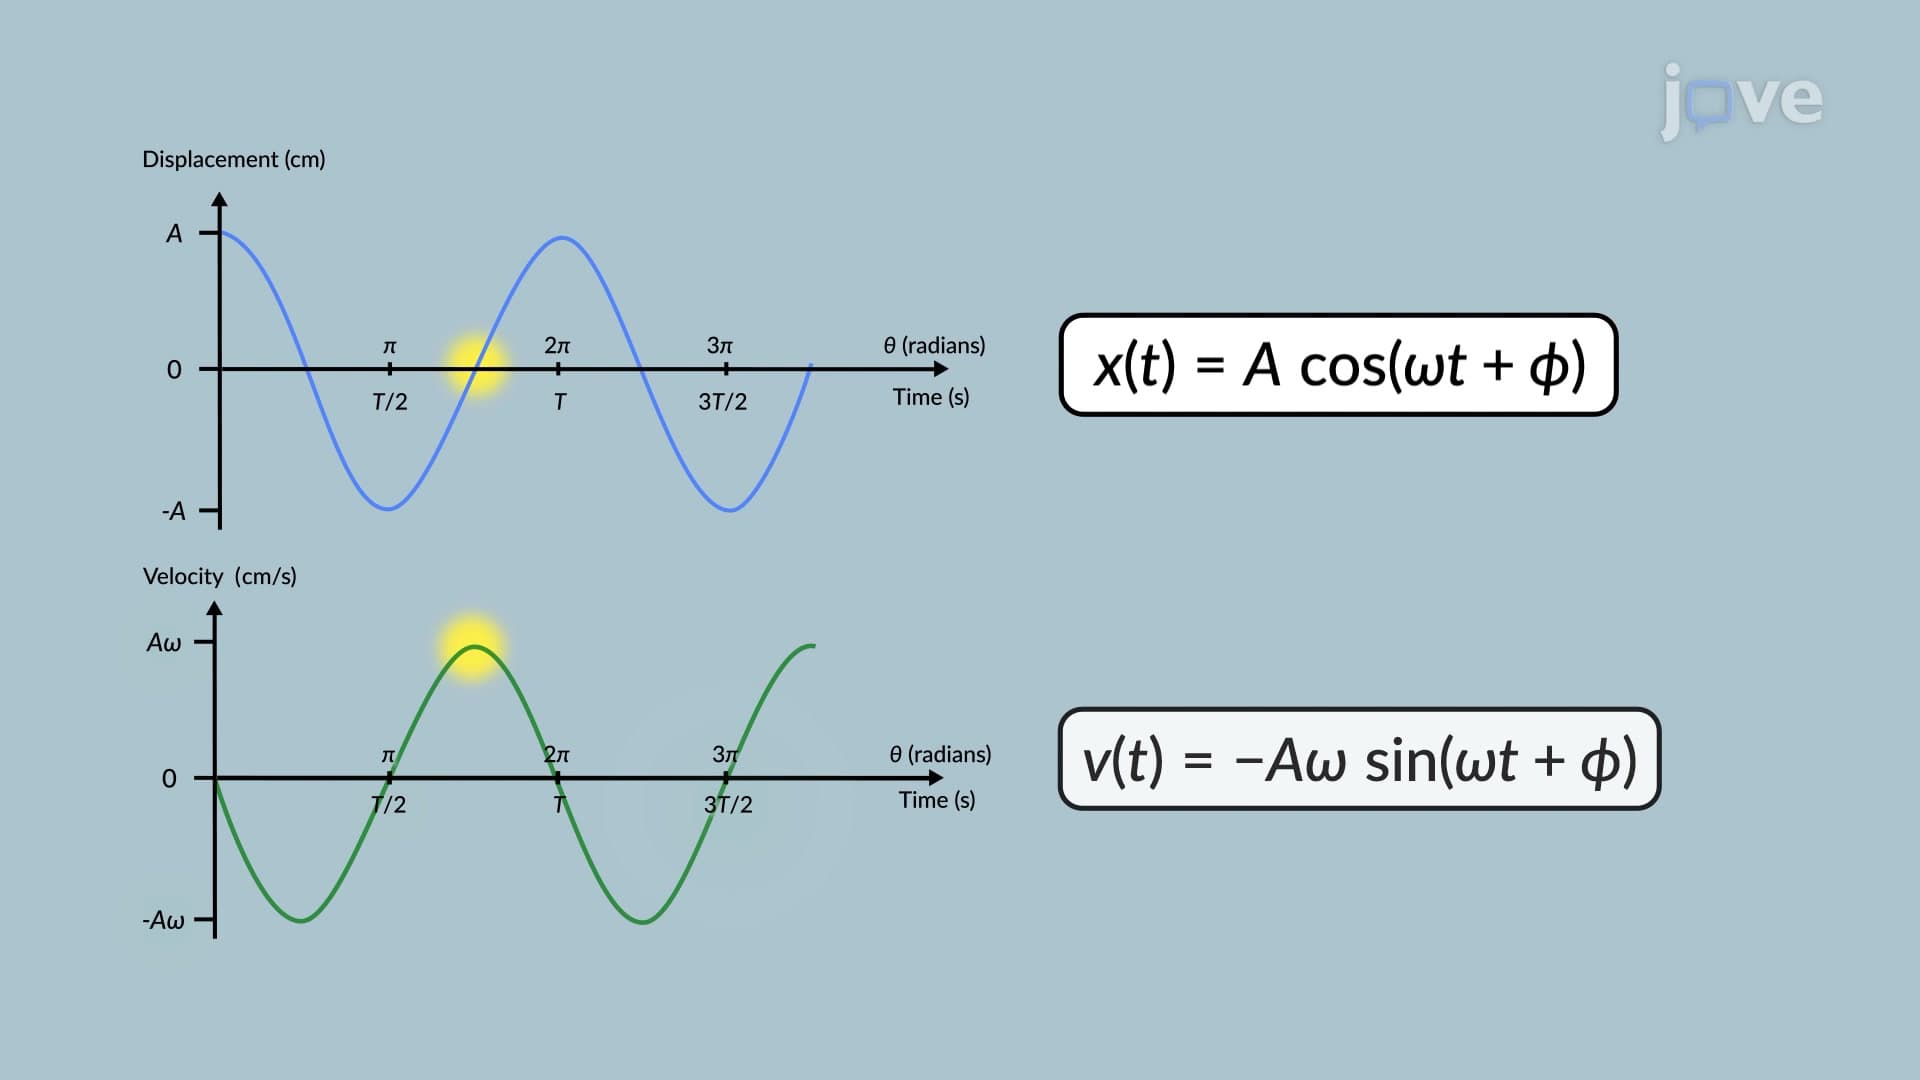
Characteristics of Simple Harmonic Motion
 01:14
Design Example: Frog Muscle Response
When the switch connecting the RL circuit is closed, a brief muscle contraction is observed. This is because, at a steady state, the inductor acts like a short circuit,...
 01:18
Residual Stresses in Bending
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:20
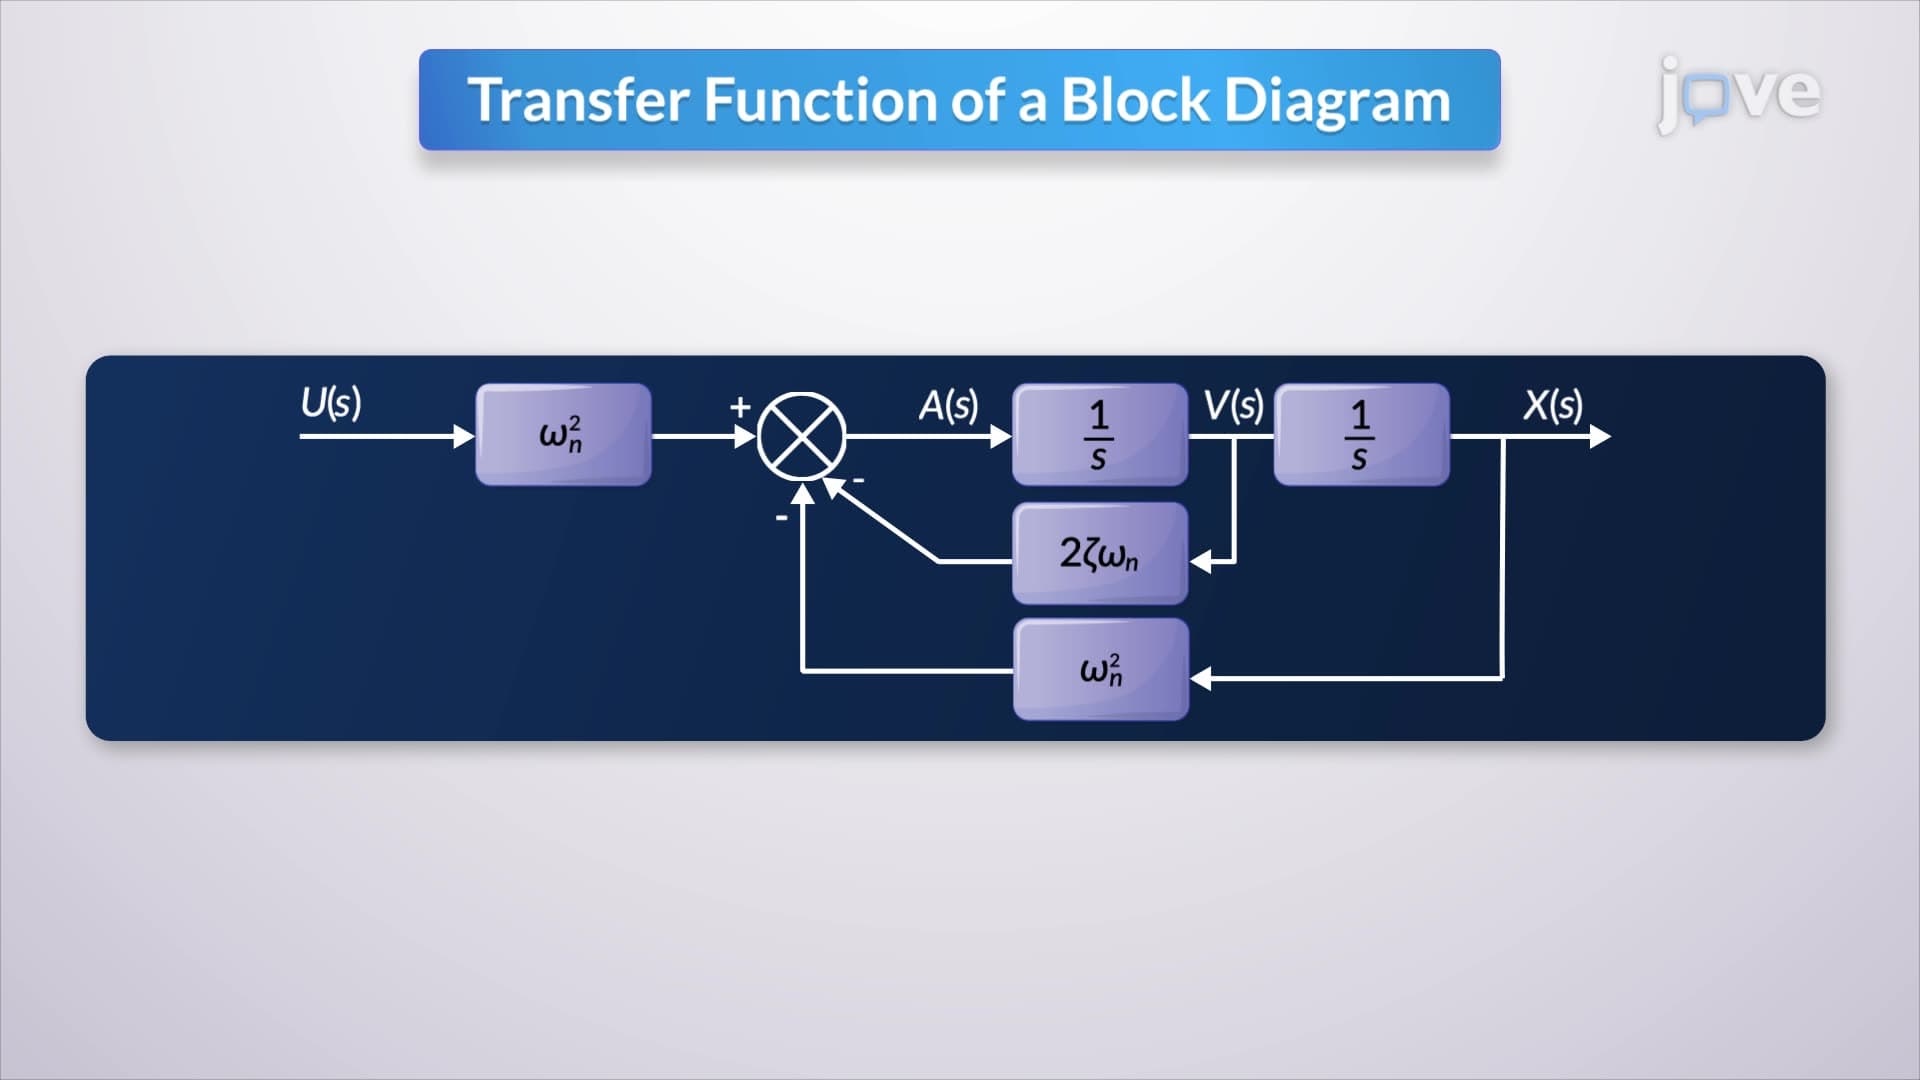
Relation between Mathematical Equations and Block Diagrams