Control model of human stance using fuzzy logic
Related Experiment Video
Updated: Oct 22, 2026
A Human-machine-interface Integrating Low-cost Sensors with a Neuromuscular Electrical Stimulation System for Post-stroke Balance Rehabilitation
Published on: April 12, 2016
1Institute of Biomedical Technology (BMTI), University of Twente, Enschede, The Netherlands.

Abstract:
A control model of human stance is proposed based on knowledge from behavioral experiments and physiological systems. The proposed model is based on the control of global variables specific to body orientation and alignment, rather than on the control of the body's center of mass within the base of support. Furthermore, the proposed control model is not based on purely inverted pendulum body mechanics where only motion at one joint is controlled, as for instance the ankle. In the proposed model, the degrees of freedom are controlled by using reciprocal and synergistic muscle actions at multiple joints. The control model is based on three sets of different global variables which act in parallel: (1) limb length and its derivative, (2) limb orientation and its derivative, and (3) trunk attitude and its derivative. An important feature of the control model is the use of fuzzy logic, which enables us to model experimental findings and physiological knowledge in a meaningful and explicit way using fuzzy if-then rules. In the control model, 36 fuzzy if-then rules are implemented and applied using a four-linked segment model consisting of a trunk, thigh, shank and foot. Uni- and biarticular limb muscles and trunk muscles are represented as torque actuators at each individual joint. In the model, three sets of global variables act in parallel and make corrective and coordinated responses to internal, self-induced perturbations. The data show that the use of global variables and fuzzy logic successfully enables us to model human standing with sway about a point of equilibrium. Small changes in, for example, total body sway are comparable to those seen during natural sway in human stance. The selected controllers--limb length, limb orientation and trunk attitude--seem to be appropriate for human stance control.

Related Concept Videos
 02:16
Stereotype Content Model
 01:09
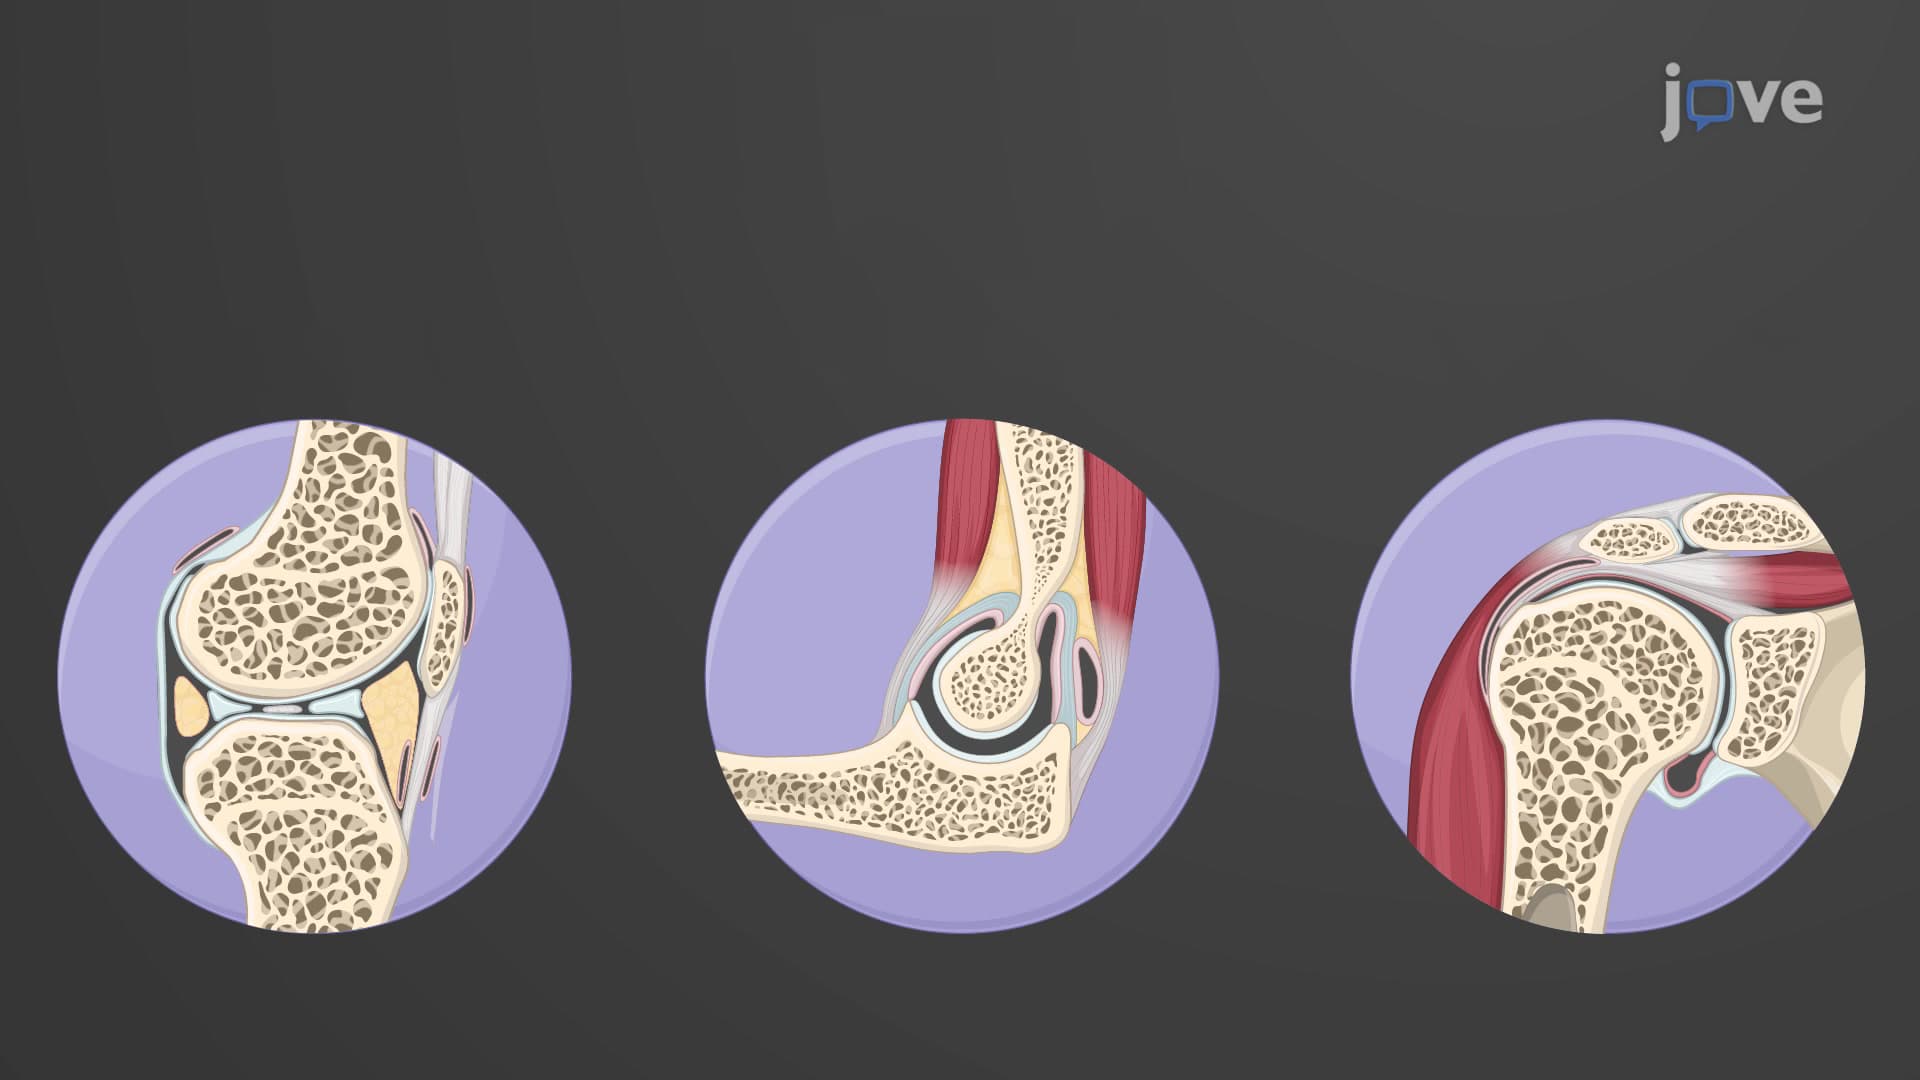
Functional Classification of Joints
The functional classification of joints is determined by the amount of mobility between the adjacent bones. Joints are functionally classified as a synarthrosis or immobile joint, an amphiarthrosis or slightly moveable joint, or as a diarthrosis, a freely moveable joint. Fibrous and cartilaginous joints can be functionally classified as either synarthroses or amphiarthroses, whereas all synovial joints are classified as diarthroses.
Synarthrosis
An immobile...
 01:10
Control Systems
At the heart...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:19
Root-Locus Method
This system can be represented by a block diagram,...