The interaction between stereoscopic and luminance motion
Related Experiment Video
Updated: Oct 2, 2026
Measuring Sensitivity to Viewpoint Change with and without Stereoscopic Cues
Published on: December 4, 2013
1Department of Visual Communication Design, Faculty of Design, Kyushu Institute of Design, Fukuokashi, Japan.

Abstract:
An interaction in apparent motion between perceived three-dimensional forms defined by stereopsis and local luminous elements is reported. Vertical stripes of cyclopean square gratings were simulated by random-dot stereograms. Alternation of two-frame stereograms whose phases differed by 90 deg caused two kinds of percepts, planes' motion in depth (first-order stereoscopic motion, first-order SM) or lateral motion of gratings (higher-order stereoscopic motion, higher-order SM). Experiment 1 explored the conditions under which higher-order SM frequently arose, as opposed to local luminance-based in-depth motion (first-order SM). The results show that, when the spatial arrangements of two-frame random dots were correlated, higher-order SM dominated for long ISI conditions (ISI > 73 msec). When they were uncorrelated, higher-order SM dominated even under zero ISI conditions. Subjects reported that, when higher-order SM was seen, dots were attached to the surfaces of the moving cyclopean figure (motion capture). Experiment 2 tested which factor caused the domination of higher-order SM under uncorrelated conditions in Experiment 1, the larger distance of dot jump or the varied directions of the dots' motion. The results show that, when the distance of dot jump is large or when the directions of dots' motion are incoherent, higher-order SM arises more frequently. When local first-order motion signals are weakened by appropriate temporal and spatial conditions or by incoherent motion directions, higher-order SM dominates and it captures the motion of dots.
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:27
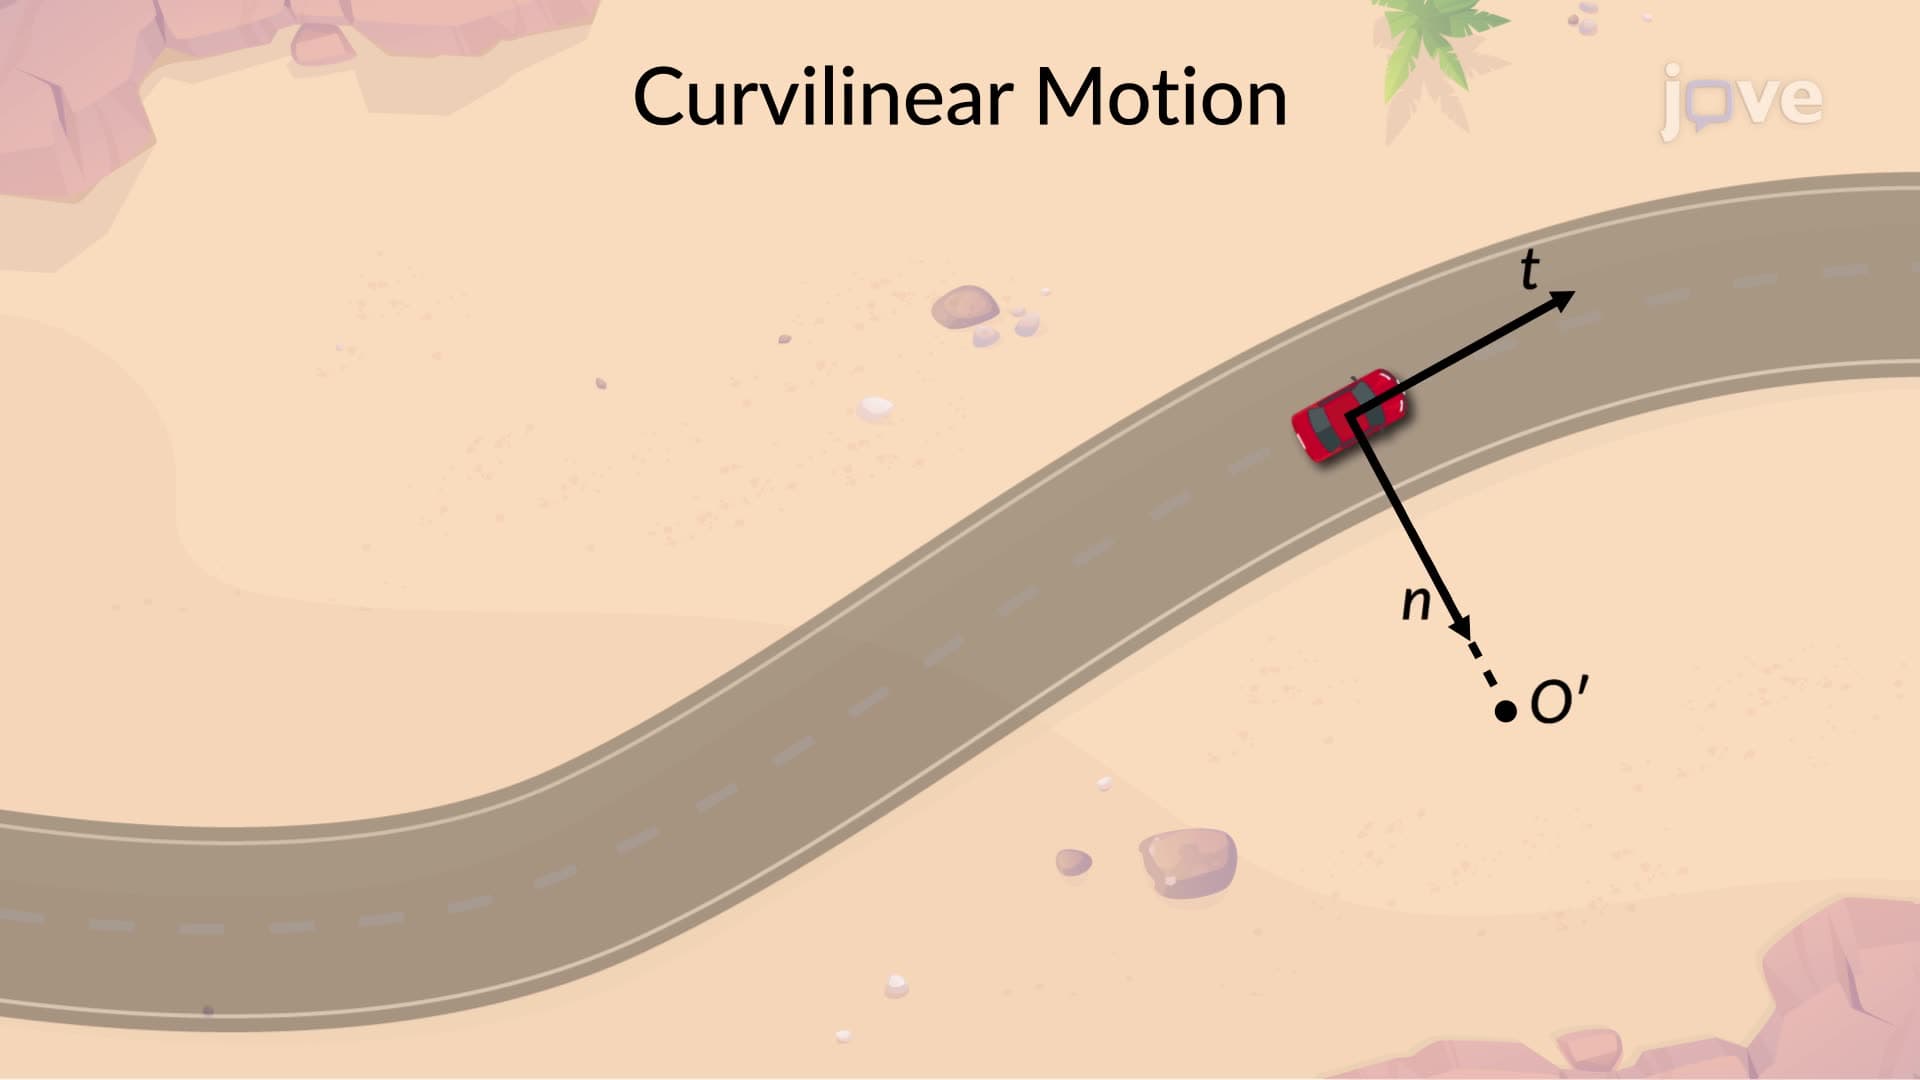
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:10
Relative Motion Analysis - Acceleration
 01:15
Depth Perception and Spatial Vision