Dynamometer for rat plantar flexor muscles in vivo
Related Experiment Video
Updated: Oct 31, 2026
Construction of Constant-Load (Isotonic) and Constant-Velocity (Isokinetic) Torque-Velocity-Power Profiles In vivo for the Rat Plantar Flexors
Published on: October 3, 2025
R G Cutlip1, W T Stauber, R H Willison
1Department of Mechanical & Aerospace Engineering, West Virginia University, Morgantown 26506, USA.

Abstract:
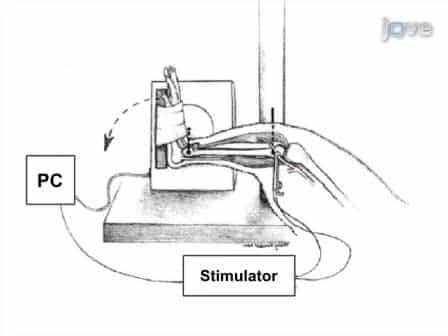
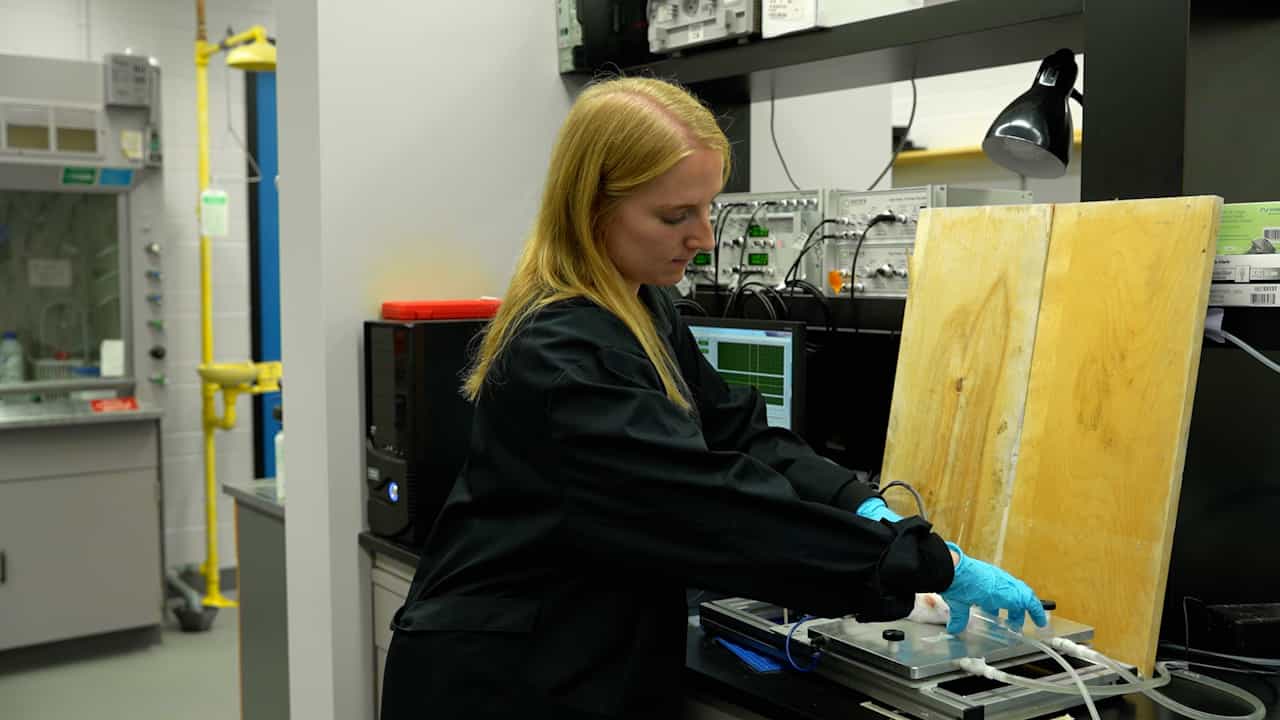
A dynamometer is designed and fabricated to measure the force output during static and dynamic muscle actions of the plantar flexor muscles of anaesthetised rats in vivo. The design is based on a computer-controlled DC servomotor capable of angular velocities in excess of 17.5 rad s-1. The system controls the range of motion, angular velocity and electrical stimulation of the muscles, while monitoring the force output at the plantar surface of the foot. The force output is measured by a piezo-electric load cell that is rated at 5 kg capacity. Angular velocity and position are measured by a DC tachometer and potentiometer, respectively. All measurement devices are linear (r2 = 0.9998). The design minimises inertial loading during high-speed angular motions, with a variation in force output of less than 0.2%. The dynamometer proves to be an accurate and reliable system for quantifying static and dynamic forces of rat plantar flexor muscles in vivo.