Modelling and simulation of the hand grasping using neural networks
Related Experiment Video
Updated: Aug 5, 2026
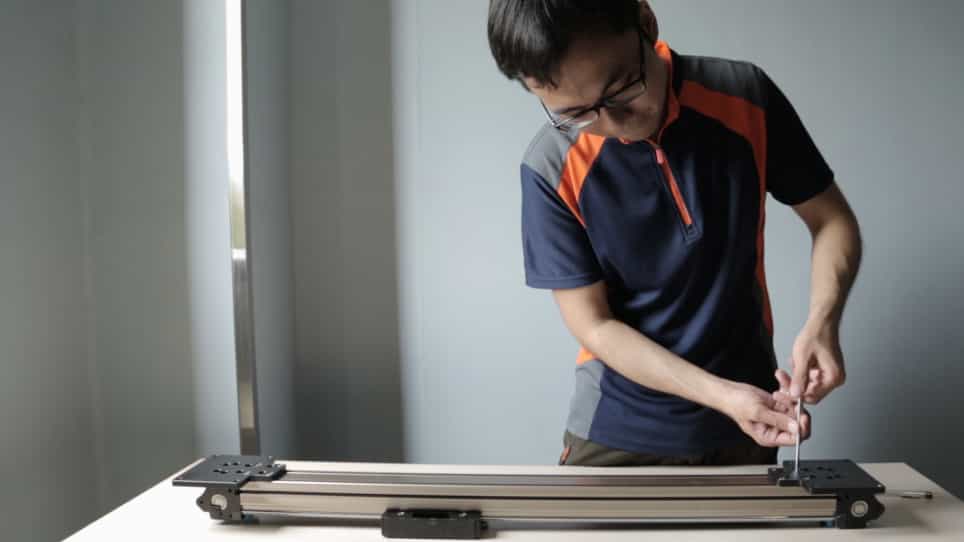
Design and Use of an Apparatus for Presenting Graspable Objects in 3D Workspace
Published on: August 8, 2019
1Design Engineering Research Centre, University of Wales Institute Cardiff, UK.

Abstract:
In this paper we present preliminary results of a study on the use of artificial neural networks to model and simulate the hand grasping. Results of this study will provide a basic understanding of the co-ordination and control of multiple degrees of freedom upper limb prosthetic devices and robotic end effectors when interacting with the environment. We assumed the hand to be a black box with the inputs being the object and simulation time sequence, whilst the output is the grasping postures over time. We trained the network with samples of key postures of the hand grasping several object shapes and sizes. The back-propagation technique was used to update the weights of the network. We found that the neural network is able to reproduce the postures of the hand grasping objects of different shapes and sizes from a single set of neural network weights.