Accuracy of reconstructed angular estimates obtained with the Ariel Performance Analysis System
Related Experiment Video
Updated: Aug 30, 2026
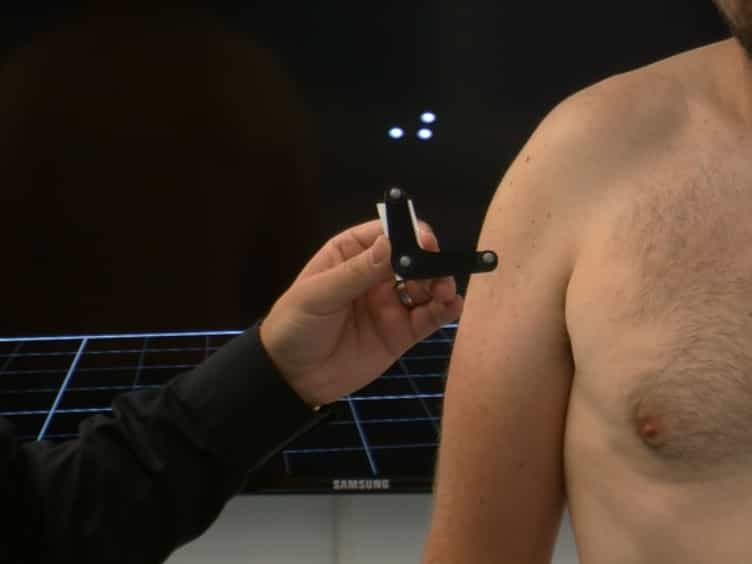
Measurement of Dynamic Scapular Kinematics Using an Acromion Marker Cluster to Minimize Skin Movement Artifact
Published on: February 10, 2015
D J Wilson1, B K Smith, J K Gibson
1Department of Physical Medicine and Rehabilitation, Rusk Rehabilitation Center, University of Missouri-Columbia, MO 65212, USA. dan_wilson@pmr.missouri.edu

Background And Purpose:
Three-dimensional computerized gait analysis continues to grow in use among physical therapists and other clinical specialists interested in quantitative data regarding human ambulation. This study documented the accuracy of reconstructed angular estimates under static and dynamic conditions using the Ariel Performance Analysis System.
Methods:
Angular velocity was systematically increased by raising the release position of a T-shaped pendulum. Angular velocities were examined by releasing the pendulum from four angles (0 degree-static, 45 degrees, 90 degrees, and 120 degrees). Twelve reference angles were estimated over 20 autodigitized frames for 10 trials at each release position. Intraclass correlation coefficients (ICCs) and analysis-of-variance (ANOVA) procedures were used to test the hypothesis that the error of angular estimates grows with increasing angular velocity.
Results:
Mean errors of the reconstructed angles were consistently within +/- 1.0 degree, regardless of angular velocity. An ANOVA revealed a statistically significant angular velocity effect, characterized by release position. The 90-degree release position produced the greatest error, followed by the 120-, 45-, and 0-degree release positions. The error was not significantly different between the 120- and 45-degree release positions. Intraclass correlation coefficients greater than .90 were found for all frame-to-frame angular velocities, except for the 90-degree release position. The angle estimates consistently underestimated the reference angles, regardless of release position.
Conclusion And Discussion:
The results suggest that clinically accurate angular estimates can be obtained across the range of angular velocities used in this study.
Related Concept Videos
 01:28
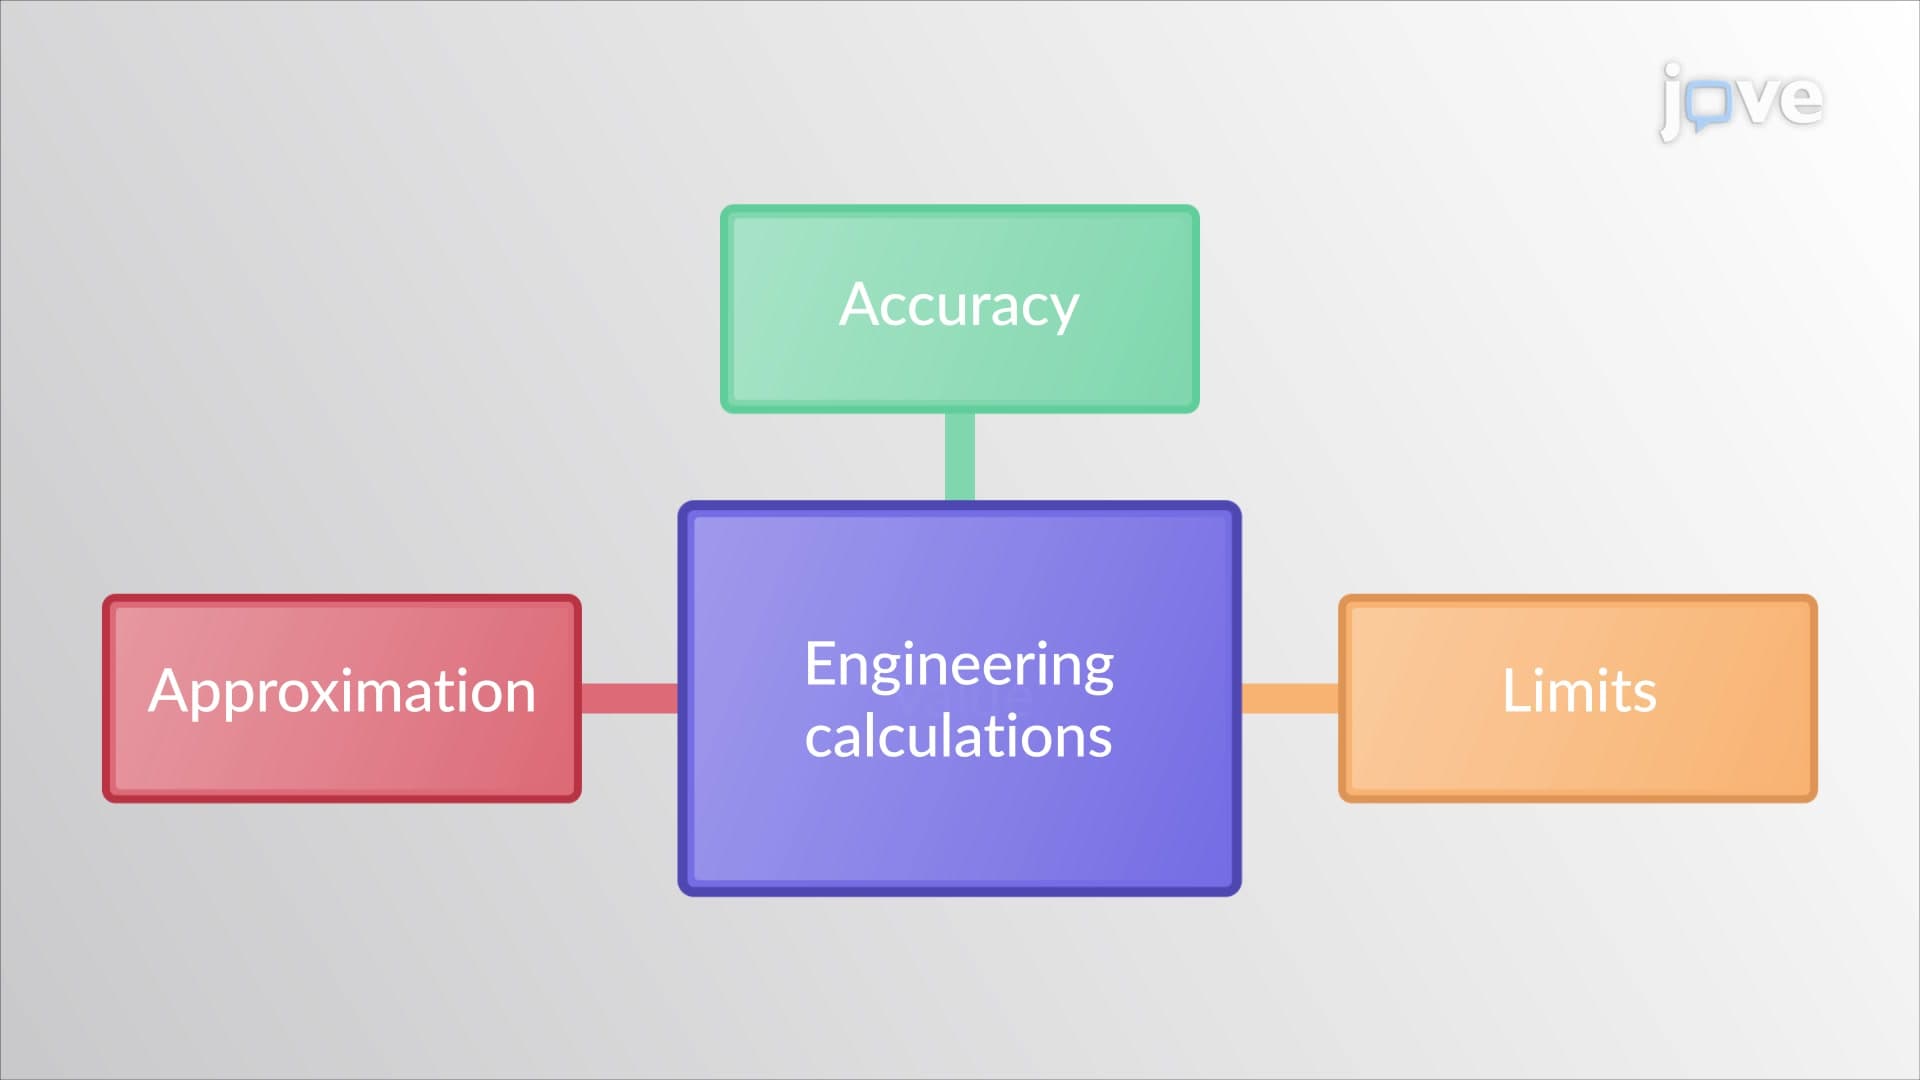
Accuracy, limits, and approximation
Accuracy is defined as the closeness of the measured value to the true or actual value. In engineering mechanics, repeated measurements are taken during theoretical or experimental analyses to ensure that the result is precise and accurate.
The accuracy of any solution is based on the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:10
Relative Motion Analysis - Acceleration
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:12
Adjusting a Traverse