Vector analysis of astigmatism changes by flattening, steepening, and torque
Related Experiment Video
Updated: Oct 30, 2026
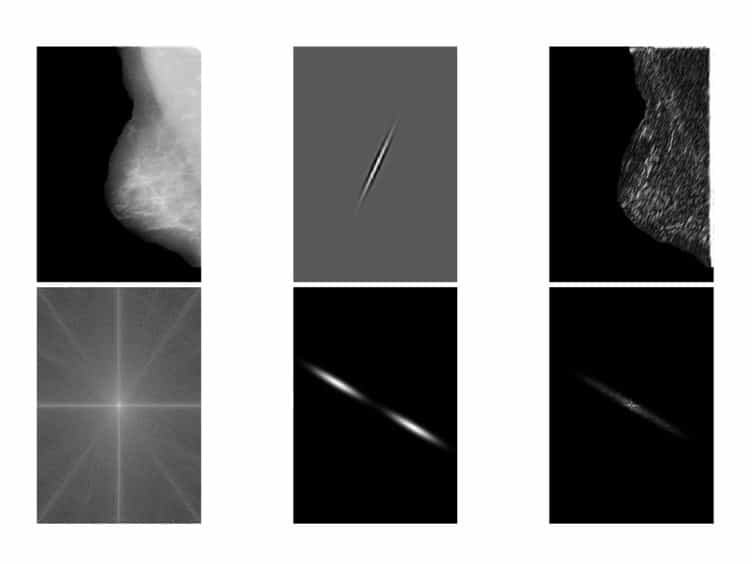
Detection of Architectural Distortion in Prior Mammograms via Analysis of Oriented Patterns
Published on: August 30, 2013
1Cheltenham Eye Centre, Melbourne, Victoria, Australia.

Purpose:
To understand the effect of astigmatism surgery by analyzing astigmatic changes according to their component parts.
Setting:
Cheltenham Eye Centre, Melbourne, Australia.
Methods:
The component parts of the astigmatic changes considered were flattening, steepening, clockwise torque, and counterclockwise torque. Calculations to determine the astigmatic change were performed by vector analysis using rectangular coordinates after doubling the astigmatism and surgical vector axes. A reference axis was used for the resolution of astigmatic change to ascertain its effect along a selected meridian.
Results:
When correcting astigmatism, the orientations of incisional (tissue addition) or nonincisional (tissue ablation) techniques in any cornea are at right angles to each other. Since differences exist in the measured astigmatism depending on whether it is measured topographically or by manifest refraction, an on-axis correction in one will occur with an off-axis effect in the other. The net result is a reduced flattening effect and a proportionately increased torque effect for the off-axis component.
Conclusion:
When treatment is applied off one of the four primary axes, the treating vector can be resolved into its component parts of flattening, steepening, and torque. Analyzing changes in this way provides a uniform means of assessing astigmatic changes for all types of cataract and refractive surgery and quantifies the flattening effect when treatment is applied off the intended meridian.
Related Concept Videos
 01:18
Transformation of Plane Stress
 01:20
Torsion in Vector Calculus
 01:20
Two-Dimensional Force System
 01:27
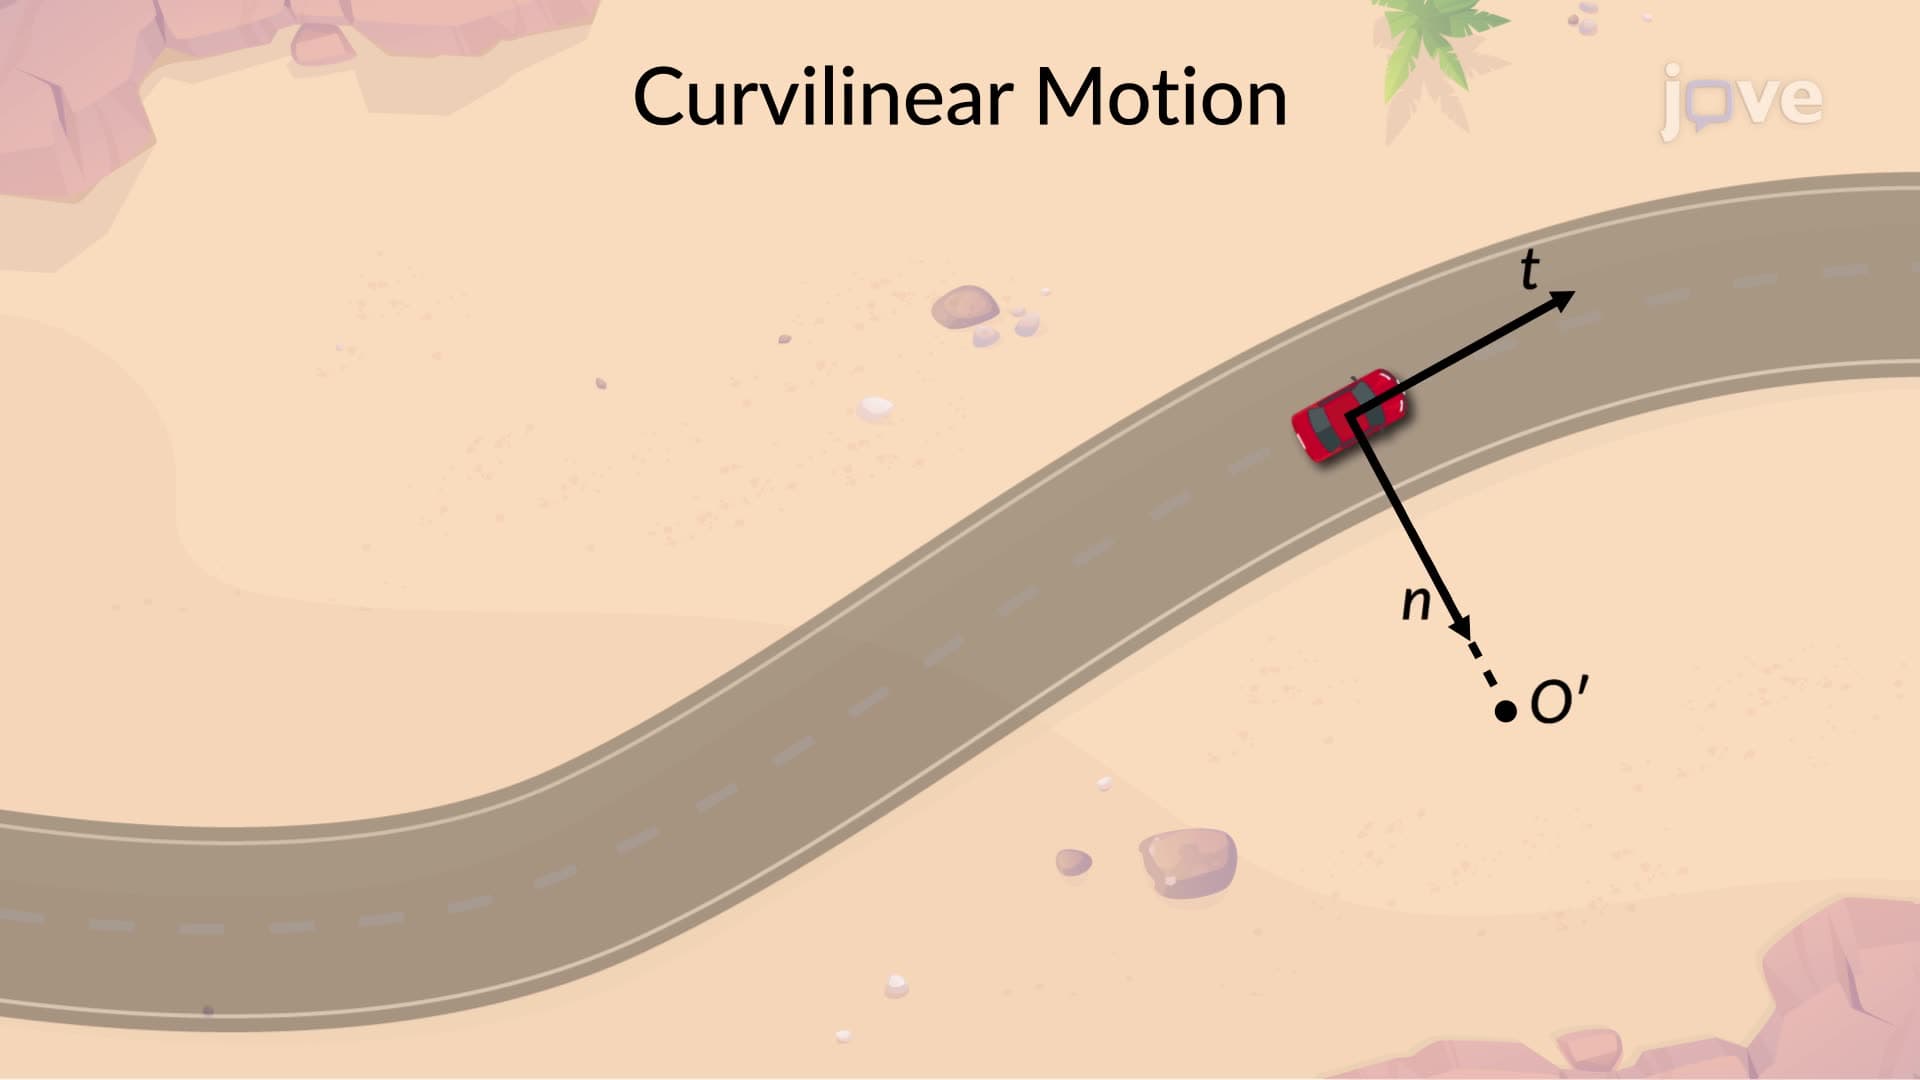
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:12
Transformation of Plane Strain
Under plane strain conditions, typical for members where one dimension significantly exceeds the others, deformations and resultant strains are...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...