Codman's paradox of the arm rotations is not a paradox: mathematical validation
Related Experiment Video
Updated: Oct 28, 2026

Robotic Mirror Therapy System for Functional Recovery of Hemiplegic Arms
Published on: August 15, 2016
J C Politti1, G Goroso, M E Valentinuzzi
1Instituto de Bioingeniería, Facultad de Ciencias Exactas y Tecnología, Universidad Nacional de Tucumán, Argentina.

Abstract:
Movement of a straight arm centred at the shoulder joint in three successive 90 degrees rotations, each around the respective orthogonal coordinate axis, leads to an apparently unrelated 90 degrees rotation around the longitudinal arm axis. This empirical fact is known as Codman's paradox, after a Bostonian surgeon who first reported it in 1934. However, by means of homogeneous coordinates, it is herein demonstrated that the phenomenon is just a mechanical property mathematically described by the equivalence between the matricial product of three orthogonal rotation matrices applied to a position vector and the matricial product of a single rotation matrix applied to the same vector. The latter rotation matrix corresponds to the middle one in the former group of three. When polar coordinates are used, the demonstration is even simpler, for the total shift vector clearly shows a single net effect on the longitudinal axis rotation. Thus, Codman's paradox is not a paradox. This property improves the muscle dynamics arm knowledge and might find applications in robotics.
Related Concept Videos
 01:06
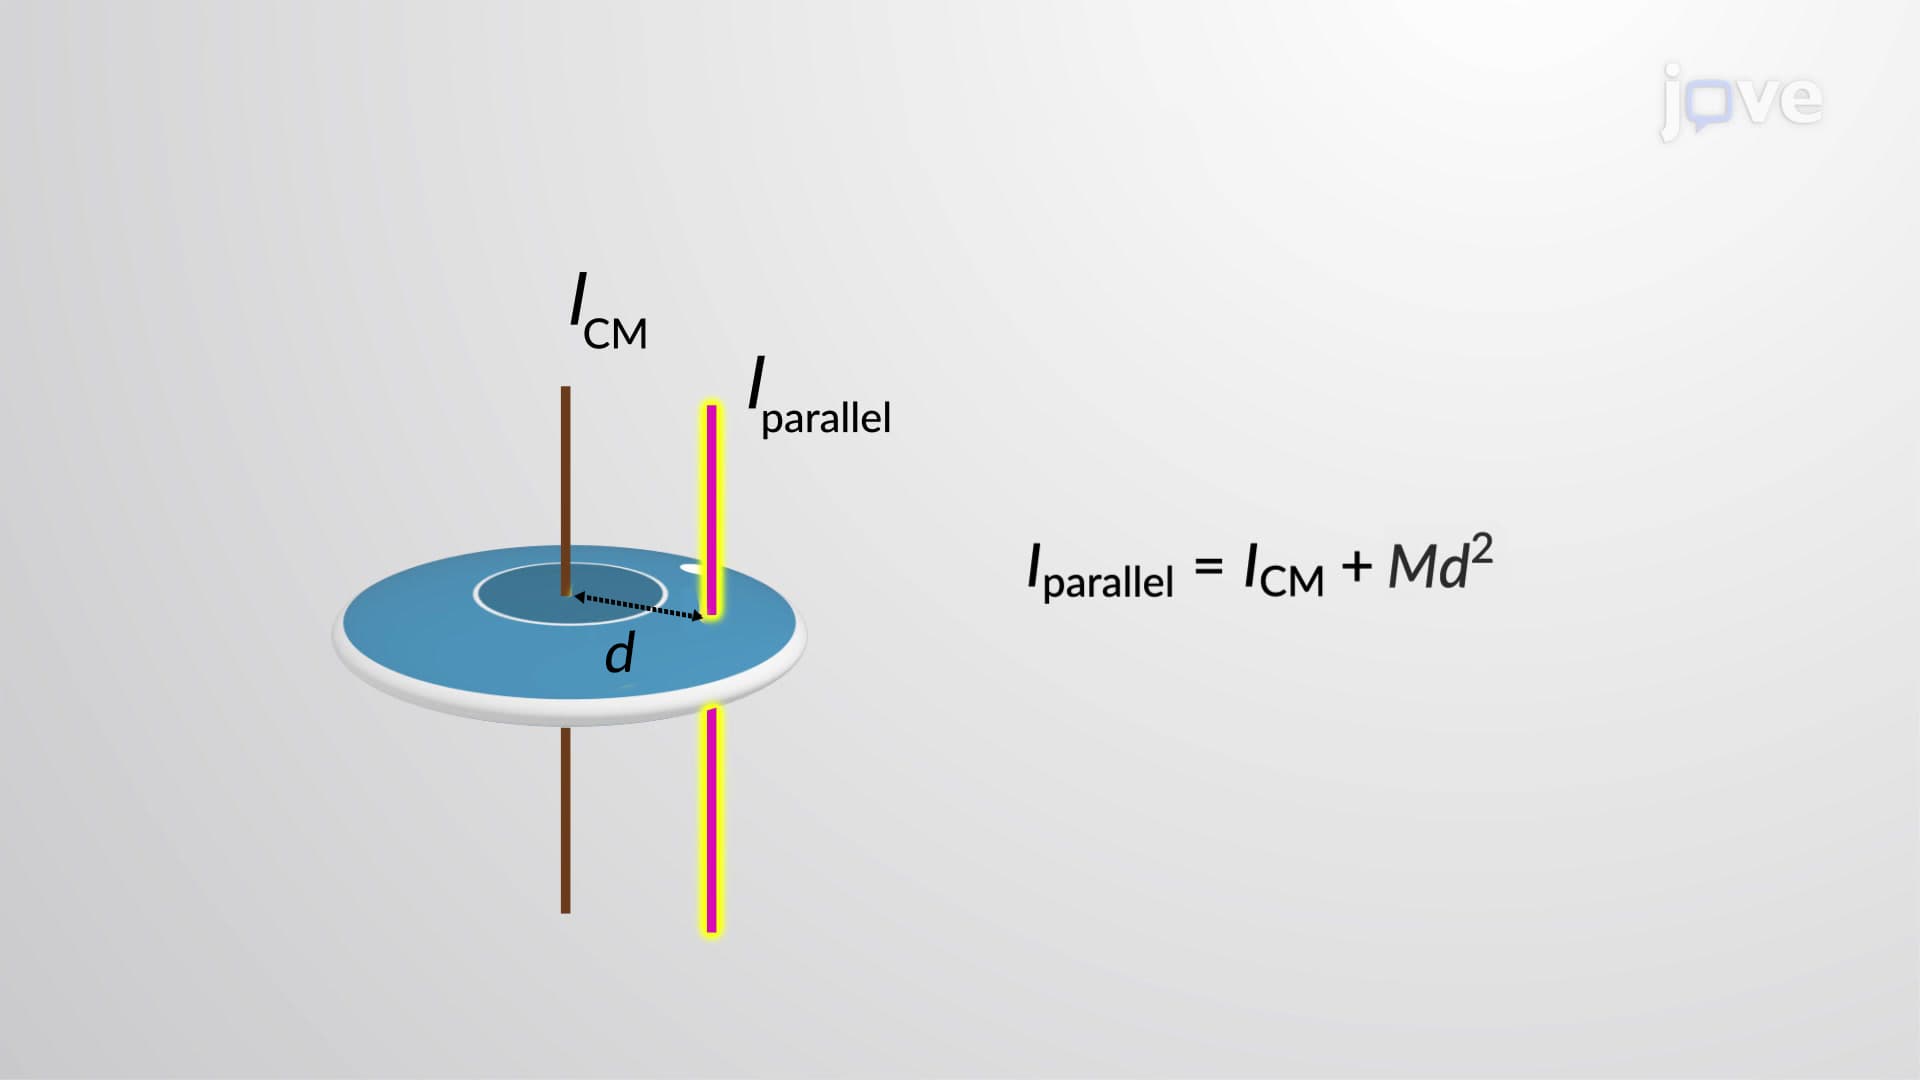
Parallel-axis Theorem
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:11
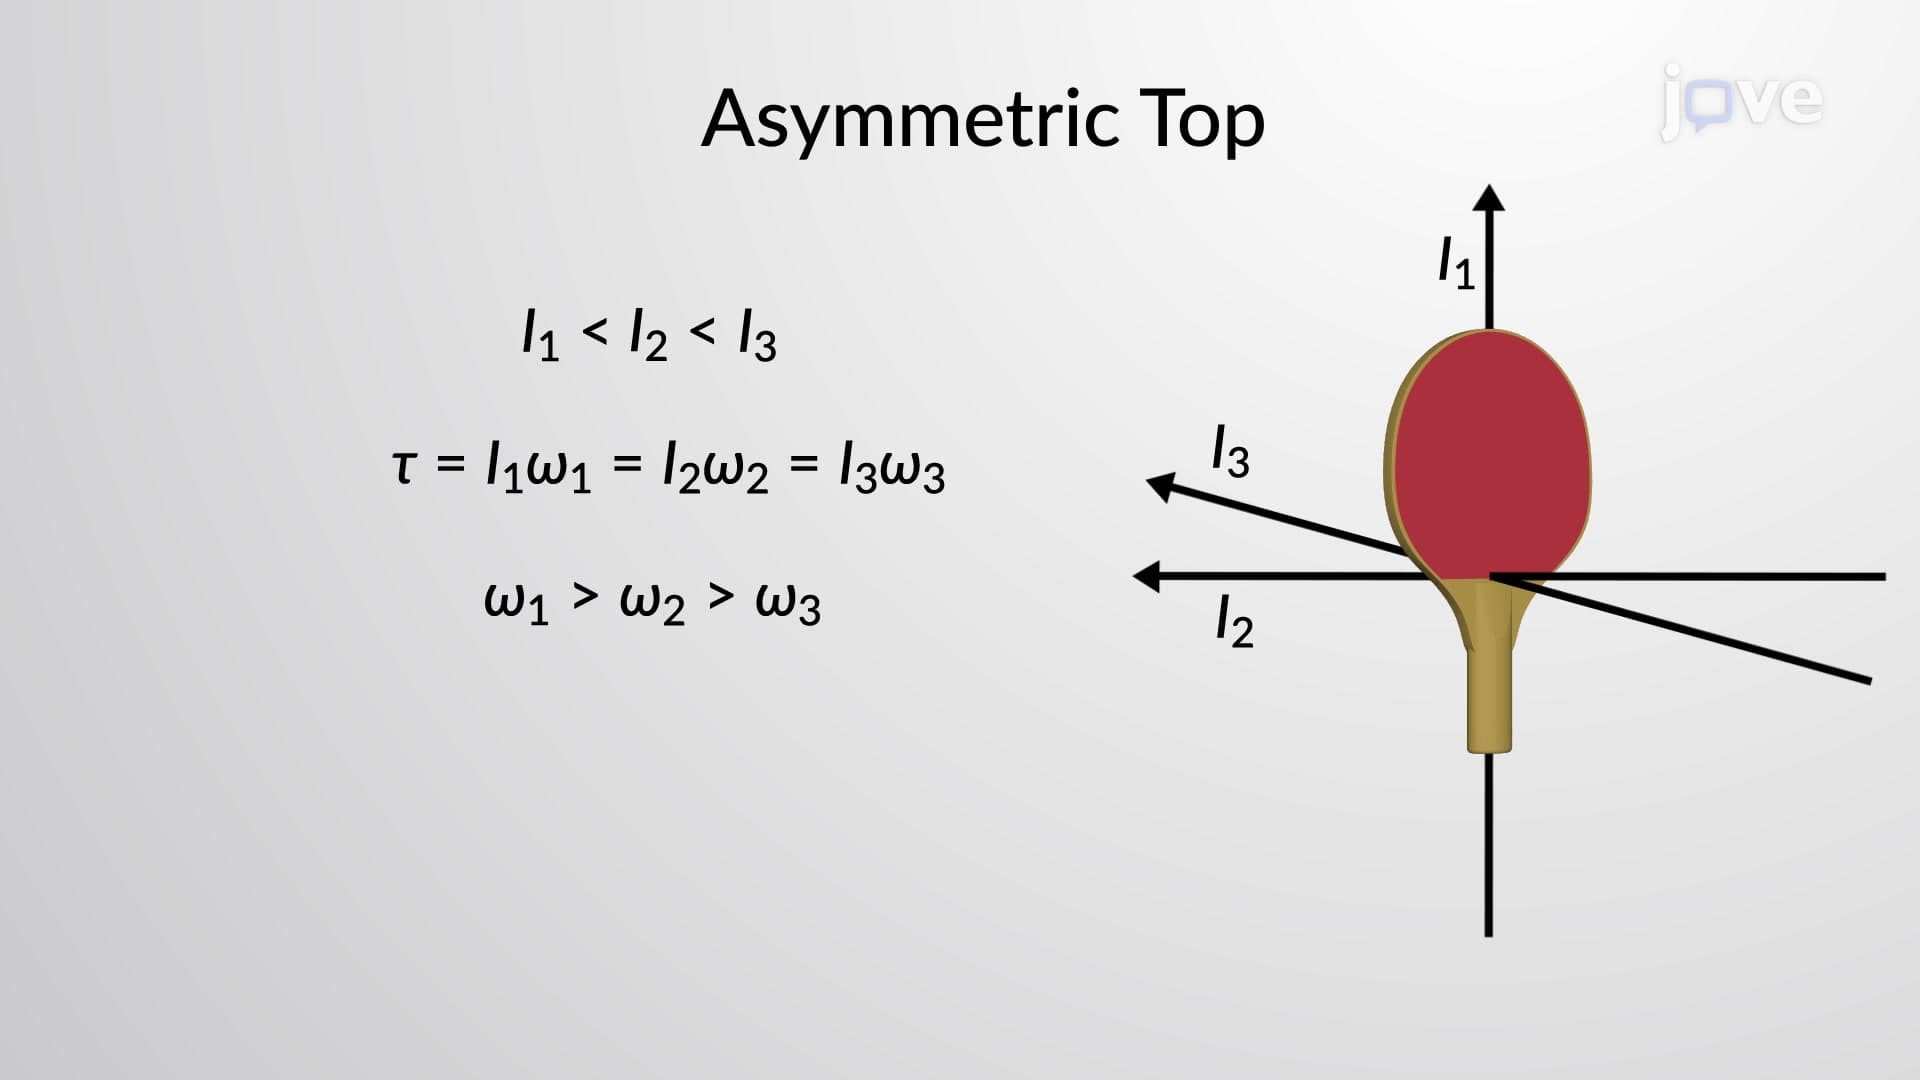
Rotation of Asymmetric Top
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
 01:12
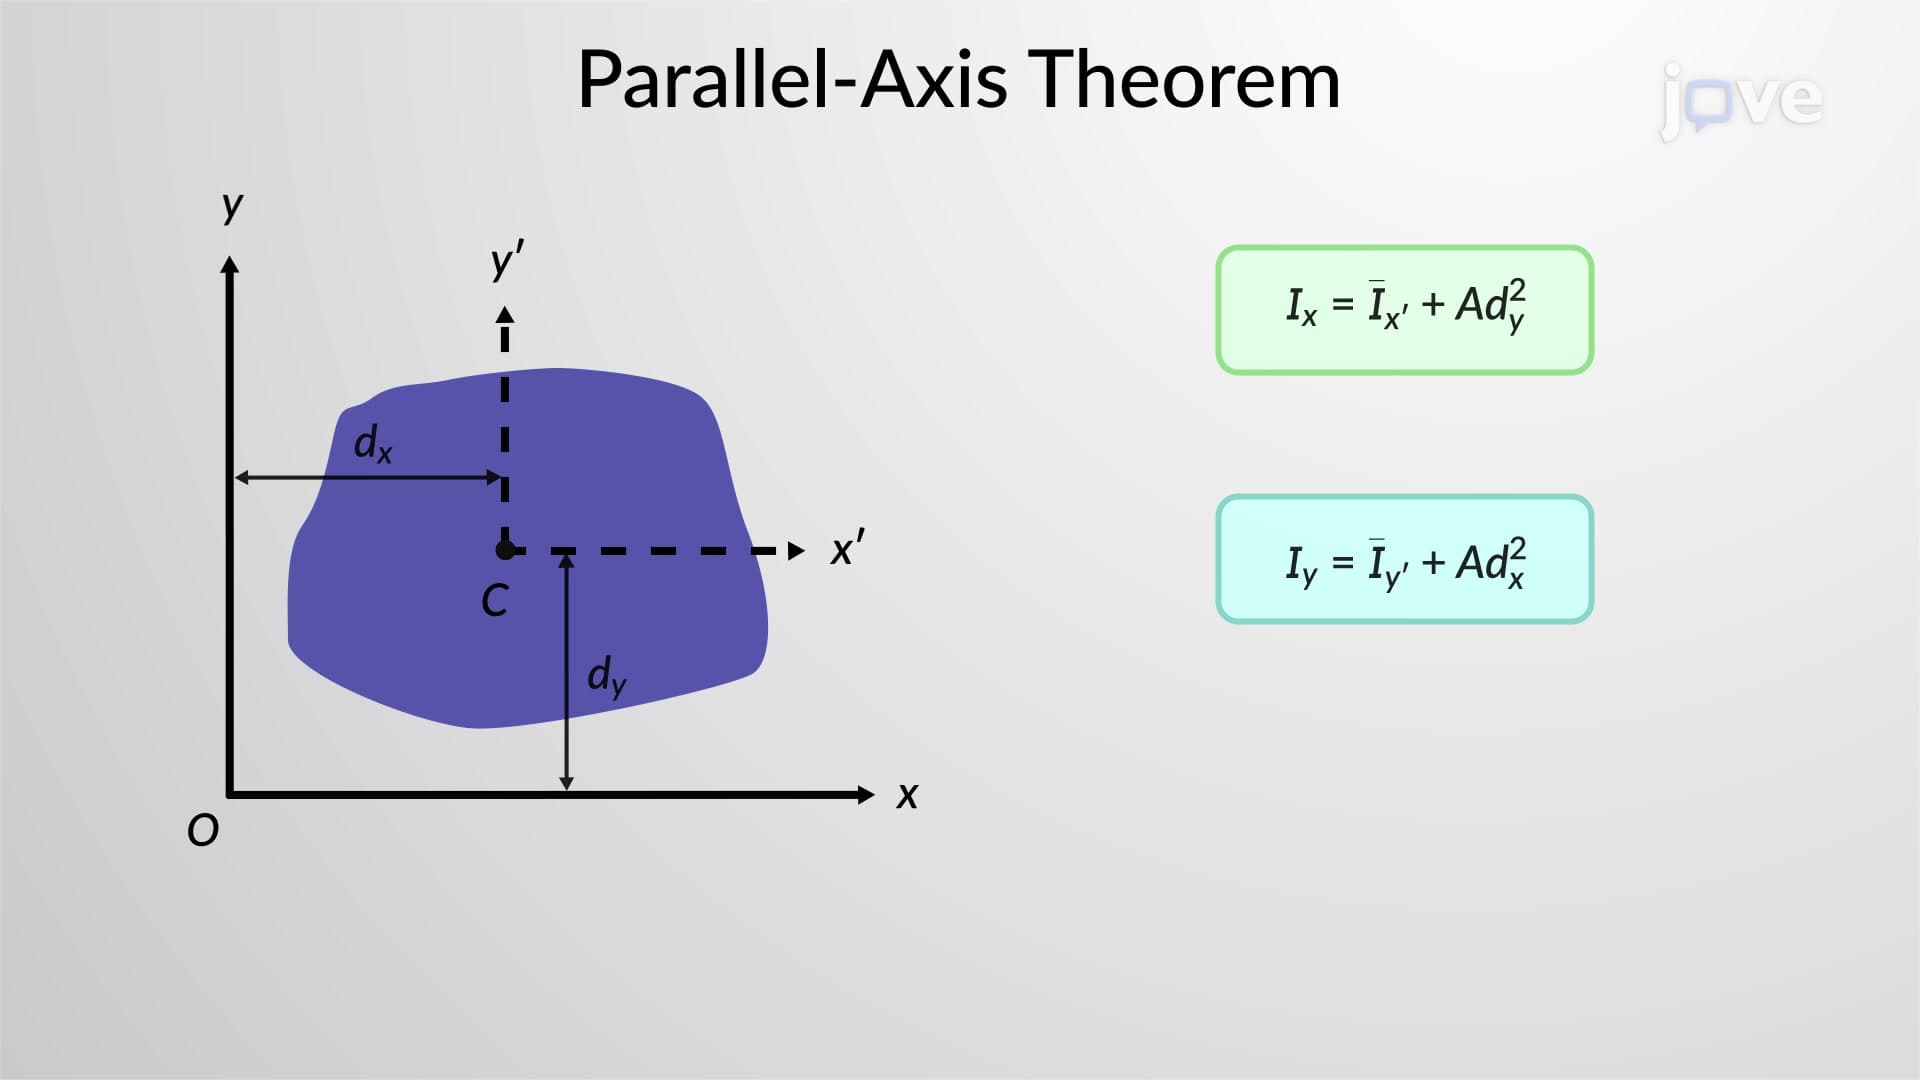
Parallel-Axis Theorem for an Area
For a flywheel approximated as a solid disc, consider an infinitesimal differential element with an arbitrary distance...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:18
Equation of Motion: Rotation About a Fixed Axis
The tangential component is dependent on the direction of the angular acceleration of the flywheel. The tangential component of the acceleration propels the flywheel along its path. On the other hand,...