Neural control of rotational kinematics within realistic vestibuloocular coordinate systems
Related Experiment Video
Updated: Oct 27, 2026
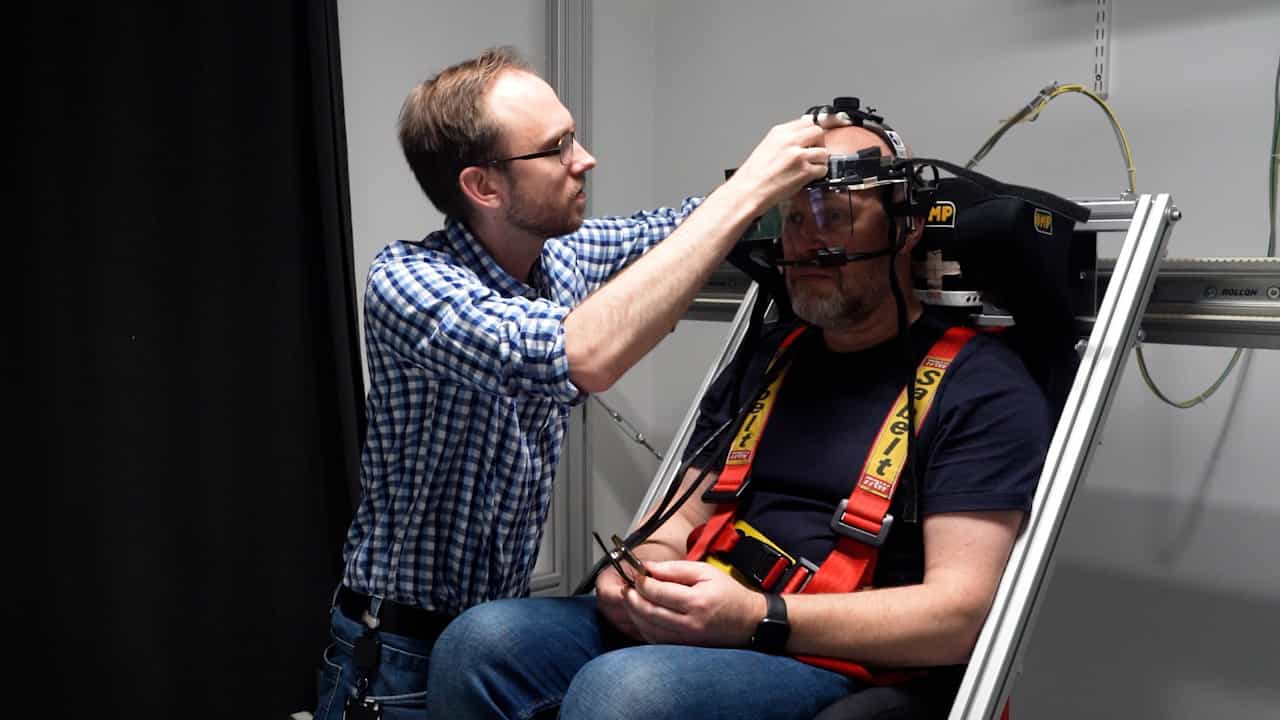
Using Eye-tracking to Assess the Relative Importance of Visual and Vestibular Input to Subcortical Motion Processing in the Roll Plane
Published on: August 22, 2025
1Centre for Vision Research, York University, Toronto, Ontario M3J 1P3, Canada.

Abstract:
Previous theoretical investigations of the three-dimensional (3-D) angular vestibuloocular reflex (VOR) have separately modeled realistic coordinate transformations in the direct velocity path or the nontrivial problems of converting angular velocity into a 3-D orientation command. We investigated the physiological and behavioral implications of combining both approaches. An ideal VOR was simulated using both a plant model with head-fixed eye muscle actions (standard plant) and one with muscular position dependencies that facilitate Listing's law (linear plant). In contrast to saccade generation, stabilization of the eye in space required a 3-D multiplicative (tensor) interaction between the various components of velocity and position in both models: in the indirect path of the standard plant version, but also in the direct path of the linear plant version. We then incorporated realistic nonorthogonal coordinate transformations (with the use of matrices) into both models. Each now malfunctioned, predicting ocular drift/retinal destabilization during and/or after the head movement, depending on the plant version. The problem was traced to the standard multiplication tensor, which was only defined for right-handed, orthonormal coordinates. We derived two solutions to this problem: 1) separating the brain stem coordinate transformation into two (sensory and motor) transformations that reordered and "undid" the nonorthogonalities of canals and muscle transformations, thus ensuring orthogonal brain stem coordinates, or 2) computing the correct tensor components for velocity-orientation multiplication in arbitrary coordinates. Both solutions provided an ideal VOR. A similar problem occurred with partial canal or muscle damage. Altering a single brain stem transformation was insufficient because the resulting coordinate changes rendered the multiplication tensor inappropriate. This was solved by either recomputing the multiplication tensor, or recomputing the appropriate internal sensory or motor matrix to normalize and reorthogonalize the brain stem. In either case, the multiplication tensor had to be correctly matched to its coordinate system. This illustrates that neural coordinate transformations affect not only serial/parallel projections in the brain, but also lateral projections associated with computations within networks/nuclei. Consequently, a simple progression from sensory to motor coordinates may not be optimal. We hypothesize that the VOR uses a dual coordinate transformation (i.e., both sensory and motor) to optimize intermediate brain stem coordinates, and then sets the appropriate internal tensor for these coordinates. We further hypothesize that each of these processes should optimally be capable of specific, experimentally identifiable adjustments for motor learning and recovery from damage.
Related Concept Videos
 01:29
The Vestibular System
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:15
Equilibrium and Balance
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:26
Rotational Motion about a Fixed Axis