Related Experiment Video
Updated: Oct 26, 2026
Computational Modeling of Retinal Neurons for Visual Prosthesis Research - Fundamental Approaches
Published on: June 21, 2022
Nonuniformity in the linear network model of the oculomotor integrator produces approximately fractional-order
1Beckman Institute, University of Illinois at Urbana/Champaign 61801, USA. tja@uiuc.edu

Abstract:
The oculomotor integrator is a network that is composed of neurons in the medial vestibular nuclei and nuclei prepositus hypoglossi in the brainstem. Those neurons act approximately as fractional integrators of various orders, converting eye velocity commands into signals that are intermediate between velocity and position. The oculomotor integrator has been modeled as a network of linear neural elements, the time constants of which are lengthened by positive feedback through reciprocal inhibition. In this model, in which each neuron reciprocally inhibits its neighbors with the same Gaussian profile, all model neurons behave as identical, first-order, low-pass filters with dynamics that do not match the variable, approximately fractional-order dynamics of the neurons that compose the actual oculomotor integrator. Fractional-order integrators can be approximated by weighted sums of first-order, low-pass filters with diverse, broadly distributed time constants. Dynamic systems analysis reveals that the model integrator indeed has many broadly distributed time constants. However, only one time constant is expressed in the model due to the uniformity of its network connections. If the model network is made nonuniform by removing the reciprocal connections to and from a small number of neurons, then many more time constants are expressed. The dynamics of the neurons in the nonuniform network model are variable, approximately fractional-order, and resemble those of the neurons that compose the actual oculomotor integrator. Completely removing the connections to and from a neuron is equivalent to eliminating it, an operation done previously to demonstrate the robustness of the integrator network model. Ironically, the resulting nonuniform network model, previously supposed to represent a pathological integrator, may in fact represent a healthy integrator containing neurons with realistically variable, approximately fractional-order dynamics.
Related Concept Videos
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:21
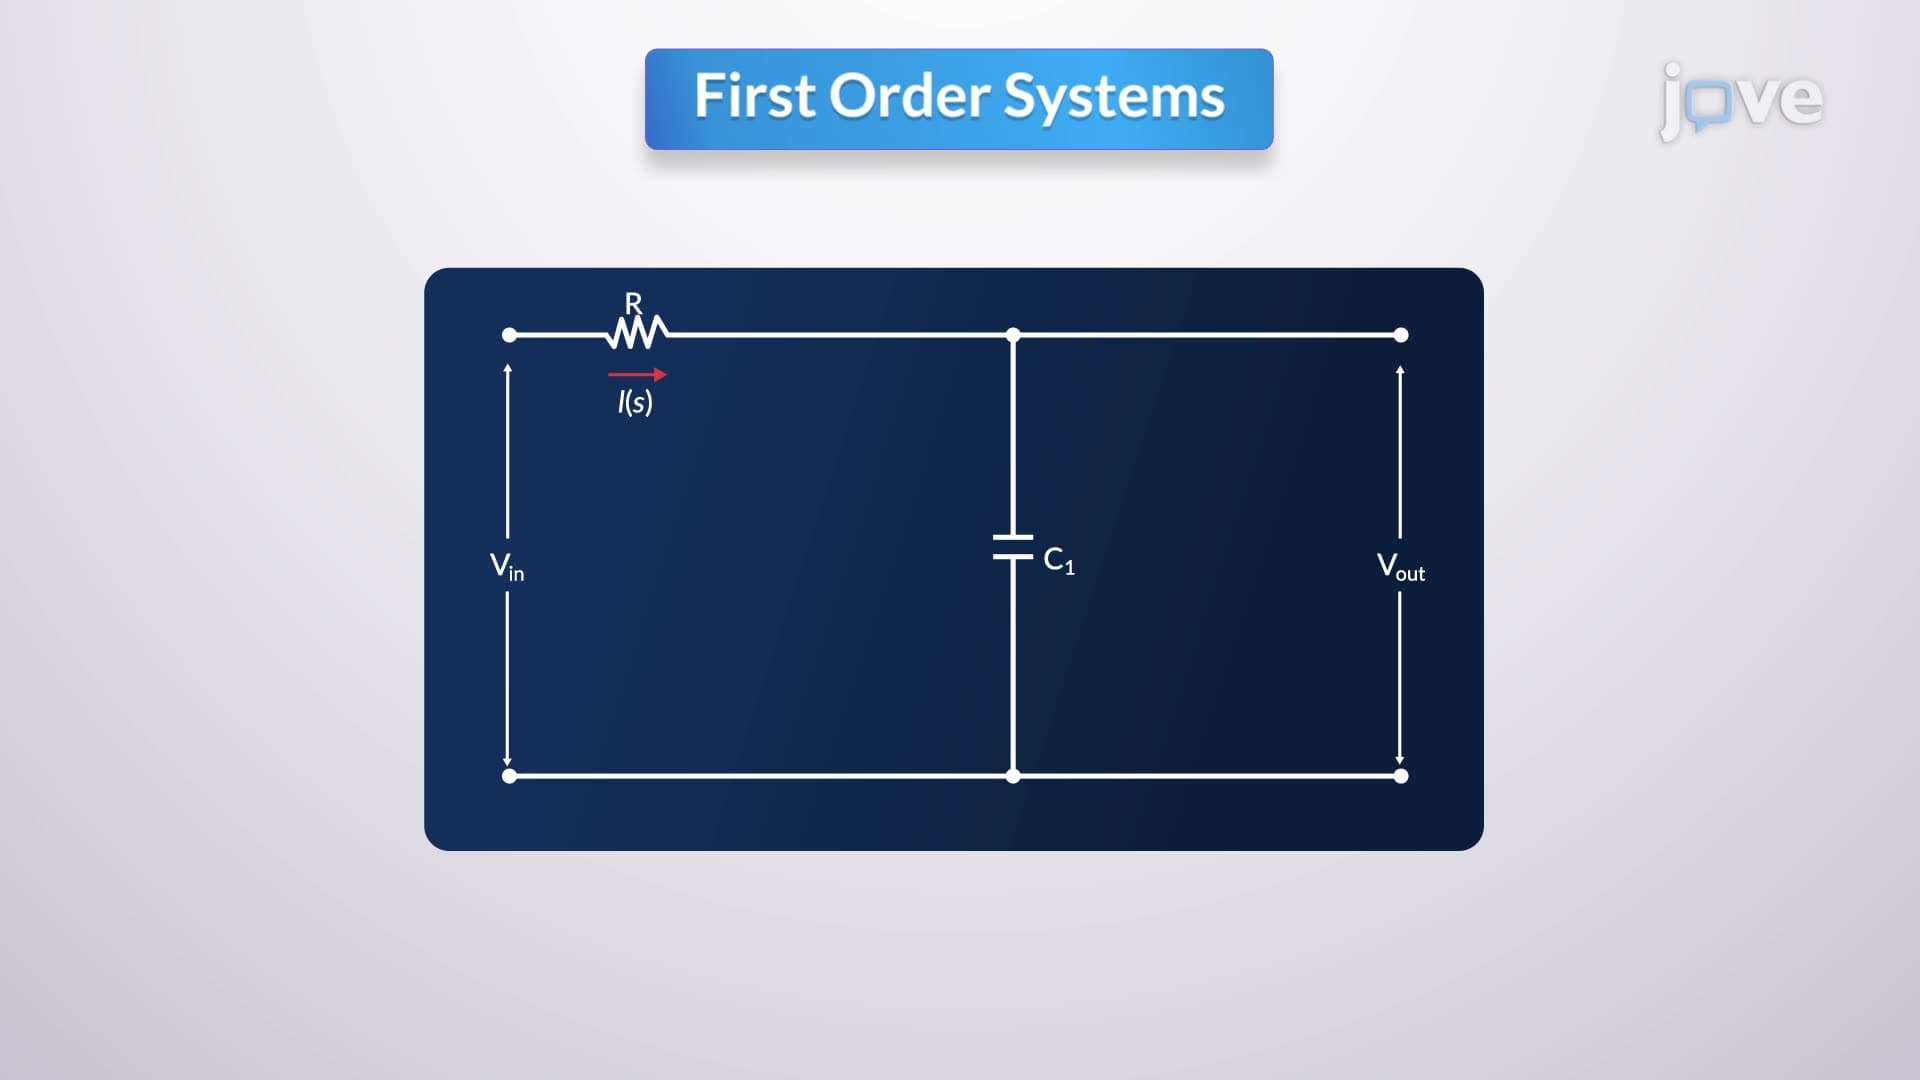
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:26
Classification of Systems-I
Homogeneity dictates that if an input x(t) is multiplied by a constant c, the output y(t) is multiplied by the same constant. Mathematically, this is expressed as:
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...