Predicting error in rigid-body point-based registration
Related Experiment Videos
J M Fitzpatrick1, J B West, C R Maurer
1Department of Computer Science, Vanderbilt University, Nashville, TN 37235, USA. jmf@vuse.vanderbilt.edu

Abstract:
Guidance systems designed for neurosurgery, hip surgery, and spine surgery, and for approaches to other anatomy that is relatively rigid can use rigid-body transformations to accomplish image registration. These systems often rely on point-based registration to determine the transformation, and many such systems use attached fiducial markers to establish accurate fiducial points for the registration, the points being established by some fiducial localization process. Accuracy is important to these systems, as is knowledge of the level of that accuracy. An advantage of marker-based systems, particularly those in which the markers are bone-implanted, is that registration error depends only on the fiducial localization error (FLE) and is thus to a large extent independent of the particular object being registered. Thus, it should be possible to predict the clinical accuracy of marker-based systems on the basis of experimental measurements made with phantoms or previous patients. This paper presents two new expressions for estimating registration accuracy of such systems and points out a danger in using a traditional measure of registration accuracy. The new expressions represent fundamental theoretical results with regard to the relationship between localization error and registration error in rigid-body, point-based registration. Rigid-body, point-based registration is achieved by finding the rigid transformation that minimizes "fiducial registration error" (FRE), which is the root mean square distance between homologous fiducials after registration. Closed form solutions have been known since 1966. The expected value (FRE2) depends on the number N of fiducials and expected squared value of FLE, (FLE-2, but in 1979 it was shown that (FRE2) is approximately independent of the fiducial configuration C. The importance of this surprising result seems not yet to have been appreciated by the registration community: Poor registrations caused by poor fiducial configurations may appear to be good due to a small FRE value. A more critical and direct measure of registration error is the "target registration error" (TRE), which is the distance between homologous points other than the centroids of fiducials. Efforts to characterize its behavior have been made since 1989. Published numerical simulations have shown that (TRE2) is roughly proportional to (FLE2)/N and, unlike (FRE2), does depend in some way on C. Thus, FRE, which is often used as feedback to the surgeon using a point-based guidance system, is in fact an unreliable indicator of registration-accuracy. In this work we derive approximate expressions for (TRE2), and for the expected squared alignment error of an individual fiducial. We validate both approximations through numerical simulations. The former expression can be used to provide reliable feedback to the surgeon during surgery and to guide the placement of markers before surgery, or at least to warn the surgeon of potentially dangerous fiducial placements; the latter expression leads to a surprising conclusion: Expected registration accuracy (TRE) is worst near the fiducials that are most closely aligned! This revelation should be of particular concern to surgeons who may at present be relying on fiducial alignment as an indicator of the accuracy of their point-based guidance systems.
Related Concept Videos
 00:49
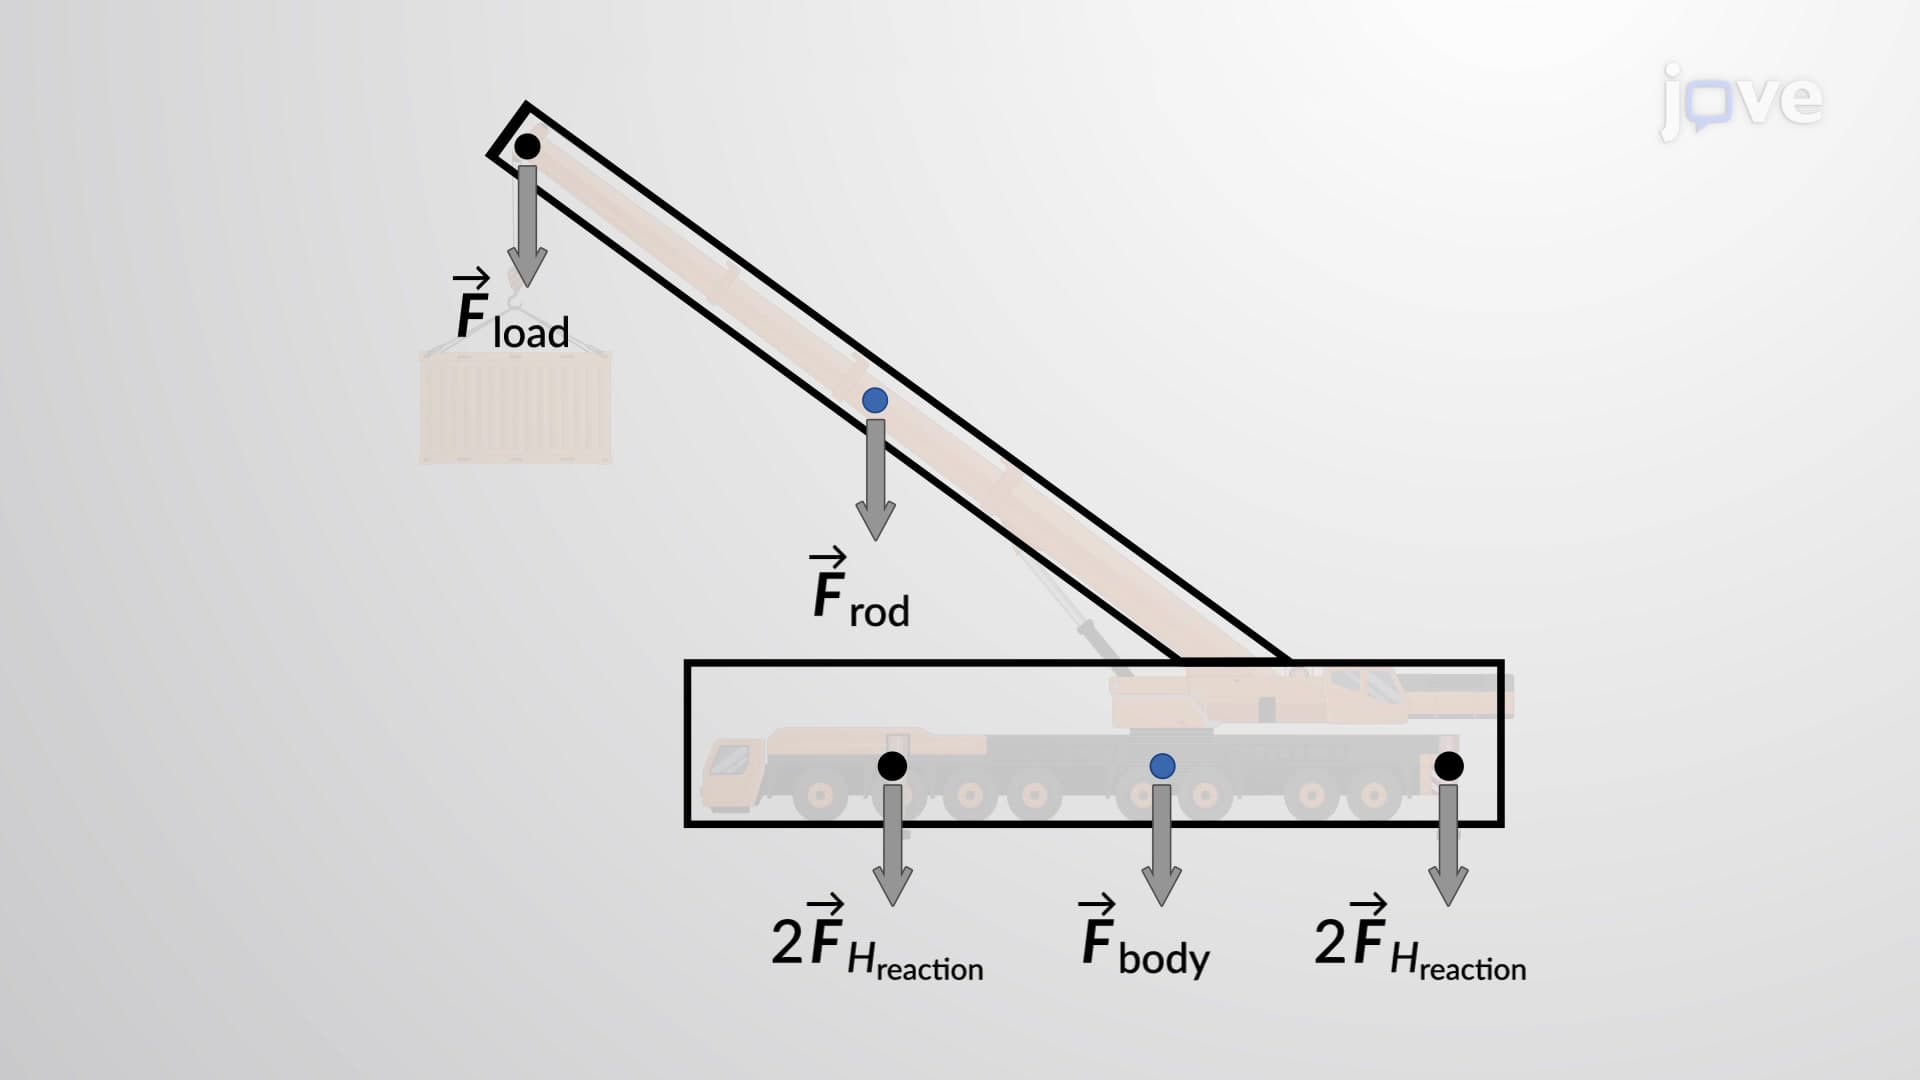
Rigid Body Equilibrium Problems - I
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:12
Equation of Motion for a Rigid Body
The combined moments generated about the center of mass of the object are equal to the rate of change of the angular momentum of the body. An external force, when applied at a different point...
 01:13
Kinetic Energy for a Rigid Body
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:11
Deformation of Member under Multiple Loadings
In the case of a member with a variable cross-section, the strain is not constant but depends on the position. The deformation of an...