Evolution of time coding systems
Related Experiment Video
Updated: Oct 25, 2026
12:03
A Method for Tracking the Time Evolution of Steady-State Evoked Potentials
Published on: May 25, 2019
1Department of Zoology, University of Maryland, College Park, MD 20742, USA. carr@zool.umd.edu
Neural Computation
|February 9, 1999

Abstract:
The auditory and electrosensory systems contain circuits that are specialized for the encoding and processing of microsecond time differences. Analysis of these circuits in two specialists, weakly electric fish and barn owls, has uncovered common design principles and illuminated some aspects of their evolution.
Related Concept Videos
 02:05
Gene Evolution - Fast or Slow?
The genomes of eukaryotes are punctuated by long stretches of sequence which do not code for proteins or RNAs. Although some of these regions do contain crucial regulatory sequences, the vast majority of this DNA serves no known function. Typically, these regions of the genome are the ones in which the fastest change, in evolutionary terms, is observed, because there is typically little to no selection pressure acting on these regions to preserve their sequences.
In contrast, regions which code...
In contrast, regions which code...
02:05Gene Evolution - Fast or Slow?
The genomes of eukaryotes are punctuated by long stretches of sequence which do not code for proteins or RNAs. Although some of these regions do contain crucial regulatory sequences, the vast majority of this DNA serves no known function. Typically, these regions of the genome are the ones in which the fastest change, in evolutionary terms, is observed, because there is typically little to no selection pressure acting on these regions to preserve their sequences.
In contrast, regions which code...
In contrast, regions which code...
 01:23
Linear time-invariant Systems
A system is linear if it displays the characteristics of homogeneity and additivity, together termed the superposition property. This principle is fundamental in all linear systems. Linear time-invariant (LTI) systems include systems with linear elements and constant parameters.
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
 01:31
Classification of Systems-II
Continuous-time systems have continuous input and output signals, with time measured continuously. These systems are generally defined by differential or algebraic equations. For instance, in an RC circuit, the relationship between input and output voltage is expressed through a differential equation derived from Ohm's law and the capacitor relation,
 01:22
Basic Continuous Time Signals
Basic continuous-time signals include the unit step function, unit impulse function, and unit ramp function, collectively referred to as singularity functions. Singularity functions are characterized by discontinuities or discontinuous derivatives.
The unit step function, denoted u(t), is zero for negative time values and one for positive time values, exhibiting a discontinuity at t=0. This function often represents abrupt changes, such as the step voltage introduced when turning a car's...
The unit step function, denoted u(t), is zero for negative time values and one for positive time values, exhibiting a discontinuity at t=0. This function often represents abrupt changes, such as the step voltage introduced when turning a car's...
 01:22
Basic Operations on Signals
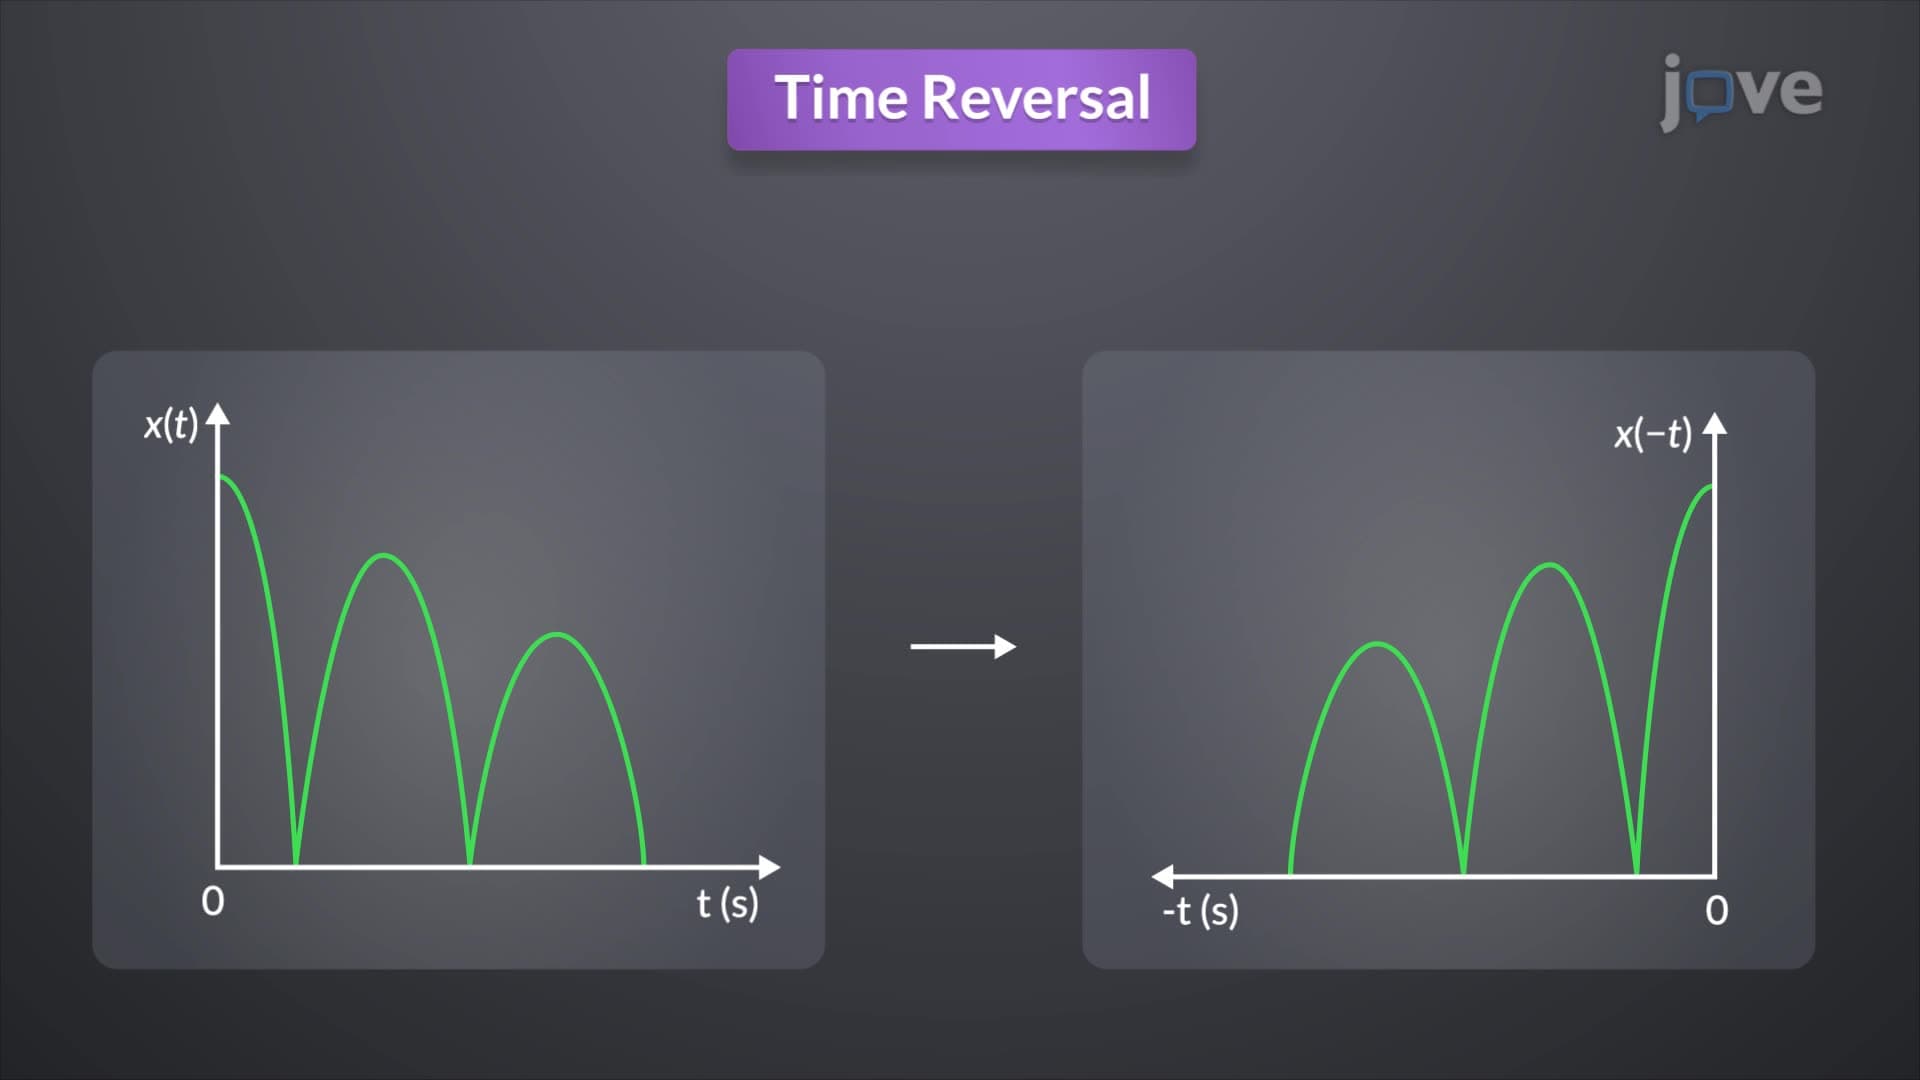
Basic signal operations include time reversal, time scaling, time shifting, and amplitude transformations. These operations are fundamental in signal processing and analysis.
Time Reversal mirrors a continuous-time signal about the vertical axis at t=0. This is achieved by substituting t with −t. For example, if a signal x(t) is considered, the time-reversed signal is x(−t). This operation can be graphically represented, showing the mirrored signal.
Time Reversal mirrors a continuous-time signal about the vertical axis at t=0. This is achieved by substituting t with −t. For example, if a signal x(t) is considered, the time-reversed signal is x(−t). This operation can be graphically represented, showing the mirrored signal.