Standing on a continuously moving platform: is body inertia counteracted or exploited?
Related Experiment Video
Updated: Oct 25, 2026
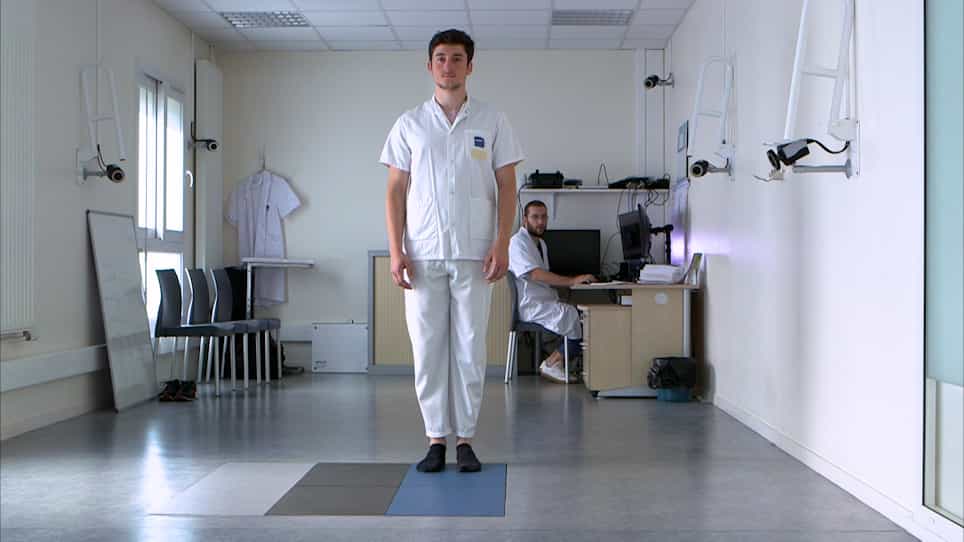
Postural Organization of Gait Initiation for Biomechanical Analysis Using Force Platform Recordings
Published on: July 26, 2022
S Corna1, J Tarantola, A Nardone
1Division of Physical Therapy and Rehabilitation, Rehabilitation Institute of Veruno, Salvatore Maugeri Foundation, IRCCS, Italy.

Abstract:
We describe the characteristics of displacement of the head and hip in normal young subjects standing on a moving platform undergoing continuous sinusoidal horizontal translation in the antero-posterior direction, at frequencies ranging from 0.1-1 Hz. The head, hip and malleolus were marked by light-emitting diodes (LEDs), and the displacement of each LED was quantified by (1) the measure of the shift during each cycle of translation, (2) the standard deviation (SD) of the path travelled during the whole trial, (3) the power spectrum (PS) of the signal and (4) the cross-correlation (CC) between pairs of LED signals. At each frequency of translation, with eyes open (EO), the displacement of head was smaller than that of hip, and the displacement of hip was smaller than that of malleolus. With eyes closed (EC), this order was reversed. The peak value of the CC functions of the pairs malleolus/head, malleolus/hip and hip/head decreased by passing from low to high frequency of translation, under both visual conditions, and decreased more for the pair malleolus/head than malleolus/hip. The lags between body segment displacements ranged between 30 ms and 150 ms, on average, the former segment of each pair preceding the latter. The fast Fourier transformation of hip and head displacement showed a power spectrum peak at the frequency imposed by the platform translation. The peak was larger with EC than EO. With EC, another peak appeared at 0.2 Hz, possibly corresponding to the respiratory frequency. We conclude that, when vision was allowed, subjects behaved as a non-rigid, noninverted pendulum, and stabilised head in space. When vision was denied, head oscillated more than the platform, especially at low translation frequencies. Therefore, the strategy of balance control shifted from a pendulum to an inverted-pendulum behaviour, passing from active head-and-trunk control to maximal body compliance to the perturbation.

Related Concept Videos
 01:22
Equation of Motion: General Plane motion
Moreover, the body's center of mass experiences a rotational effect as a result of these couple moments. This rotation can be articulated as the product of the...
 01:10
Second Law: Motion under Same Force
Let's imagine a person is standing on a weighing...
 01:03
Inertial Frames of Reference
 01:07
Static Equilibrium - II
 01:05
Static Equilibrium - I
 01:12
Equation of Motion for a Rigid Body
The combined moments generated about the center of mass of the object are equal to the rate of change of the angular momentum of the body. An external force, when applied at a different point...