Video Experimental Relacionado
Updated: Jun 15, 2026
08:40
Synthesis of Metal Nanoparticles Supported on Carbon Nanotube with Doped Co and N Atoms and its Catalytic Applications in Hydrogen Production
Published on: December 6, 2021
3.9K
Corrección de "Mecanismo autobifuncional de los nanocables Pt dentados para la cinética de la evolución del hidrógeno
Journal of the American Chemical Society
|May 7, 2021

Resumen
No abstract available in PubMed .
Más Videos Relacionados

Videos de Conceptos Relacionados
 01:25
Multimachine Stability
Multimachine stability analysis is crucial for understanding the dynamics and stability of power systems with multiple synchronous machines. The objective is to solve the swing equations for a network of M machines connected to an N-bus power system.
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
 01:30
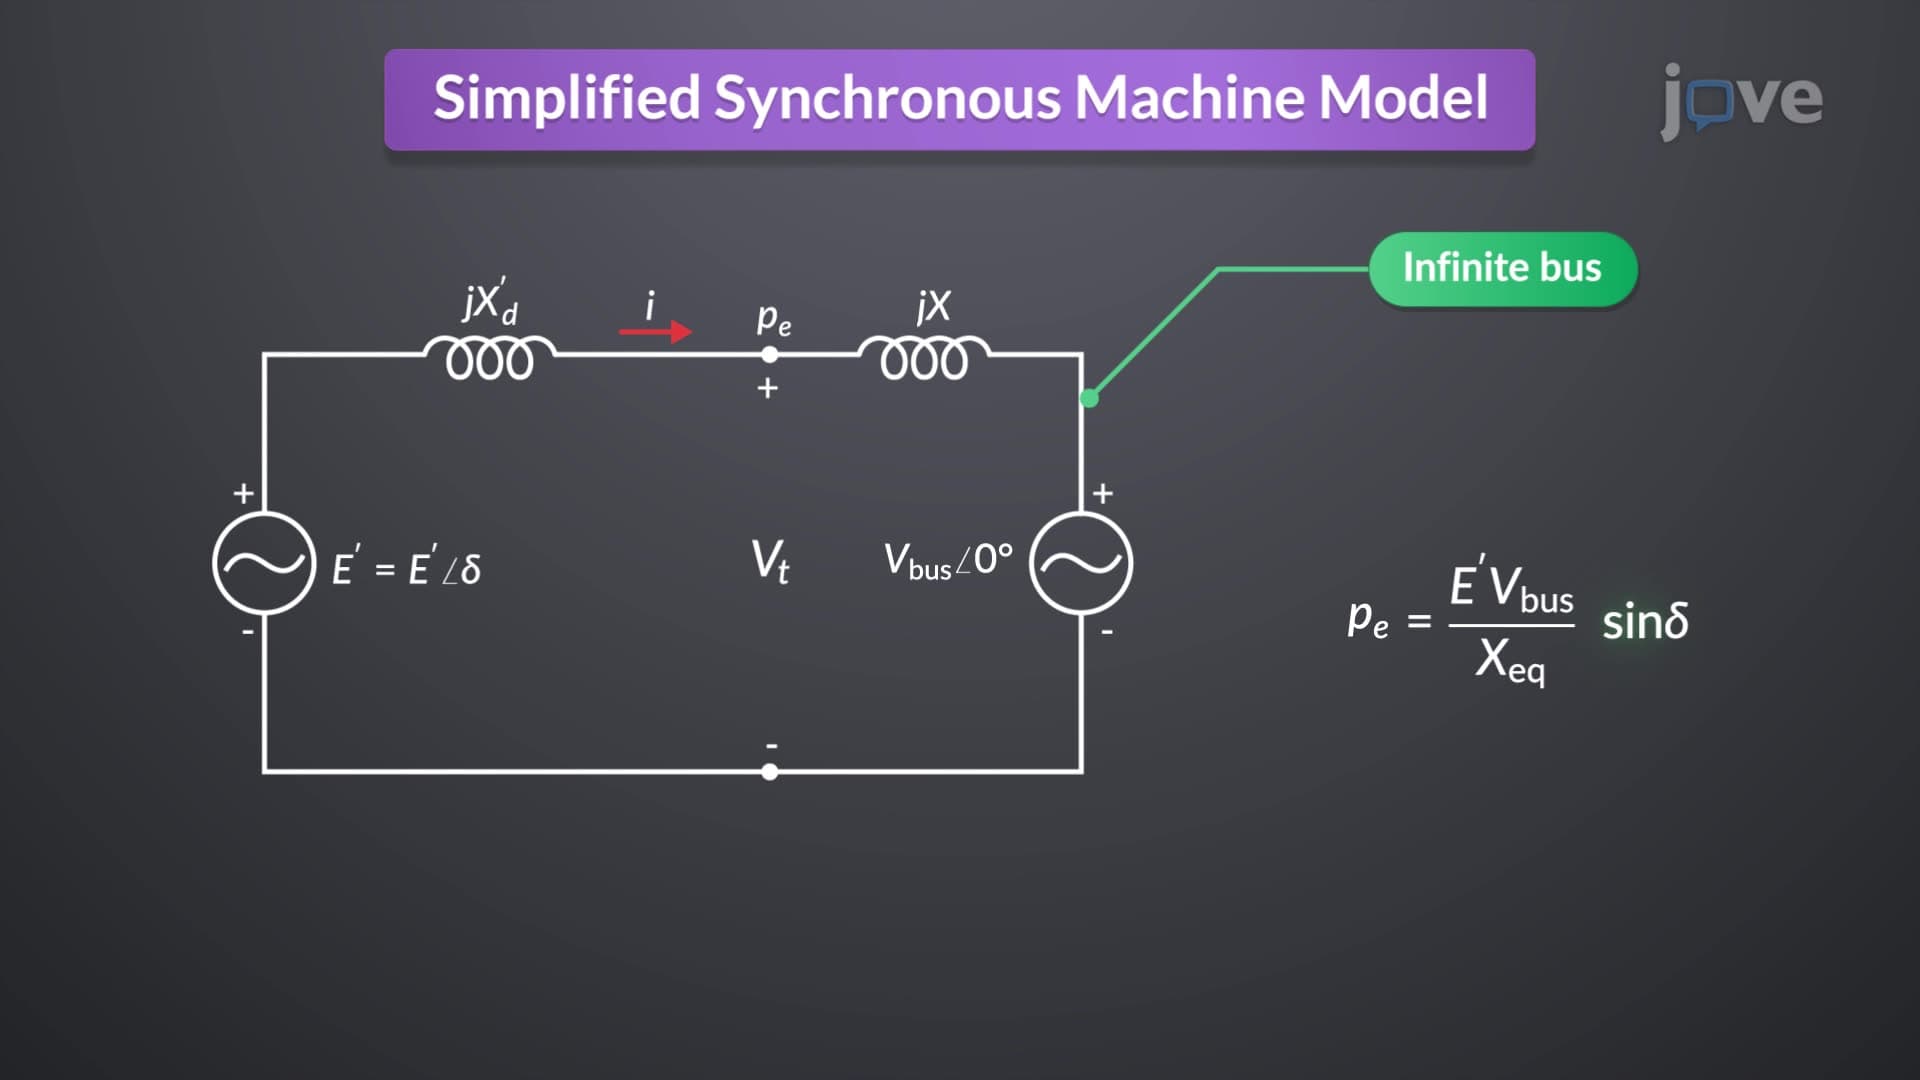
Simplified Synchronous Machine Model
The Synchronous Machine Model is a fundamental tool in analyzing and ensuring the transient stability of power systems. This model simplifies the representation of a synchronous machine under balanced three-phase positive-sequence conditions, assuming constant excitation and ignoring losses and saturation. The model is pivotal for understanding the behavior of synchronous generators connected to a power grid, particularly during transient events.
In this model, each generator is connected to a...
In this model, each generator is connected to a...
 01:07
Time-Domain Interpretation of PD Control
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...