Video Experimental Relacionado
Updated: May 1, 2026
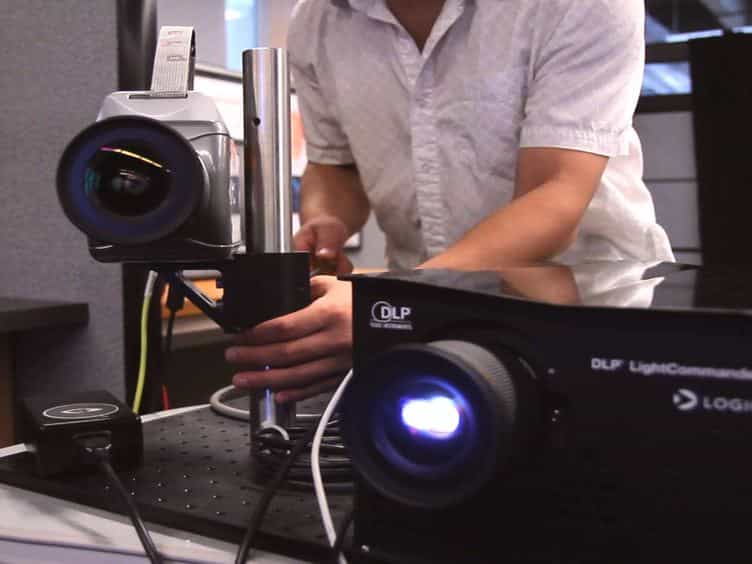

High-resolution, High-speed, Three-dimensional Video Imaging with Digital Fringe Projection Techniques
Published on: December 3, 2013
Verificación de Nubes de Puntos 3D y Eliminación de Dispersión Usando un Configuración Dual de Cámara/Proyector
Jens T Thielemann1, Jostein Thorstensen1
1SINTEF AS, 0373 Oslo, Norway.

Abstract:
This work investigates the properties of 3D imaging in turbid water in context of being able to precisely remove false 3D measurements that are a result of scattering. Such false measurements make object boundaries highly uncertain and limit the usefulness of 3D data. The work is motivated by a need for high-quality 3D image data for underwater robotics, also in turbid waters, where false 3D data can make 3D point cloud algorithms complex and unreliable. Basing ourselves on triangulation-based 3D imaging in turbid water, we show through first-principles analysis how a combination of certain camera/projector geometries and projected patterns allows for the reliable discrimination between true and false 3D measurements. We present an efficient (O1) algorithm capable of rapidly performing this discrimination. Through experiments, we show that we can provide a 50-100× better false positive rate than single-camera algorithms across relevant turbidities, whilst maintaining an almost zero false negative rate. This combination of camera hardware, projected patterns, and algorithms gives a significant robustness improvement of subsea 3D imaging systems, enabling robust and trustworthy 3D imaging.