Predicción de fotogramas intermedios para imágenes integrales de vídeo basada en Triple I-3D Net
Video Experimental Relacionado
Updated: Jan 8, 2026
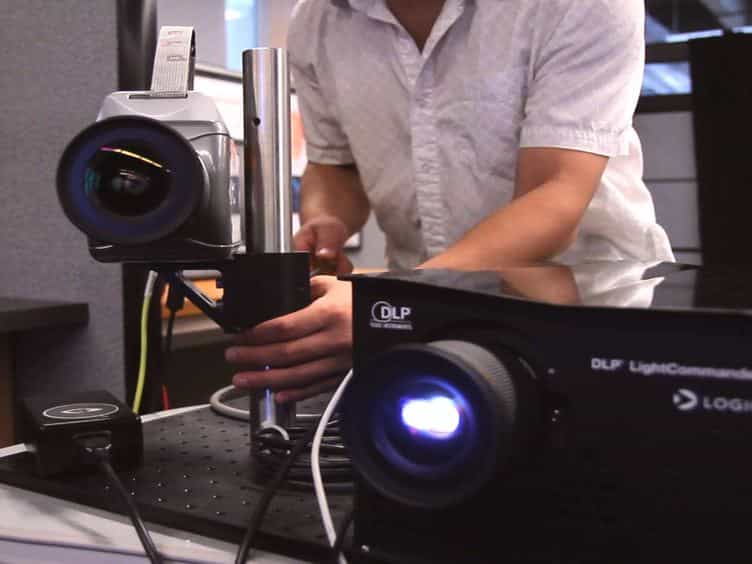
High-resolution, High-speed, Three-dimensional Video Imaging with Digital Fringe Projection Techniques
Published on: December 3, 2013

Abstract:
Integral imaging is a promising three-dimensional (3D) display technology as it can reconstruct full-parallax light fields without causing vergence-accommodation conflicts. However, generating high frame rate element image arrays (EIAs) effectively for 3D videos remains a challenging task. In this study, we propose a novel intermediate frame prediction method for integral imaging using a network called Triple I-3D Net. The proposed method constructs adaptive receptive fields and patches to estimate each pixel's values, ensuring the generated intermediate EIA frames preserve a correct internal optical logic. Additionally, the proposed method incorporates both motion estimation and pixel synthesis within a unified loss function, thereby achieving balanced optimization between the two tasks. By exploiting the intrinsic properties of EIA, our method enables the efficient synthesis of high frame rate sequences without modifying the optical system, thereby significantly enhancing the dynamic performance of 3D display. The experimental results indicate that Triple I-3D Net significantly outperforms other methods, with a maximum improvement of 12.2% in peak signal-to-noise ratio, a 37.8% enhancement in structural similarity index measure, and a 95% boost in learned perceptual image patch similarity. Furthermore, the corrected sample variance across evaluation metrics is reduced by up to 93.5% in the best cases. These results demonstrate that the proposed method realizes accurate frame interpolation for integral imaging and confirms the stability of the interpolated frames.
Videos de Conceptos Relacionados
 01:26
Frames: Problem Solving II
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:24
Frames: Problem Solving I
 01:10
Reconstruction of Signal using Interpolation
 01:03
Inertial Frames of Reference