Video Experimental Relacionado
Updated: Jan 13, 2026


Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Control sin modelo validado en HILS en tiempo real para AUVs mediante control deslizante de modo terminal rápido no
Seongjun Yoo1, Hyuntae Bang1, Wonkeun Youn1
1Department of Autonomous Vehicle System Engineering, Chungnam National University, Daehak-Ro 99, Daejeon, 34134, the Republic of Korea.

Abstract:
This paper proposes a novel adaptive fuzzy nonsingular fast terminal sliding mode control (AFNFTSMC) scheme integrated with time delay control (TDC) for autonomous underwater vehicles (AUVs). The proposed controller enhances robustness and tracking performance by combining the model-free characteristics of TDC with the fast convergence and singularity avoidance of AFNFTSMC. TDC is employed to estimate and compensate for nonlinear dynamics and external disturbances in real time, without requiring an accurate mathematical model. To address the chattering problem inherent in conventional sliding mode control, a fuzzy logic system is integrated, enabling smooth control inputs through continuous adaptation. Using Lyapunov theory, the system is proven to possess global stability and finite-time convergence properties. The effectiveness of the proposed method is validated through numerical simulations using the Delphin2 AUV model under external disturbance conditions.
Más Videos Relacionados
 07:28
A Method for Evaluating Timeliness and Accuracy of Volitional Motor Responses to Vibrotactile Stimuli
Published on: August 2, 2016
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
Videos de Conceptos Relacionados
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:21
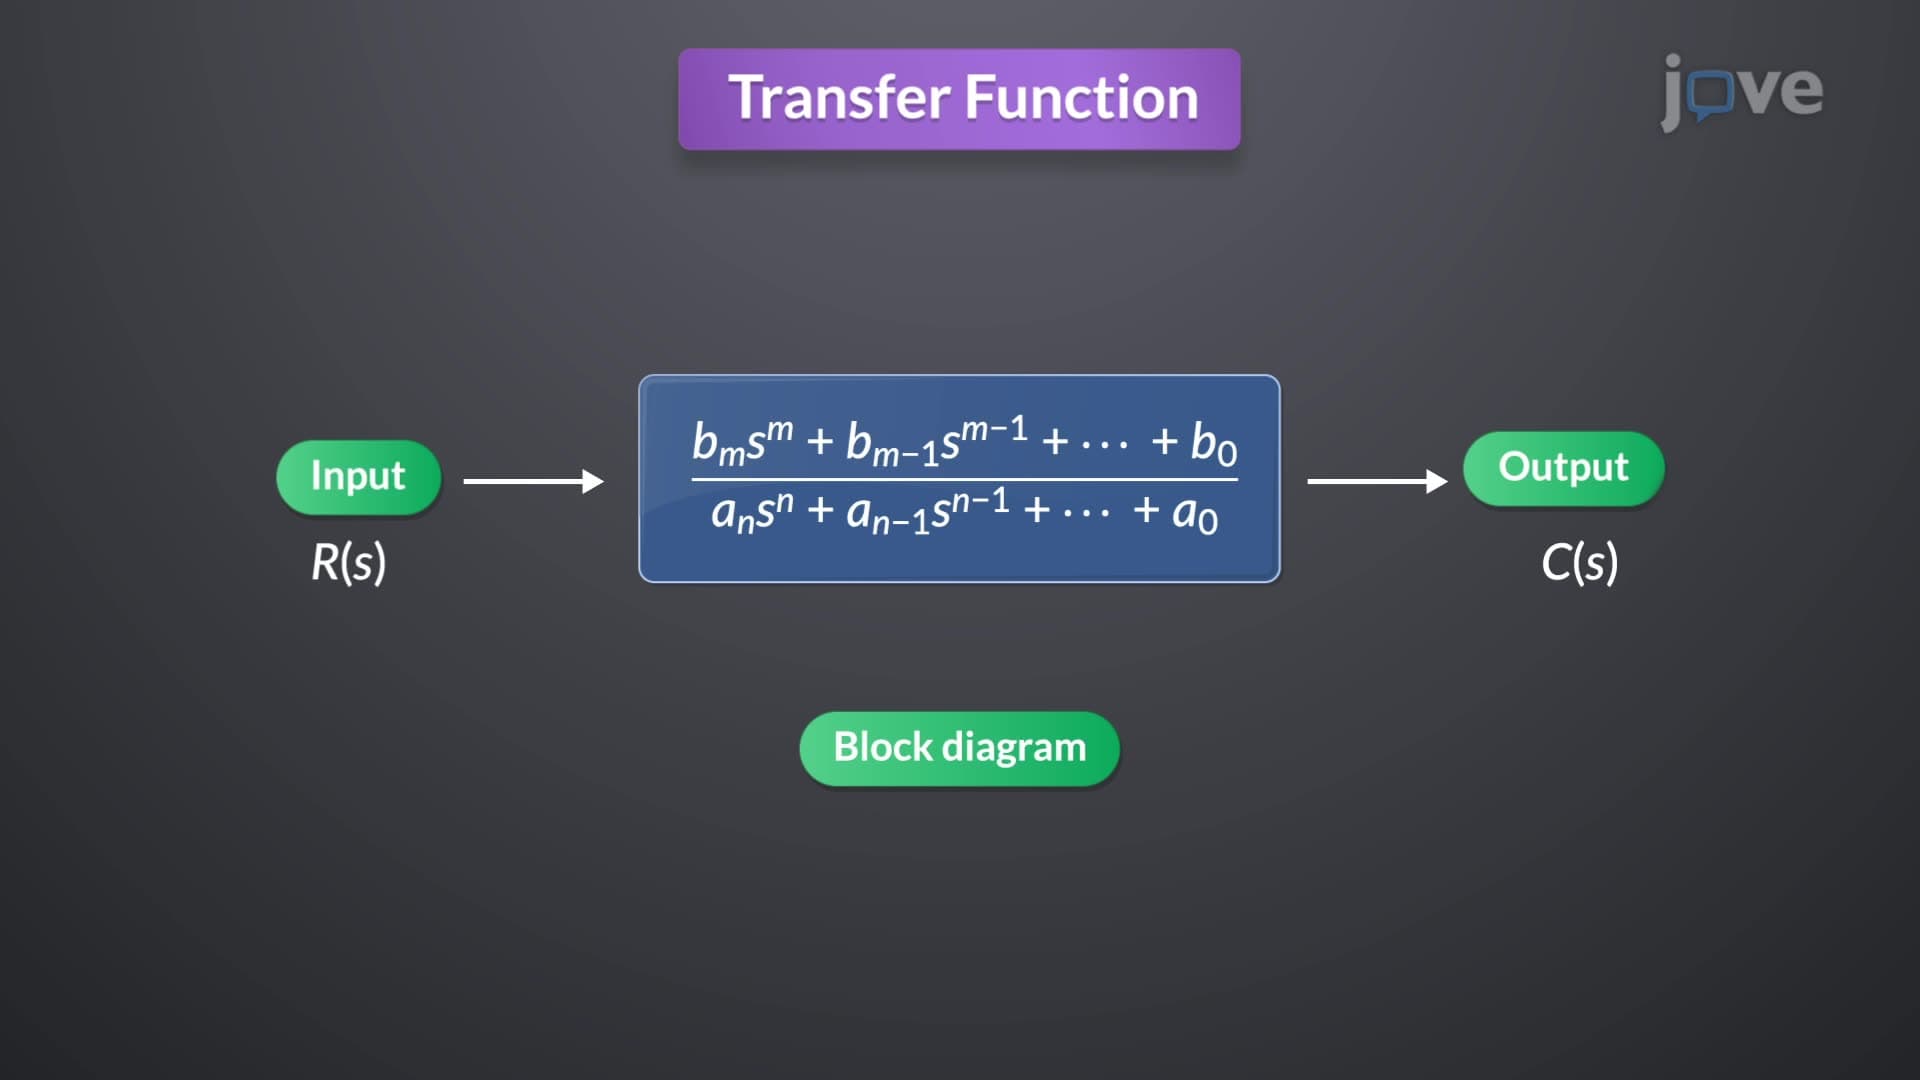
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...