Video Experimental Relacionado
Updated: Jan 18, 2026


The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Control de cabeceo de turbinas eólicas basado en aprendizaje por refuerzo utilizando redes Q profundas dobles
Víctor Espinoza1, Carolina Ormaza2, Christian Tutivén3
1Mechatronics Engineering, Faculty of Mechanical Engineering and Production Sciences,Escuela Superior Politécnica del Litoral, ESPOL, Campus Gustavo Galindo Km. 30.5 Vía Perimetral, Guayaquil, 090902, Ecuador.

Abstract:
This paper presents a novel reinforcement learning-based framework for pitch control in wind turbines, addressing the challenges posed by high nonlinearity and uncertainties in wind dynamics. Traditional pitch control methods, such as proportional-integral controllers, often struggle with adaptability and load mitigation under fluctuating wind conditions. To enhance control efficiency, the proposed framework employs a two-stage approach: policy transfer and policy refinement. In the policy transfer stage, a proportional-integral controller is used to estimate an initial control policy. This policy is then refined using the double deep Q-Network algorithm. Furthermore, a novel reward function is introduced as an improved version of a recent formulation in the literature, ensuring better alignment with practical operational scenarios. Simulations demonstrate that the proposed controller outperforms the industry-standard ROSCO controller, achieving a 15.87% reduction in power fluctuations, while preserving comparable structural load levels, with slight reductions in some cases. These results highlight the potential of reinforcement learning-based control to enhance wind turbine power regulation without compromising structural safety in terms of loads and vibrations.

Videos de Conceptos Relacionados
 01:17
Turbine-Governor Control
 01:24
Wind Turbine Machine Models
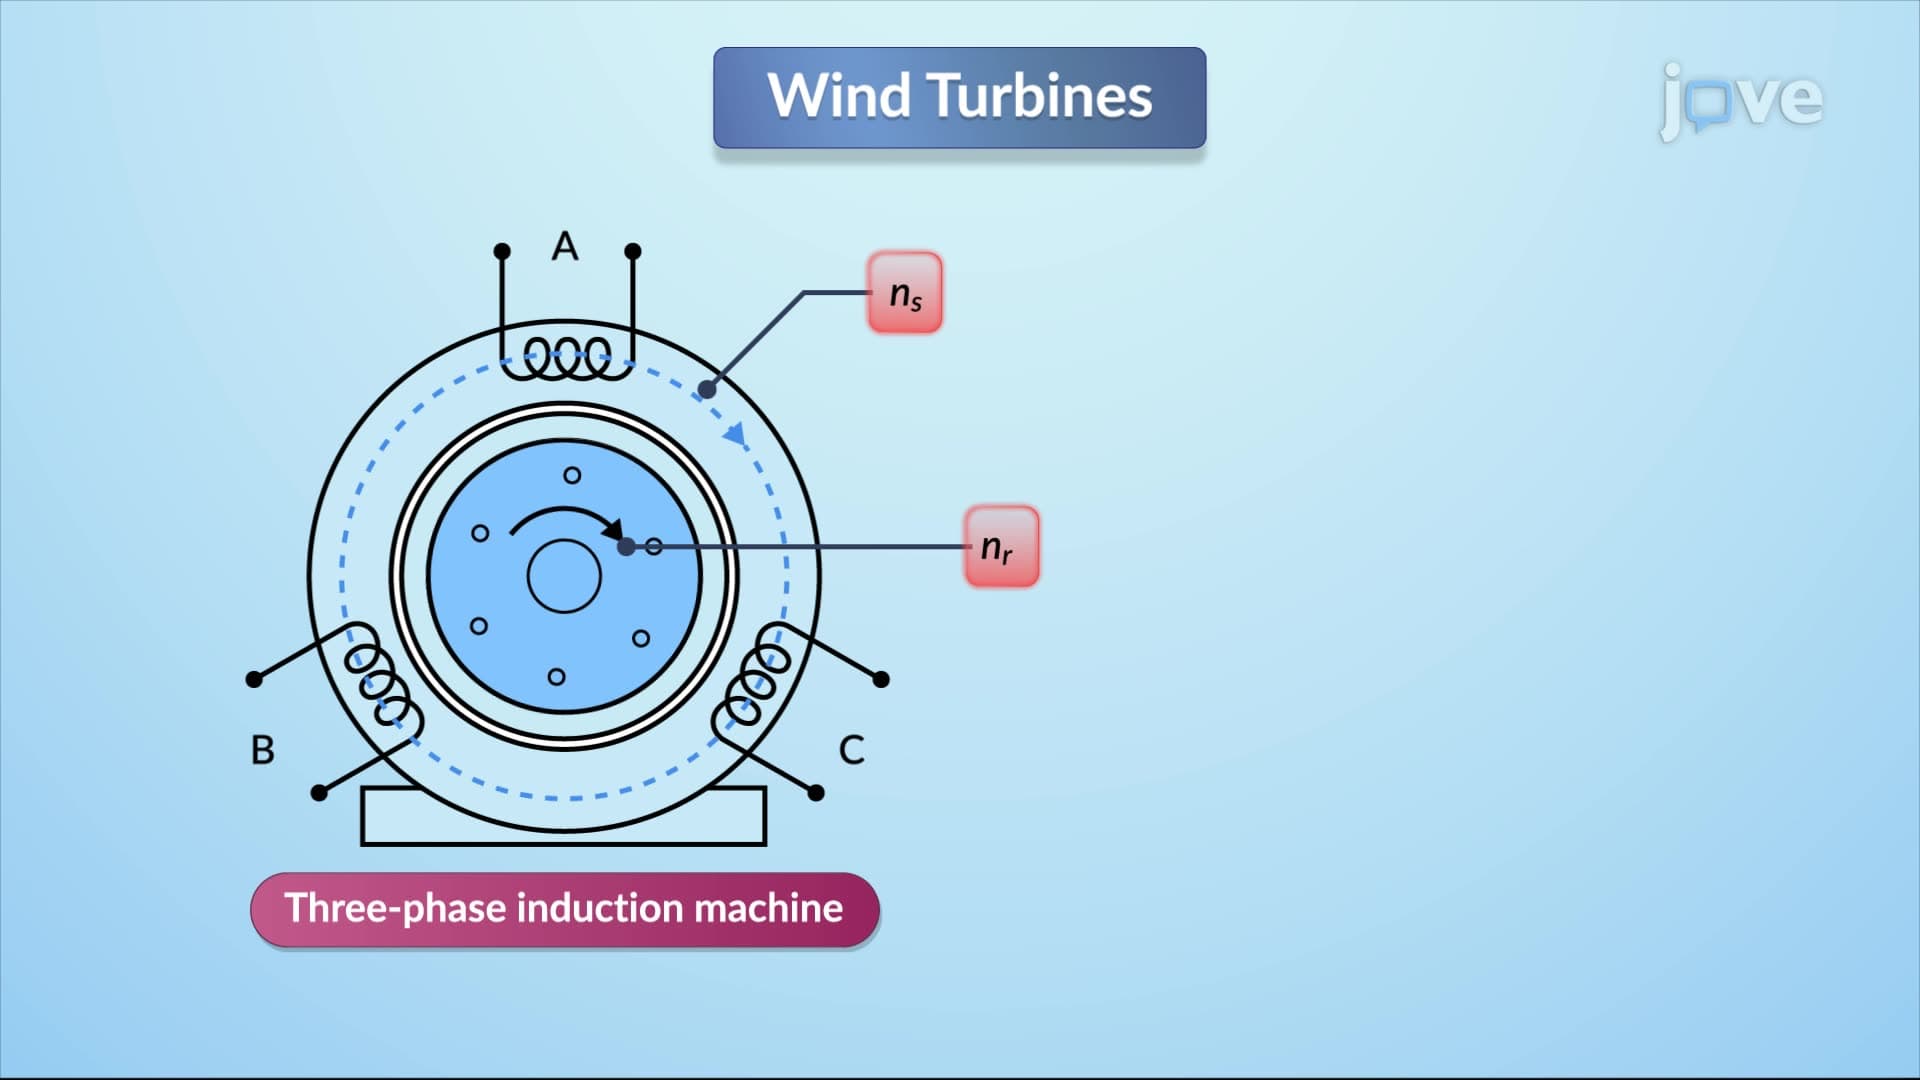
Induction machines interact through the rotating magnetic field generated by the stator and the rotor. The key parameter is slip, which is the difference between synchronous speed and rotor speed relative to synchronous speed. Slip is...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:21
Generator Voltage Control