Video Experimental Relacionado
Updated: Jan 28, 2026
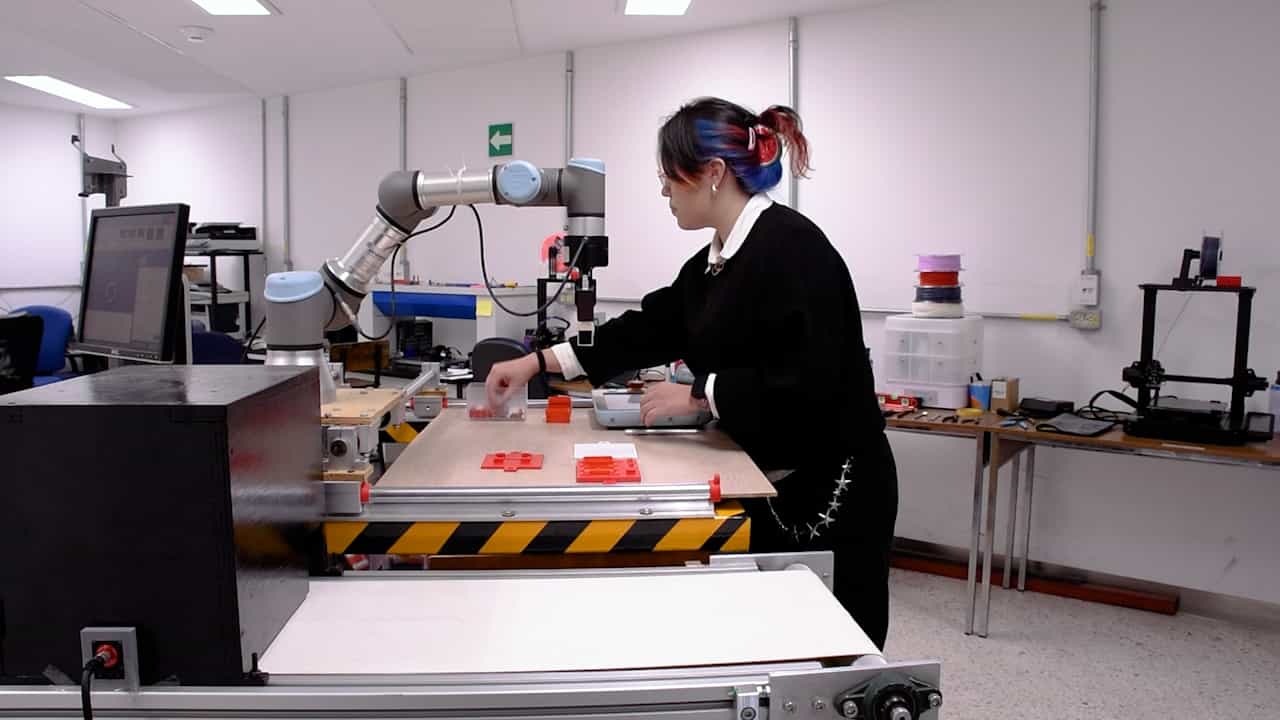
Simulation of a Scaled Assembly Process with Collaboration of a Robotic Arm and Monitoring through a Vision System for Quality Control
Published on: August 29, 2025
Enfoque biomimético para el diseño de transferencia de objetos de robot a humano basada en la confianza en una tarea
1Department of Mechanical Engineering, The Pennsylvania State University, 120 Ridge View Drive, Dunmore, PA 18512, USA.

Abstract:
We presented a biomimetic approach to designing robot-to-human handover of objects in a collaborative assembly task. We developed a human-robot hybrid cell where a human and a robot collaborated with each other to perform the assembly operations of a product in a flexible manufacturing setup. Firstly, we investigated human psychology and biomechanics (kinetics and kinematics) for human-to-robot handover of an object in the human-robot collaborative set-up in three separate experimental conditions: (i) human possessed high trust in the robot, (ii) human possessed moderate trust in the robot, and (iii) human possessed low trust in the robot. The results showed that human psychology was significantly impacted by human trust in the robot, which also impacted the biomechanics of human-to-robot handover, i.e., human hand movement slowed down, the angle between human hand and robot arm increased (formed a braced handover configuration), and human grip forces increased if human trust in the robot decreased, and vice versa. Secondly, being inspired by those empirical results related to human psychology and biomechanics, we proposed a novel robot-to-human object handover mechanism (strategy). According to the novel handover mechanism, the robot varied its handover configurations and motions through kinematic redundancy with the aim of reducing potential impulse forces on the human body through the object during the handover when robot trust in the human was low. We implemented the proposed robot-to-human handover mechanism in the human-robot collaborative assembly task in the hybrid cell. The experimental evaluation results showed significant improvements in human-robot interaction (HRI) in terms of transparency, naturalness, engagement, cooperation, cognitive workload, and human trust in the robot, and in overall performance in terms of handover safety, handover success rate, and assembly efficiency. The results can help design and develop human-robot handover mechanisms for human-robot collaborative tasks in various applications such as industrial manufacturing and manipulation, medical surgery, warehouse, transport, logistics, construction, machine shops, goods delivery, etc.

Videos de Conceptos Relacionados
 01:28
Dosage Regimens: Designs and Approaches
 01:29
Chronic Pancreatitis II: Collaborative Care
Assessment:
 02:01
Group Design
 02:01
Factorial Design
 01:29
Potential Due to a Polarized Object
 01:24
Potential Due to a Magnetized Object
The vector...