Video Experimental Relacionado
Updated: Feb 8, 2026


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Control de alta precisión para una plataforma Stewart con rendimiento prescrito de rechazo de perturbaciones

Abstract:
This article presents a prescribed-performance-controller-based equivalent-input-disturbance approach (PEID) that enhances the disturbance-rejection performance of a Stewart platform. The PEID approach ensures that the disturbance-estimation error converges to a bounded region in a prescribed time. The bound of disturbance-estimation error can be chosen arbitrarily small, and the convergence time of disturbance-estimation error can be prescribed in advance. Stability conditions are derived by dividing the PEID-based control system into three subsystems, and a barrier Lyapunov function is used to design a prescribed-performance-controller-based compensator. An algorithm for designing system parameters devises state feedback and observer gains. The experiments conducted on a Stewart platform validate the effectiveness and superiority of the PEID approach.
Más Videos Relacionados
Videos de Conceptos Relacionados
 02:26
Ecological Disturbance
 01:29
Disturbances in Heart Rhythm
Arrhythmias are categorized by their speed, rhythm, and origin. A slow heart...
 03:37
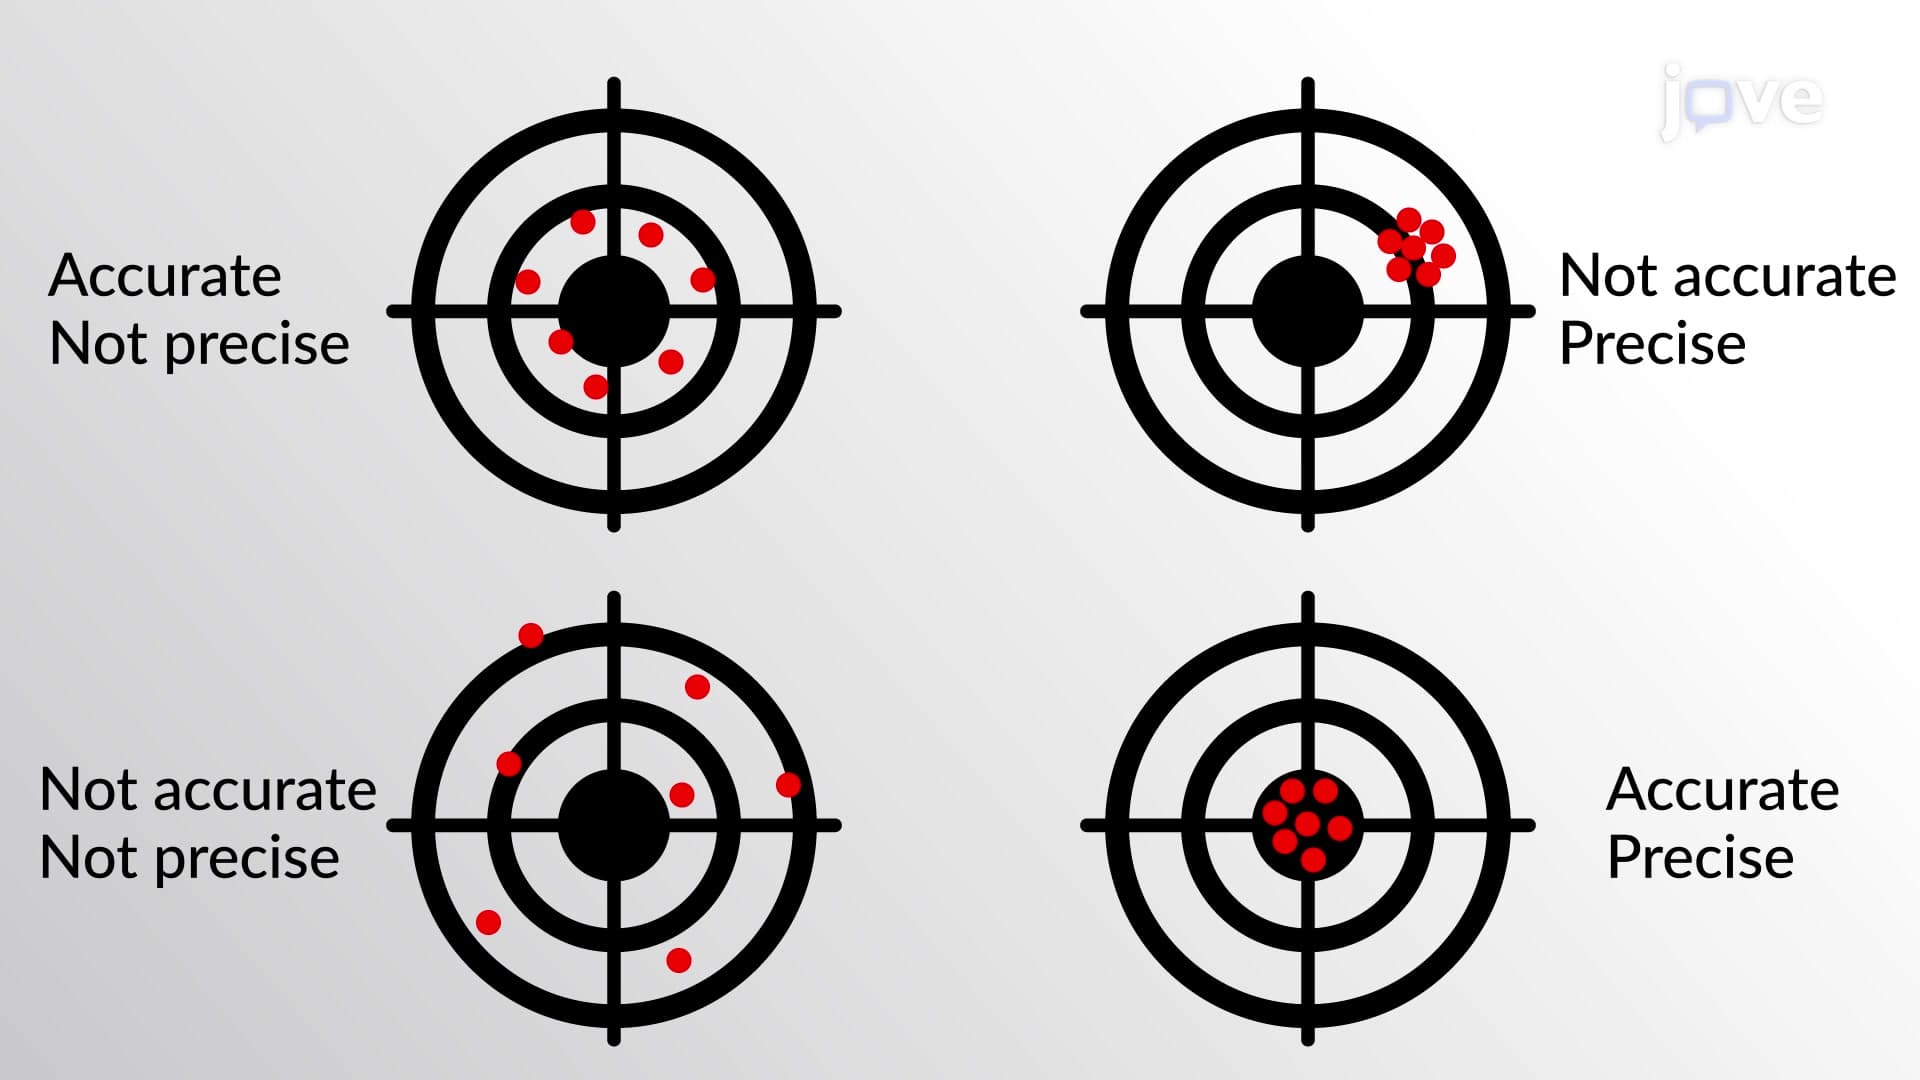
Uncertainty in Measurement: Accuracy and Precision
 01:17
Hypothesis: Accept or Fail to Reject?
There are two ways to indicate that the null hypothesis is not rejected. 'Accept' the null...
 01:02
Quantifying and Rejecting Outliers: The Grubbs Test
 01:52
Accuracy and Precision