Video Experimental Relacionado
Updated: Feb 13, 2026
10:19

3D Kinematic Gait Analysis for Preclinical Studies in Rodents
Published on: August 3, 2019
11.4K
Coordinación cinemática y patrones de sinergia muscular de agarre durante la locomoción de las extremidades

Resumen
El control motor humano integra la locomoción de las extremidades inferiores y el agarre de las extremidades superiores. Las tareas cooperativas muestran una fuerte coordinación entre extremidades, combinando patrones de movimiento existentes a nivel articular y muscular.
Área de la Ciencia:
- La biomecánica es la biomecánica.
- La neurociencia es la neurociencia.
- El control del motor es el control del motor.
Sus antecedentes:
- El movimiento humano a menudo implica acciones rítmicas simultáneas de las extremidades inferiores y voluntarias de las extremidades superiores.
- Comprender los mecanismos de control para estas tareas cooperativas es crucial para campos como la robótica y la rehabilitación.
Objetivo del estudio:
- Investigar las estrategias de sinergia a nivel articular y muscular durante las tareas motoras cooperativas.
- Explorar cómo la locomoción de las extremidades inferiores y el agarre de las extremidades superiores interactúan y se controlan.
Principales métodos:
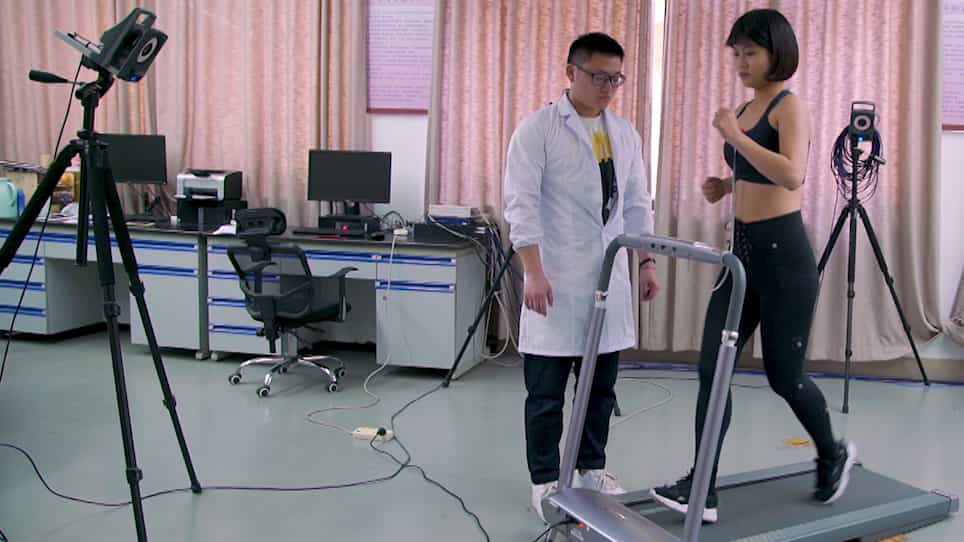
- Se diseñaron nuevos experimentos motores para analizar las características cinemáticas, los ángulos de las articulaciones y las señales de electromiografía (EMG).
- El análisis de componentes principales (PCA) y la factorización de matriz no negativa (NMF) se utilizaron para extraer primitivas cinemáticas y sinergias musculares.
Principales resultados:
- Las tareas cooperativas demostraron una dependencia significativa de la posición de agarre en los mecanismos de sinergia cinemática y muscular.
- Se encontraron fuertes correlaciones entre los coeficientes de peso de sinergia y las características cinemáticas.
- Las tareas cooperativas integran sinergias musculares preexistentes de tareas individuales, con los componentes de las extremidades inferiores en gran medida preservados y los componentes de las extremidades superiores a veces alterados.
Conclusiones:
- Las tareas cooperativas crean un acoplamiento funcional entre los movimientos de las extremidades inferiores y superiores a nivel de las articulaciones y los músculos.
- Estas acciones combinadas exhiben una mayor coordinación entre miembros en comparación con las tareas voluntarias individuales.
- El estudio proporciona nuevos paradigmas experimentales y conocimientos sobre la coordinación entre los miembros humanos y el control del movimiento.
Más Videos Relacionados
Videos de Conceptos Relacionados
 01:24
Muscle Coordination and Action
3.2K
Muscle coordination is a complex and finely tuned process essential for smooth and purposeful movements like flexion, extension, adduction, abduction, and rotation. The human body orchestrates the actions of various muscles working in concert, each with a specific role. Four functional types describe how muscles work together: agonist, antagonist, synergist, and fixator.
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement....
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement....
3.2K
 02:57
Coordination Number and Geometry
19.1K
For transition metal complexes, the coordination number determines the geometry around the central metal ion. Table 1 compares coordination numbers to molecular geometry. The most common structures of the complexes in coordination compounds are octahedral, tetrahedral, and square planar.
19.1K
 02:54
Coordination Compounds and Nomenclature
26.9K
In most main group element compounds, the valence electrons of the isolated atoms combine to form chemical bonds that satisfy the octet rule. For instance, the four valence electrons of carbon overlap with electrons from four hydrogen atoms to form CH4. The one valence electron leaves sodium and adds to the seven valence electrons of chlorine to form the ionic formula unit NaCl (Figure 1a). Transition metals do not normally bond in this fashion. They primarily form coordinate covalent bonds, a...
26.9K
 02:33
Lattice Centering and Coordination Number
12.2K
The structure of a crystalline solid, whether a metal or not, is best described by considering its simplest repeating unit, which is referred to as its unit cell. The unit cell consists of lattice points that represent the locations of atoms or ions. The entire structure then consists of this unit cell repeating in three dimensions. The three different types of unit cells present in the cubic lattice are illustrated in Figure 1.
Types of Unit Cells
Imagine taking a large number of identical...
Types of Unit Cells
Imagine taking a large number of identical...
12.2K
 01:26
Kinematic Equations - I
16.3K
When an object moves with constant acceleration, the velocity of the object changes at a constant rate throughout the motion. The kinematic equations of motions are derived for such cases where the acceleration of the object is constant. The first kinematic equation gives an insight into the relationship between velocity, acceleration, and time. We can see, for example:
16.3K
 01:17
Kinematic Equations - II
14.8K
The second kinematic equation expresses the final position of an object in terms of its initial position, the distance traveled with the initial constant velocity, and the distance traveled due to a change in velocity. Similar to the first kinematic equation, this equation is also only valid when the acceleration is constant throughout the motion of an object.
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
14.8K