Video Experimental Relacionado
Updated: Feb 13, 2026

03:31

Author Spotlight: Enhancement of Salient Object Detection for Smart Grid Applications
Published on: December 15, 2023
1.1K
Red de fusión adaptativa de grano fino para la detección de objetos UAV multimodal

Resumen
Este estudio introduce una red de fusión adaptativa para la detección de objetos multimodal de vehículos aéreos no tripulados (UAV). El nuevo método mejora la precisión de detección mediante la fusión adaptativa de datos RGB e infrarrojos, superando a los enfoques existentes.
Área de la Ciencia:
- Visión por ordenador Visión por ordenador Visión por ordenador Visión por ordenador Visión por ordenador
- La inteligencia artificial es inteligencia artificial.
- Robótica y Robótica Robótica y Robótica Robótica Robótica Robótica Robótica Robótica Robótica
Sus antecedentes:
- La percepción multimodal es crucial para la detección de objetos de vehículos aéreos no tripulados (UAV).
- Las estrategias de fusión global en los métodos existentes luchan con variaciones de iluminación y oclusiones comunes en las imágenes de UAV.
- Estas limitaciones conducen a un rendimiento subóptimo en escenarios de detección de objetos densos y pequeños.
Objetivo del estudio:
- Desarrollar una red de fusión adaptativa y de grano fino para la detección de objetos UAV multimodal mejorada.
- Abordar las limitaciones de la fusión global considerando la consistencia de las características locales y la información específica de la modalidad.
Principales métodos:
- Propuso una red de fusión de grano fino adaptativa para la detección de objetos UAV multimodal.
- Se introdujo un módulo de fusión de modalidad basado en la consistencia de características locales para asignar de manera adaptativa pesos de fusión.
- Implementó una característica de información mutua guiada por pérdida contrastante para preservar la información específica de la modalidad durante la capacitación temprana.
Principales resultados:
- El método propuesto maneja efectivamente la oclusión de objetos en perspectivas de UAV.
- Logró un rendimiento de vanguardia en los puntos de referencia de detección de objetos UAV multimodales.
- Se ha demostrado una agregación de características superior a través de la fusión local adaptativa.
Conclusiones:
- La red de fusión adaptativa de grano fino ofrece un avance significativo en la detección de objetos UAV multimodal.
- La capacidad del método para manejar iluminación y oclusiones variables lo hace robusto para aplicaciones de UAV en el mundo real.
- El trabajo futuro puede implicar explorar estrategias de fusión más sofisticadas y mecanismos de atención.
Videos de Conceptos Relacionados
 02:45
Nuclear Fusion
33.9K
The process of converting very light nuclei into heavier nuclei is also accompanied by the conversion of mass into large amounts of energy, a process called fusion. The principal source of energy in the sun is a net fusion reaction in which four hydrogen nuclei fuse and ultimately produce one helium nucleus and two positrons.
A helium nucleus has a mass that is 0.7% less than that of four hydrogen nuclei; this lost mass is converted into energy during the fusion. This reaction produces about...
A helium nucleus has a mass that is 0.7% less than that of four hydrogen nuclei; this lost mass is converted into energy during the fusion. This reaction produces about...
33.9K
 01:15
Fineness of Cement
533
The fineness of cement directly influences the rate of hydration, as the hydration begins at the surface of the cement particles. In addition to hydration, the fineness of cement is vital for various properties of concrete including workability, gypsum requirement, and long-term behavior. The fineness of cement is represented in terms of the specific surface of cement which is typically measured in square meters per kilogram, with several methods available for this determination.
Direct...
Direct...
533
 01:19
Fineness Modulus
1.5K
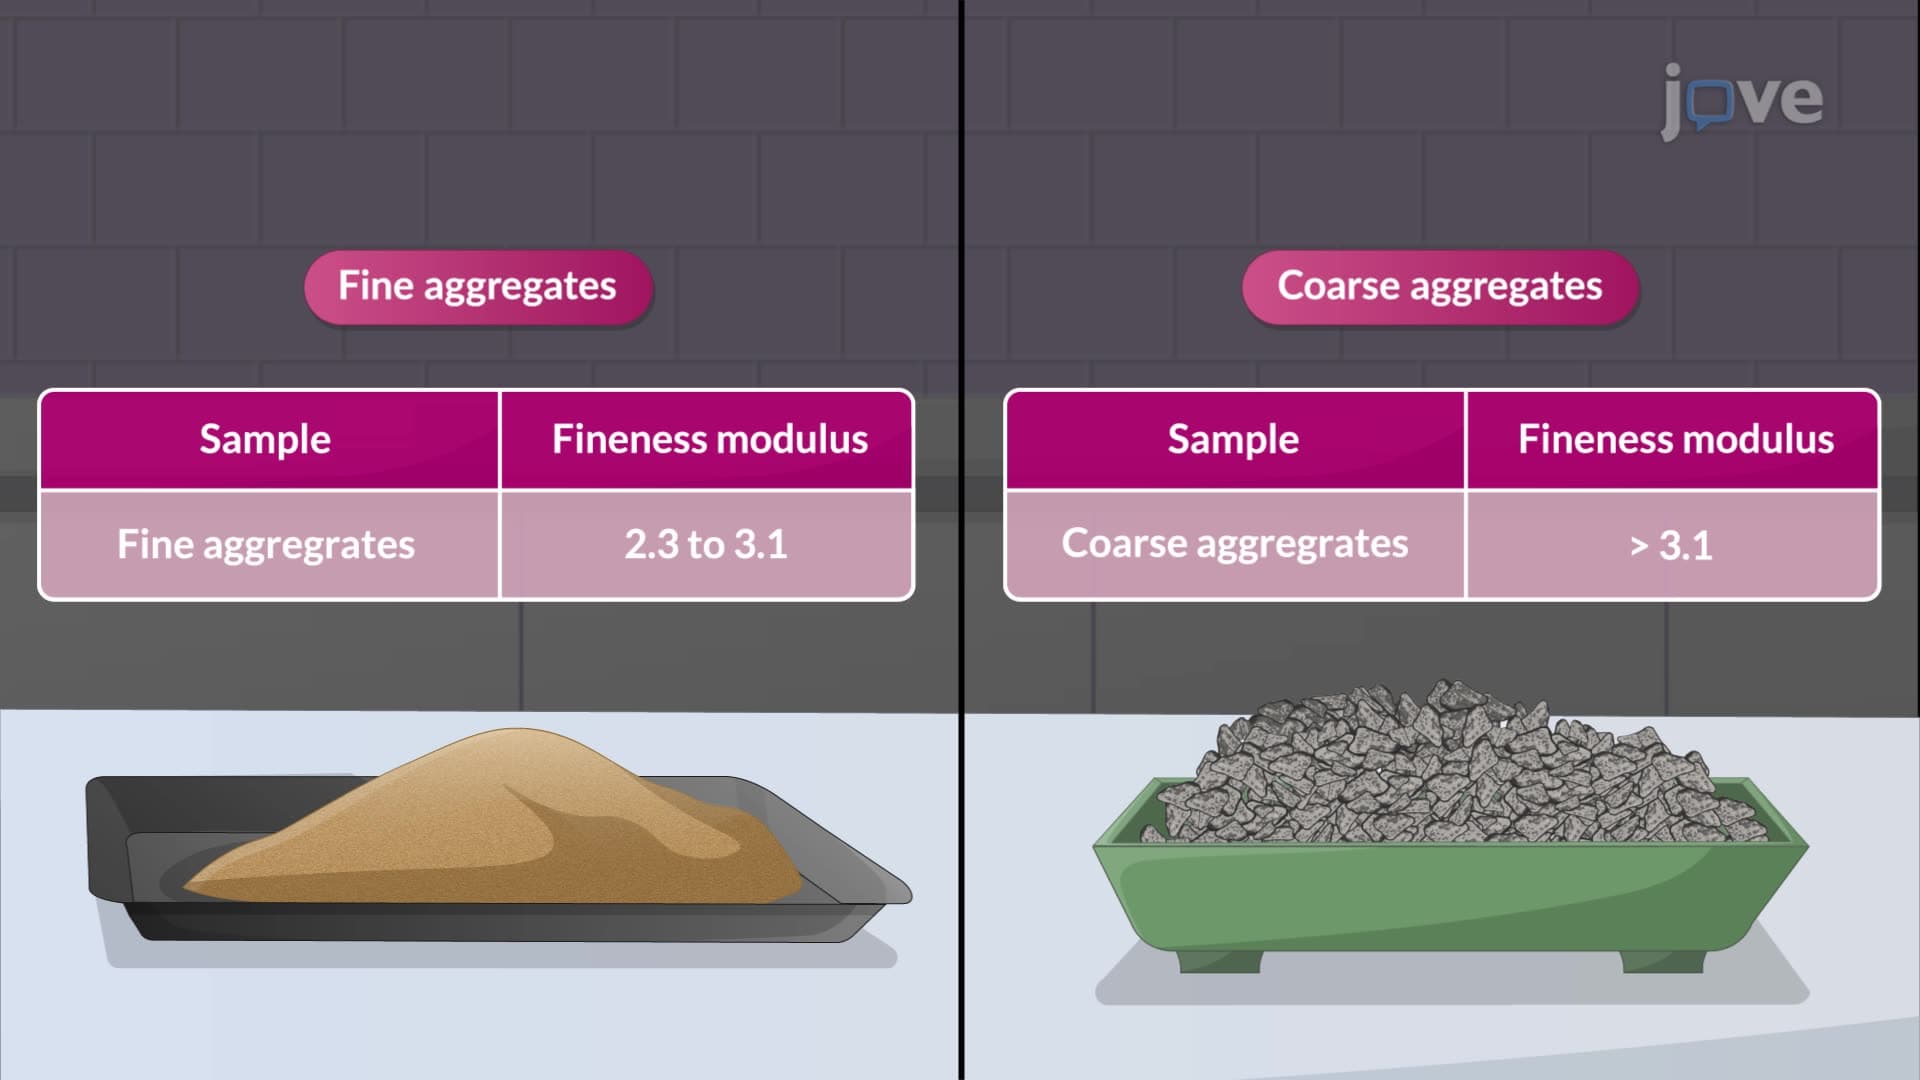
The fineness modulus (FM) of aggregate is a numerical index that measures the coarseness or fineness of the particles. It is calculated by adding the cumulative percentages of aggregate retained on each of a specified series of sieves and dividing the sum by 100.
Consider performing sieve analysis on sand through a set of ASTM sieves. The weight of aggregate retained in each sieve and pan placed at the bottom is recorded, as given in Column B of Table 1.
To determine the fineness modulus of...
Consider performing sieve analysis on sand through a set of ASTM sieves. The weight of aggregate retained in each sieve and pan placed at the bottom is recorded, as given in Column B of Table 1.
To determine the fineness modulus of...
1.5K
 02:26
Protein Networks
4.6K
An organism can have thousands of different proteins, and these proteins must cooperate to ensure the health of an organism. Proteins bind to other proteins and form complexes to carry out their functions. Many proteins interact with multiple other proteins creating a complex network of protein interactions.
These interactions can be represented through maps depicting protein-protein interaction networks, represented as nodes and edges. Nodes are circles that are representative of a protein,...
These interactions can be represented through maps depicting protein-protein interaction networks, represented as nodes and edges. Nodes are circles that are representative of a protein,...
4.6K
 02:18
Network Covalent Solids
16.2K
Network covalent solids contain a three-dimensional network of covalently bonded atoms as found in the crystal structures of nonmetals like diamond, graphite, silicon, and some covalent compounds, such as silicon dioxide (sand) and silicon carbide (carborundum, the abrasive on sandpaper). Many minerals have networks of covalent bonds.
To break or to melt a covalent network solid, covalent bonds must be broken. Because covalent bonds are relatively strong, covalent network solids are typically...
To break or to melt a covalent network solid, covalent bonds must be broken. Because covalent bonds are relatively strong, covalent network solids are typically...
16.2K
 01:18
Velocity of an Object
208
Understanding how an object moves along a path requires distinguishing between motion over a time span and motion at a precise moment. A useful example is a vehicle traveling along a straight and level path, where its position at any given time is known. The initial step in analyzing this motion is to measure how far the vehicle travels over a fixed time period. This measurement, called average velocity, is computed by dividing the total change in position by the duration over which the change...
208