
多機能受容体Robo3およびそのリガンドNELL2を通過するアクソン誘導におけるオペレーションリデンサ
Alexander Jaworski1, Irene Tom2, Raymond K Tong2
1Division of Research, Genentech, South San Francisco, CA 94080, USA. Laboratory of Brain Development and Repair, The Rockefeller University, New York, NY 10065, USA. Department of Neuroscience, Brown University, Providence, RI 02912, USA. alexander_jaworski@brown.edu marctl@rockefeller.edu.
Science (New York, N.Y.)
|November 21, 2015

まとめ
神経表皮成長因子類似2 (NELL2) は新しい軸索誘導シグナルである. ロボ3を通ってコンシューラルの軸索を駆逐し,真ん中線をターゲットにし,正確な経路を見つけるために複数の誘導信号を統合します.
科学分野:
- 神経科学
- 発達生物学
- 分子生物学
背景:
- アクソン・パスファインディングはガイド・シグナルに依存しているが,統合メカニズムは不明である.
- スリット/ロボシグナリングは排斥を媒介し,ネットリン/DCCシグナリングは引き寄せを媒介する.
- ロボ3は中枢軸が交差し 排斥と引き寄せのバランスをとるのに不可欠です
研究 の 目的:
- ロボ3のリガンドを特定し,アクソン誘導におけるその役割を明らかにする.
- ロボ3が 中央線ナビゲーションに 嫌悪感と魅力を 統合する方法を理解する
主な方法:
- ロボ3リガンドとしてNELL2の識別.
- マウスモデルでのアクソン誘導試験
- ロボ3とNELL2,Slits,Netrin-1との相互作用の分析
主要な成果:
- NELL2はRobo3を通って 中央線に誘導します
- ロボ3はNELL2の排斥を媒介し,スリットの排斥を抑制し,ネトリン吸引を強める.
- NELL2は新しい誘導シグナルとして機能し,Robo3は多機能のレギュレータとして機能します.
結論:
- NELL2は ロボ3を介して機能する 秘密の誘導信号です
- ロボ3は様々な誘導信号 (NELL2,Slit,Netrin) を統合して,精密な軸索経路を決定します.
- この研究は 神経の発達における 嫌悪感と魅力を調整する 新しいメカニズムを明らかにしています

関連する概念動画
 01:30
Three-Dimensional Force System:Problem Solving
A three-dimensional force system refers to a scenario in which three forces act simultaneously in three different directions. This type of problem is commonly encountered in physics and engineering, where it is necessary to calculate the resultant force on the system, which can then be used to predict or analyze the behavior of the object or structure under consideration.
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:17
Rolling Resistance: Problem Solving
Rolling resistance, also known as rolling friction, is the force that resists the motion of a rolling object, such as a wheel, tire, or ball, when it moves over a surface. It is caused by the deformation of the object and the surface in contact with each other, as well as other factors like internal friction, hysteresis, and energy losses within the materials. Rolling resistance opposes the object's motion, requiring additional energy to overcome it and maintain movement. In practical...
 01:24
One-Degree-of-Freedom System
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:15
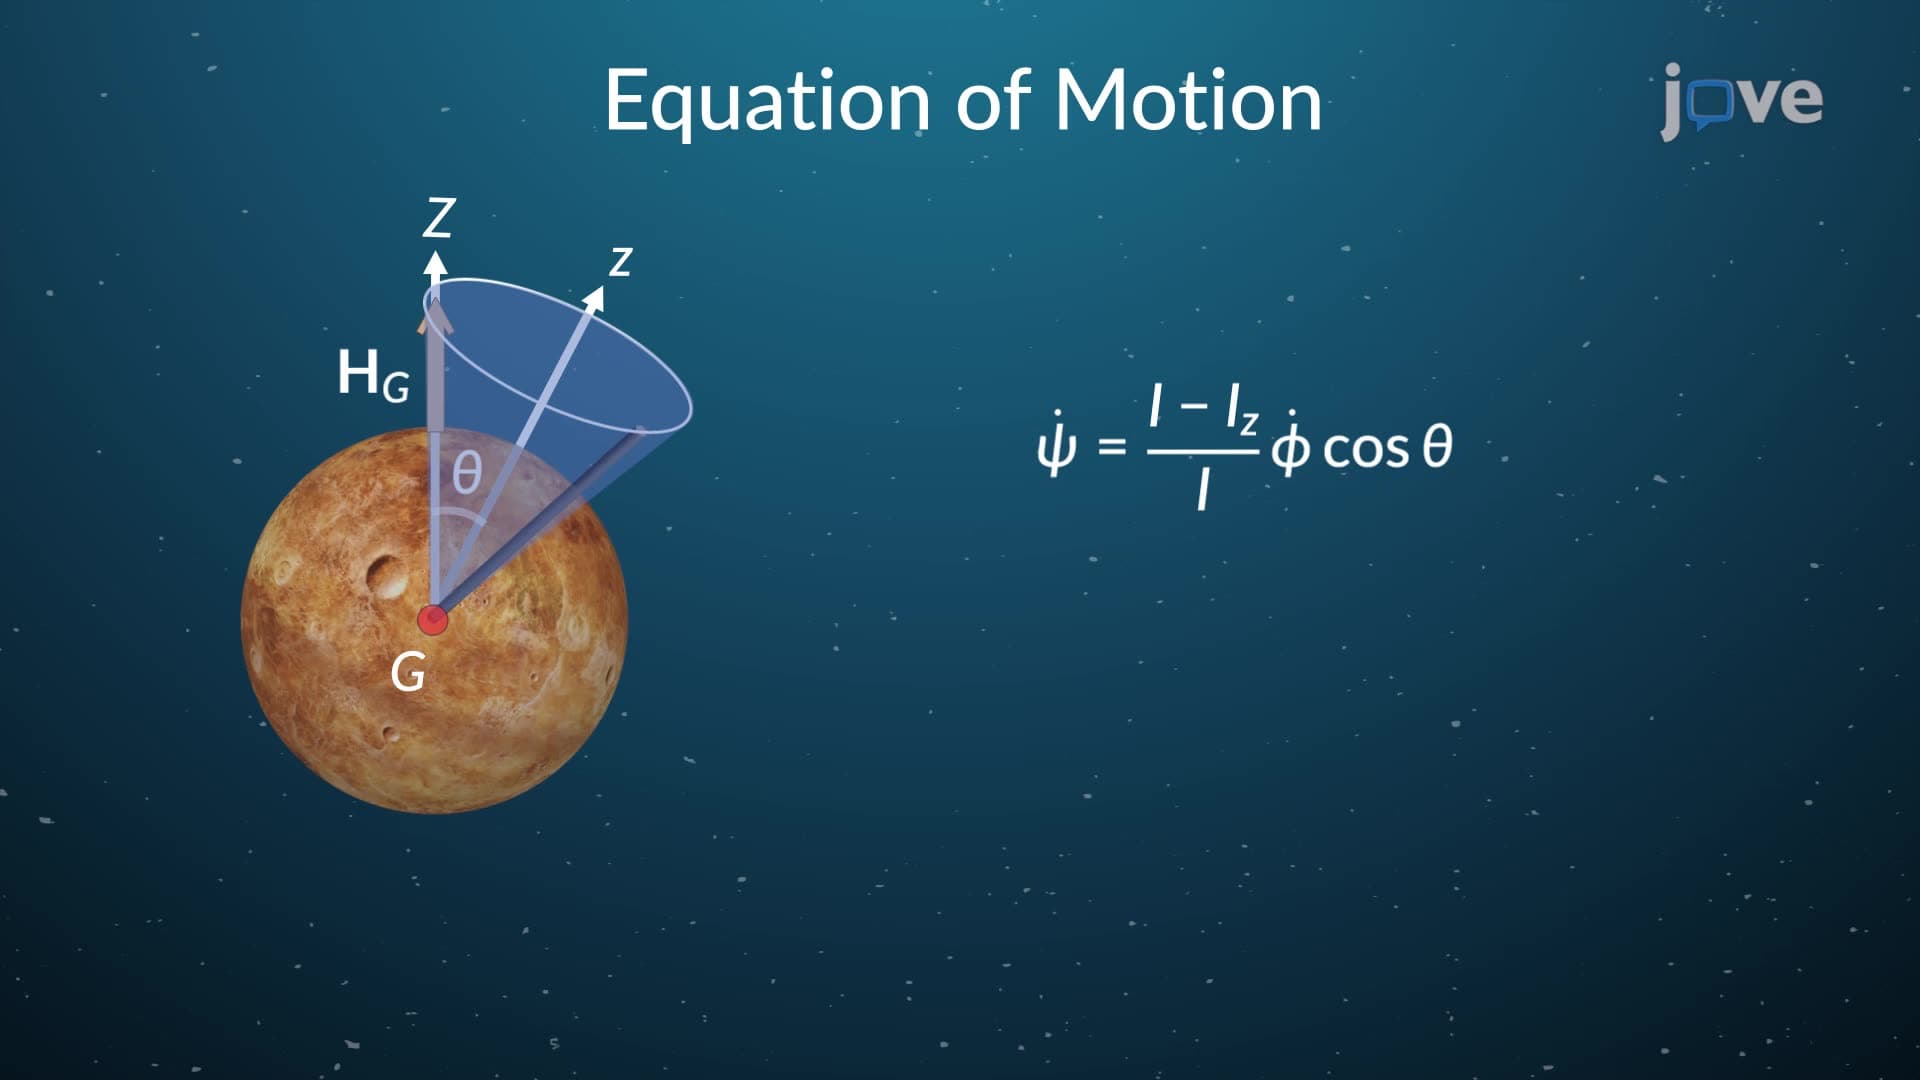
Torque Free Motion
The torque-free motion refers to the movement of a rigid body in space when no external torques are acting upon it. This type of motion can be observed in environments where there are no external forces or frictions, like in outer space. For example, a rotation of Mars in space is a torque-free motion. Mars is an axisymmetric object, meaning it has an axis of symmetry along which it rotates, designated as the z-axis. The rotating frame of reference is defined such that the center of mass of...