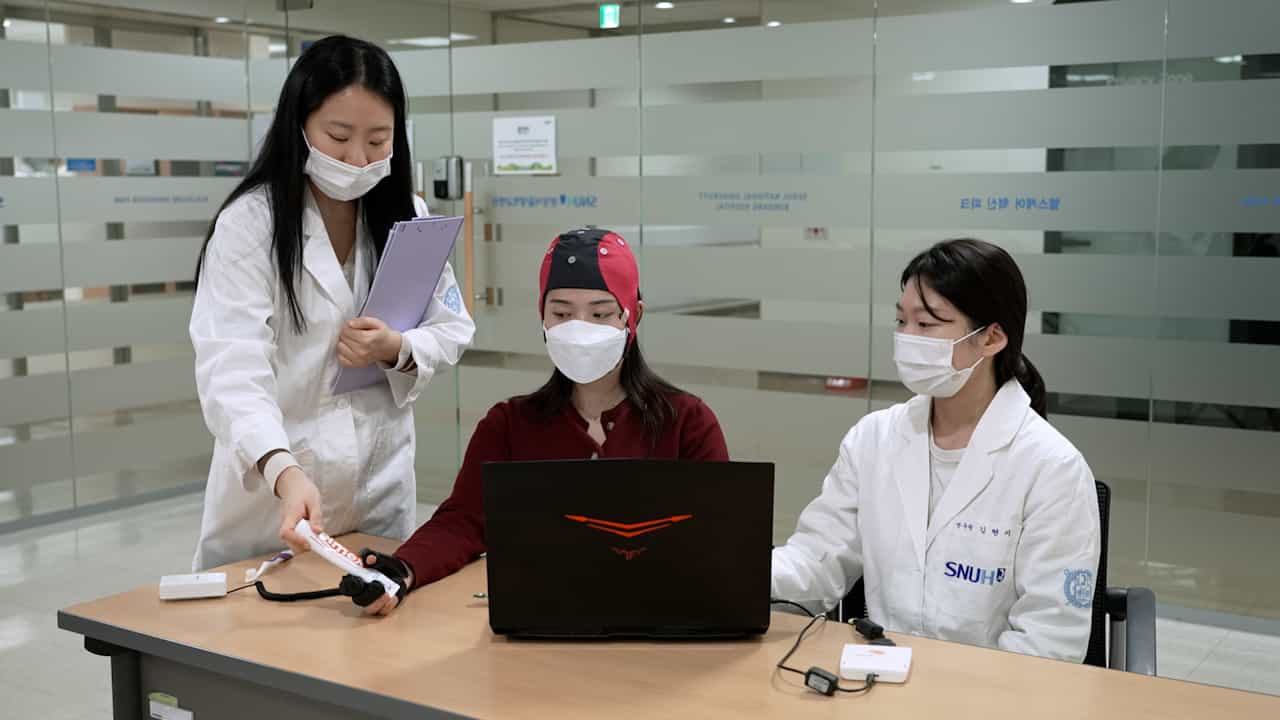

触覚 の 感覚 を 引き起こす 脳 と コンピューター の インターフェース は,ロボット の 腕 の 制御 を 改善 する
Sharlene N Flesher1,2,3, John E Downey1,2,3,4, Jeffrey M Weiss1,5
1Rehab Neural Engineering Labs, University of Pittsburgh, Pittsburgh, PA, USA.
Science (New York, N.Y.)
|May 21, 2021

まとめ
脳とコンピュータのインターフェースは 触覚フィードバックを加えることで 四肢麻痺患者の義肢のコントロールを 強化します 手足の機能を改善するために 自然の生物学的制御を模倣して 作業時間を短縮します
科学分野:
- 神経科学
- 生物医学工学
- リハビリテーションロボット
背景:
- 脳とコンピュータのインターフェース (BCI) を介して制御される義肢は,四肢麻痺の患者に機能的な運動の回復を提供します.
- 視覚的フィードバックだけでは物体を効果的に把握するには不十分であり,触覚感覚情報が必要であることを強調しています.
研究 の 目的:
- 視覚フィードバックを触覚知覚で補完することで,四肢麻痺の人のロボット肢体の性能に与える影響を調査する.
- 双方向的なBCIを介して触覚感覚を統合することで,機能的なタスクの完了時間を改善するかどうかを評価する.
主な方法:
- 運動皮質の活動を記録し,体感覚皮質の微刺激を通して触覚感覚を伝達する双方向BCIが使用されました.
- このシステムは,ロボットの足の操作中に人工的な触覚知覚で視覚的フィードバックを補完しました.
- 標準的な臨床上肢評価を用いて評価された.
主要な成果:
- ロボット腕の性能が 劇的に改善され 試験時間は 大幅に短縮されました
- 上肢評価の試験時間は20. 9秒から10. 2秒に減りました.
- 作業の迅速な完了は 主に物体をつかむ試みに費やされた時間の短縮に起因する.
結論:
- 双方向性BCIによる触覚フィードバックで視力を補完すると,四肢麻痺の患者のロボット肢体の制御が有意に向上します.
- 義肢の制御における 感覚フィードバックの生物学的原理を模倣することで 身体能力に近付くような 作業の性能が得られます
- このアプローチは,重度の運動障害を持つ人々の機能的独立性を回復させるための有望な進歩です.
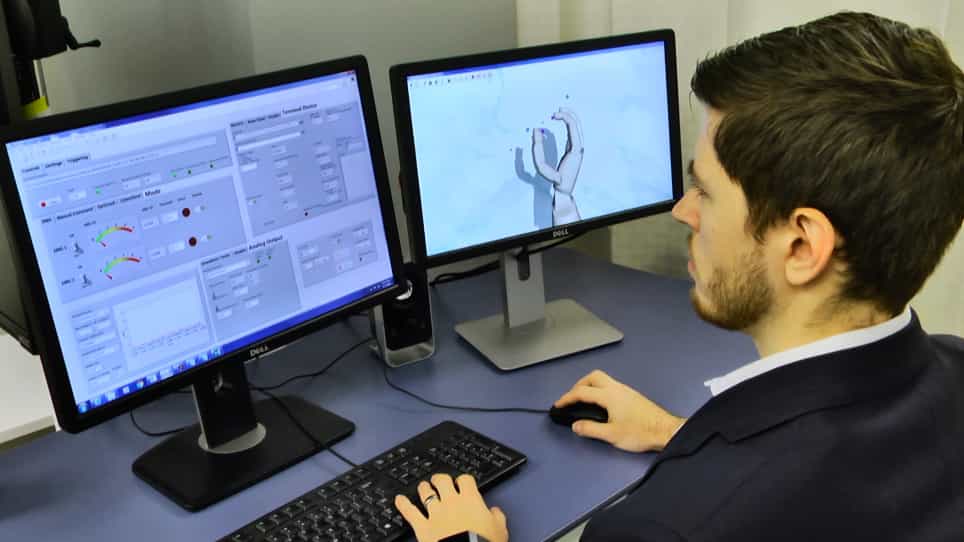

関連する概念動画
 01:33
Somatosensation
41.3K
The somatosensory system relays sensory information from the skin, mucous membranes, limbs, and joints. Somatosensation is more familiarly known as the sense of touch. A typical somatosensory pathway includes three types of long neurons: primary, secondary, and tertiary. Primary neurons have cell bodies located near the spinal cord in groups of neurons called dorsal root ganglia. The sensory neurons of ganglia innervate designated areas of skin called dermatomes.
41.3K
 01:27
Tactile and Chemical Senses
433
Tactile senses encompass touch, temperature, and pain, each mediated by specific receptors. Touch receptors detect mechanical energy or pressure against the skin. Sensory fibers from these receptors enter the spinal cord and relay information to the brain stem. Here, most fibers cross over to the opposite side of the brain. The touch information then moves to the thalamus, which projects a map of the body's surface onto the somatosensory areas of the parietal lobes in the cerebral cortex.
433