関連する実験動画
Updated: May 5, 2026
08:33

Visualize Drosophila Leg Motor Neuron Axons Through the Adult Cuticle
Published on: October 30, 2018
9.5K
ドロソフィラの足と翼前運動制御ネットワークのシナプス構造
Ellen Lesser1, Anthony W Azevedo1, Jasper S Phelps2,3
1Department of Physiology and Biophysics, University of Washington, Seattle, WA, USA.
Nature
|June 26, 2024

まとめ
研究者達は フルーツフライの足と翼を制御する 前運動回路をマッピングしました 足の運動ニューロンの採用は階層的で 翼の運動制御はより柔軟で 動物の運動制御の共通の原理と専門性を明らかにしています
科学分野:
- 神経科学
- 動物 の 行動
- コンピュータ生物学
背景:
- モーターニューロンは 筋肉を活性化することで 動物の動きを制御します
- 複雑な前運動ネットワークは様々な行動の MN 活動を調整します
- モーター前回路の配線を理解することは,モーター制御の解読に不可欠です.
研究 の 目的:
- ドロソフィラの足と翼の制御における 前運動回路の配線論理を分析する.
- モーター制御システムの共通の組織原則と専門性を特定する.
- 脚と翼のモーター制御アーキテクチャを同じ生物の中で比較する.
主な方法:
- コネクトミクスを利用して 神経回路をマッピングした
- 前運動ネットワークのシナプス接続と重量分析
- 脚と翼のモーターシステム間の回路アーキテクチャを比較した.
主要な成果:
- 脚と翼の両方の前運動ネットワークは,機能的に関連したMNをリンクするモジュールを形成します.
- 足のモーターモジュールは比例したシナプス重量を示し,階層的なMNの採用を可能にします.
- 翼前運動ネットワークには比例した接続性が欠けていて 柔軟な筋肉を操縦に使うことを示唆している.
結論:
- 異なる運動系における前運動ネットワーク組織における共通の原則を特定した.
- 脚と翼の運動制御の専門分野を強調し,生体力学と進化的要因を反映した.
- 足の制御における階層的なMN採用と,翼の制御における柔軟な採用のための回路基盤を確立した.
関連する概念動画
 01:20
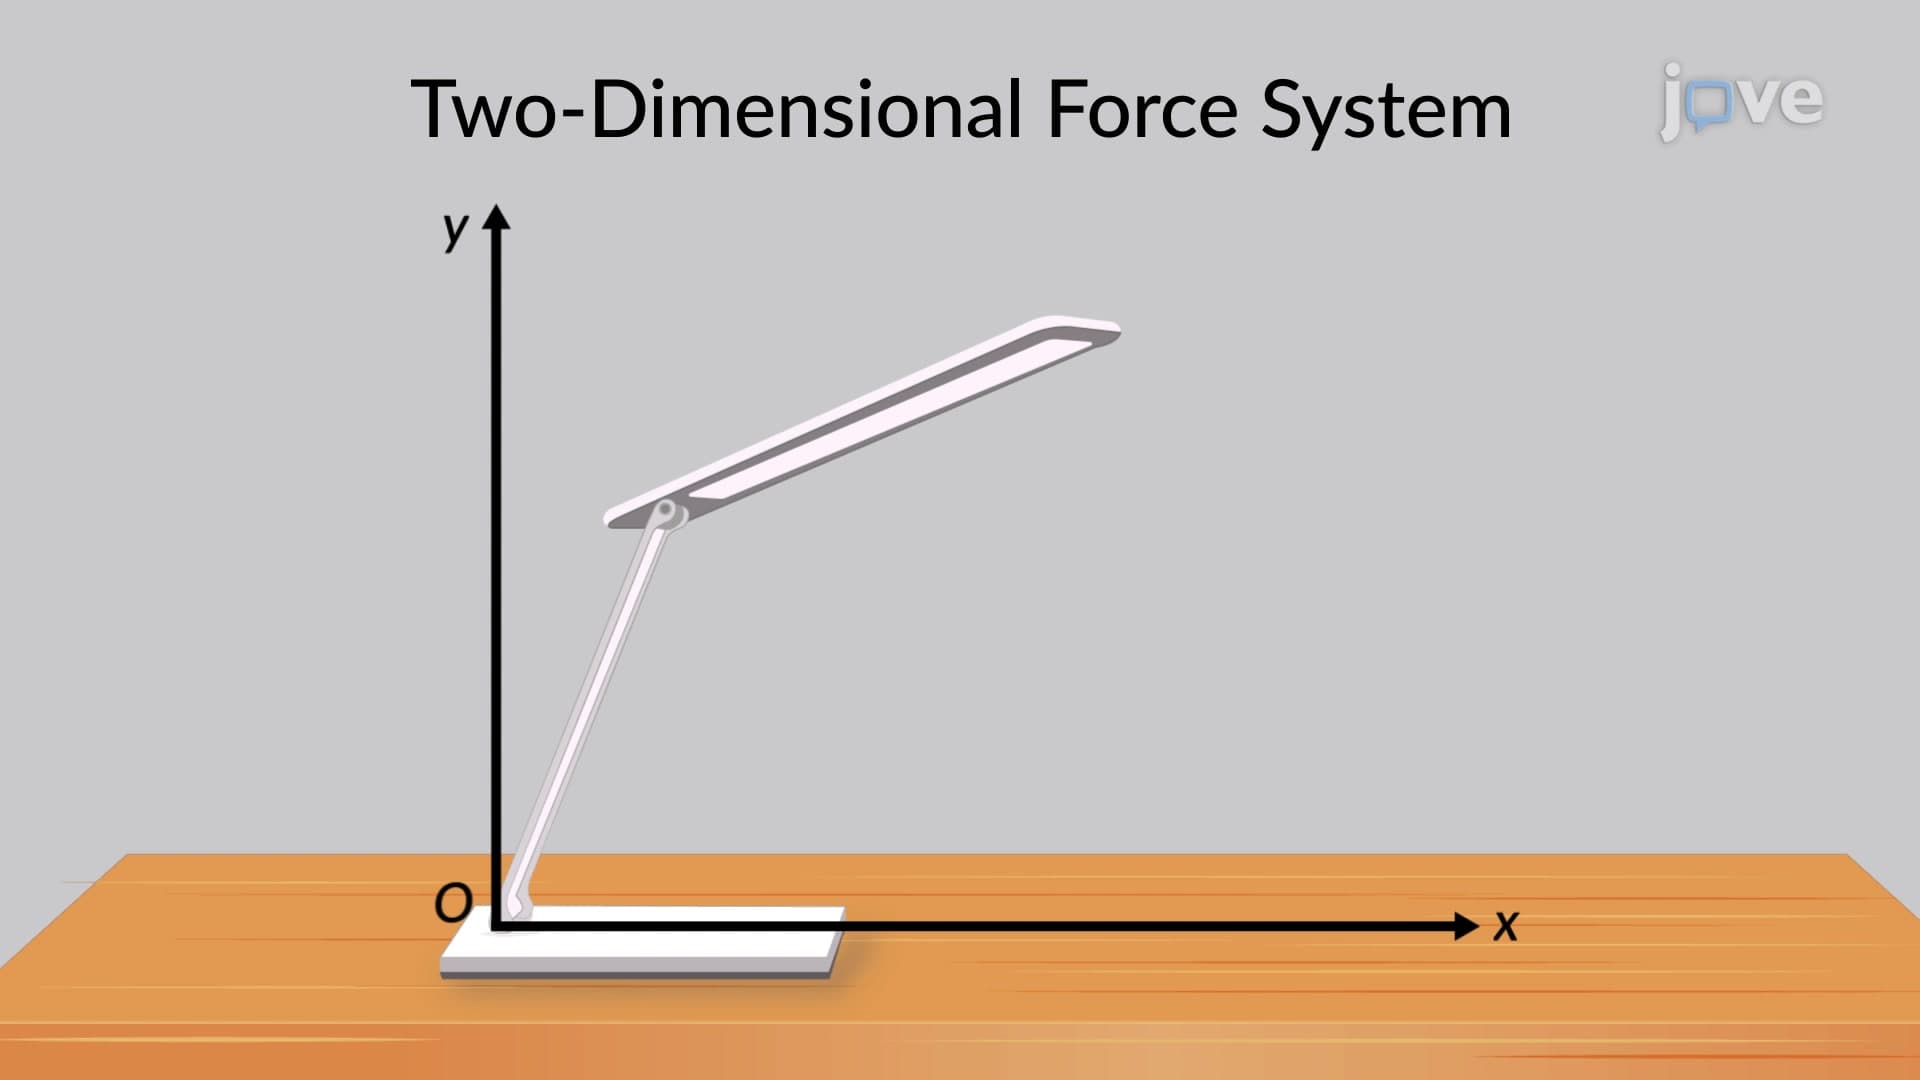
Two-Dimensional Force System
1.9K
A two-dimensional system in mechanical engineering involves the analysis of motion and forces in a plane. A two-dimensional force vector can be resolved into its components as:
1.9K
 01:30
Three-Dimensional Force System
3.2K
In mechanical engineering, a three-dimensional force system is a system of forces acting in three dimensions, with forces applied along the x, y, and z coordinate axes. The three-dimensional force system is an important concept in mechanical engineering, as it allows engineers to understand and analyze the behavior of objects and structures in three dimensions. By understanding the forces acting on a system, engineers can design more efficient and effective mechanical systems that can withstand...
3.2K
 01:24
One-Degree-of-Freedom System
1.0K
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
1.0K
 01:24
Muscle Coordination and Action
3.8K
Muscle coordination is a complex and finely tuned process essential for smooth and purposeful movements like flexion, extension, adduction, abduction, and rotation. The human body orchestrates the actions of various muscles working in concert, each with a specific role. Four functional types describe how muscles work together: agonist, antagonist, synergist, and fixator.
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement....
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement....
3.8K
 01:18
Hierarchy of Motor Control
5.6K
The hierarchy of motor control refers to the different levels of organization and processing involved in controlling movement in the body. These levels range from higher cortical areas involved in planning and decision-making to lower spinal cord reflexes that respond automatically to external stimuli.
5.6K
 01:26
PD Controller: Design
761
In automotive engineering, car suspension systems often employ Proportional Derivative (PD) controllers to enhance performance. PD controllers are utilized to adjust the damping force in response to road conditions. A controller, acting as an amplifier with a constant gain, demonstrates proportional control, with output directly mirroring input.
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
761