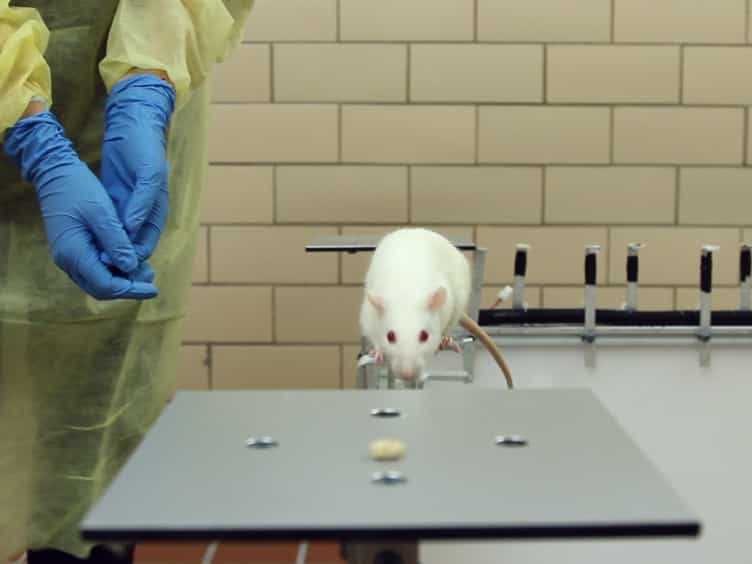
作業犬の運動の生体力学 I: 安定状態のトロッティング
James P Charles1, Eithne J Comerford1,2, Victoria F Ratcliffe3
1Department of Musculoskeletal & Ageing Science, Institute of Life Course and Medical Sciences, University of Liverpool, Liverpool, UK.
The Journal of experimental biology
|August 22, 2025

まとめ
作業犬の種は 安定状態のトロッティング中に 独特の生体力学を示します 運動の違いを理解することは 作業の際に犬の健康と福祉を最適化するために不可欠です
科学分野:
- 犬のバイオメカニクス
- 比較運動分析
- 動物の形態学
背景:
- 作業犬の安定状態運動の生体力学は十分に研究されていない.
- 種間の動力学および動力学パラメータの変動と形状学との関係は不明です.
研究 の 目的:
- ラブラドール・リトリーバー,シェパード犬,スパニール犬の総体形状と走行を比較する.
- 動的・運動的パラメータの種間変化とその形態学的関係について調査する.
主な方法:
- 総体形状とトロッティング運動の比較分析
- モーションキャプチャ,フォースプレート, バイオメカニカルモデリング.
- ラブラドール・レトリバー,シェパード,スパニエルの 27種類の犬を比較しました.
主要な成果:
- 肢体と体の長さの微妙な陽性アロメトリックスケーリングを発見し,シェパード犬はスパニール犬よりも長い長さを持っています.
- 大きな羊飼い犬は,より小さな種よりも大きな速度,ステップの長さ,地面反応力を発揮しました.
- 歩行サイクルの時間と歩行距離は,身体のサイズに等比的にスケールされず,ダイナミックな不一致を示しています.
結論:
- 作業犬の種間の安定状態のトロッティング運動の生体力学には大きな違いがあります.
- 犬の研究と福祉のために,犬種特有の動きに関するデータベースと考察は不可欠です.
- 品種特有の生体力学に 慣行を合わせることで 働く犬の健康と福祉を最大限に高めることができます
さらに関連する動画
関連する概念動画
 01:17
Kinematic Equations - II
10.6K
The second kinematic equation expresses the final position of an object in terms of its initial position, the distance traveled with the initial constant velocity, and the distance traveled due to a change in velocity. Similar to the first kinematic equation, this equation is also only valid when the acceleration is constant throughout the motion of an object.
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
10.6K
 01:16
Bones of the Lower Limb: Femur and Patella
2.9K
The femur is the body's longest and strongest bone spanning the thigh region. Its head articulates with the acetabulum of the hip bone to form the hip joint. A minor indentation on the medial side of the femoral head, called the fovea capitis, serves as the site of attachment for the ligament of the head of the femur. This weak ligament spans the femur and acetabulum and supports the hip joint. The narrowed region below the head is the neck of the femur. The inclination angle between the...
2.9K
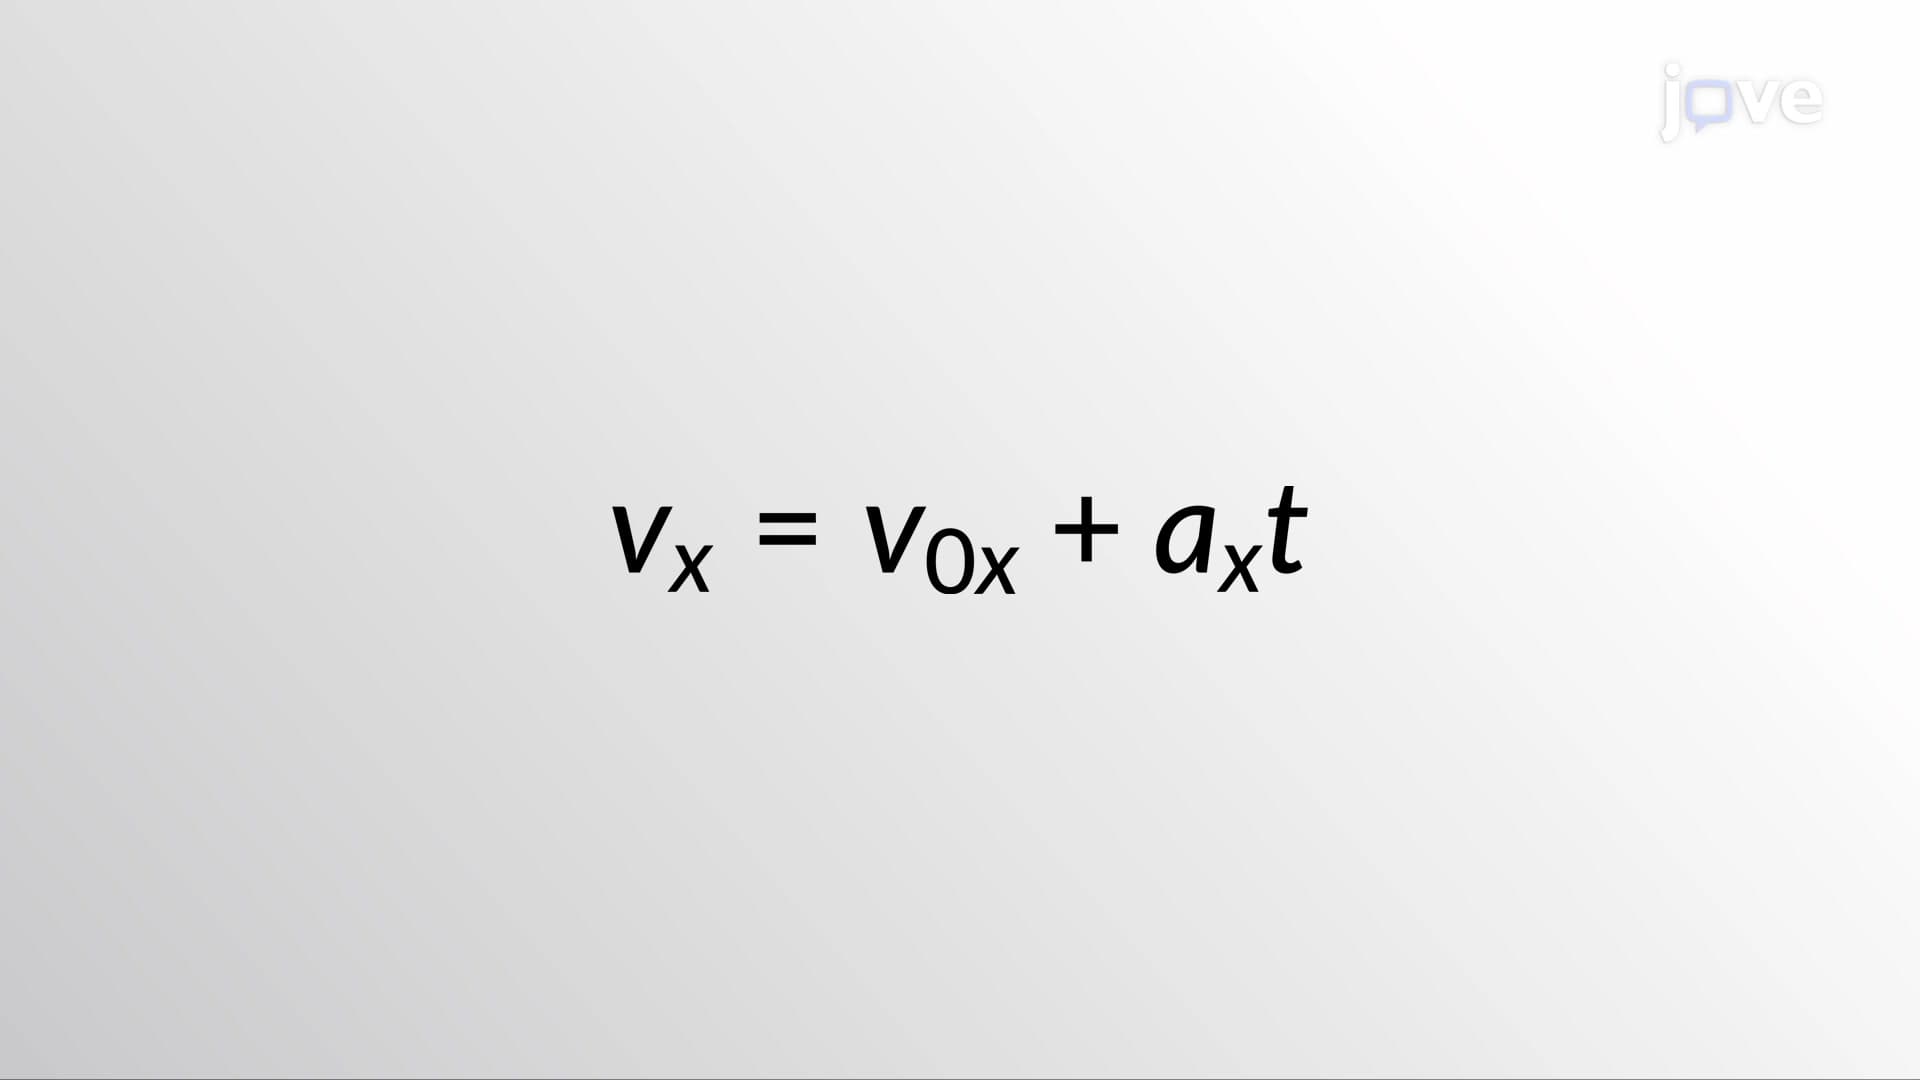 01:26
Kinematic Equations - I
11.9K
When an object moves with constant acceleration, the velocity of the object changes at a constant rate throughout the motion. The kinematic equations of motions are derived for such cases where the acceleration of the object is constant. The first kinematic equation gives an insight into the relationship between velocity, acceleration, and time. We can see, for example:
11.9K
 01:18
Kinematic Equations - III
8.4K
The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...
Using the kinematic equations,...
8.4K