

非線形システムにおける未知の入力遅延のための推定器ベースの二次スライディングモード制御設計
IEEE transactions on cybernetics
|August 26, 2025

まとめ
この研究は,未知の入力遅延と不確実性を持つ非線形システムのための新しい二次スライディングモード (SOSM) コントローラーを導入します. 新しいコントローラは,シミュレーションで既存の方法を上回って,安定性と性能を向上させます.
科学分野:
- 制御システム工学
- 非線形システムダイナミクス
- ロボット工学と自動化
背景:
- スライディングモードコントローラ (SMC) は非線形システムでは有効ですが,入力遅延と不確実性で苦労します.
- 既存の二次スライディングモード (SOSM) コントローラーは,未知の入力遅延と機能限定の不確実性を処理する上で課題に直面しています.
- SMCの断続的な性質は,遅延補償メカニズムを統合することを困難にする.
研究 の 目的:
- 未知の入力遅延を持つ不確実な非線形システムのための推定器ベースの二次スライディングモード (SOSM) コントローラを開発する.
- 未知の入力遅延と機能限定の不確実性に対処する既存のSOSM方法の限界に対処する.
- クローズド・ループ制御システムの定時安定性を確保する.
主な方法:
- 入力遅延と不確実性を含む確立されたSOSMダイナミクス.
- 補助補償システムとコンベックス最適化ベースの入力遅延推定器を導入しました.
- パワー・インテグレーター技術を用いた新しい推定器ベースのSOSMコントローラを設計し,ライアプノフ分析で安定性を検証した.
主要な成果:
- 断続的なコントローラと互換性のある入力遅延推定器を成功裏に設計しました.
- 未知の入力遅延を効果的に補償する新しいSOSMコントローラを開発しました.
- 厳格なリヤプノフ分析によって 閉ループシステムの定時安定性を証明した.
- 比較シミュレーションにより,提案されたSOSMコントローラの優れた性能が確認されました.
結論:
- 提案された推定器ベースのSOSMコントローラーは,未知の入力遅延を持つ不確実な非線形システムを効果的に処理します.
- この新しいアプローチは,堅固な制御を提供し,限られた時間の安定性を保証します.
- この方法は,複雑なシステムの既存のSOSM制御戦略に比べて,かなり進歩しています.
さらに関連する動画
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
8.7K
 08:18
WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
5.0K
関連する概念動画
 01:18
Second Order systems II
171
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
171
 01:20
Second Order systems I
233
A servo system exemplifies a second-order system, featuring a proportional controller and load elements that ensure the output position aligns with the input position. The relationship between these components is described by a second-order differential equation. Applying the Laplace transform under zero initial conditions yields the transfer function, showing how inputs are converted to outputs in the system.
By reinterpreting the system, one can derive the closed-loop transfer function, which...
By reinterpreting the system, one can derive the closed-loop transfer function, which...
233
 01:21
Linear Approximation in Time Domain
124
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
124
 01:21
First Order Systems
162
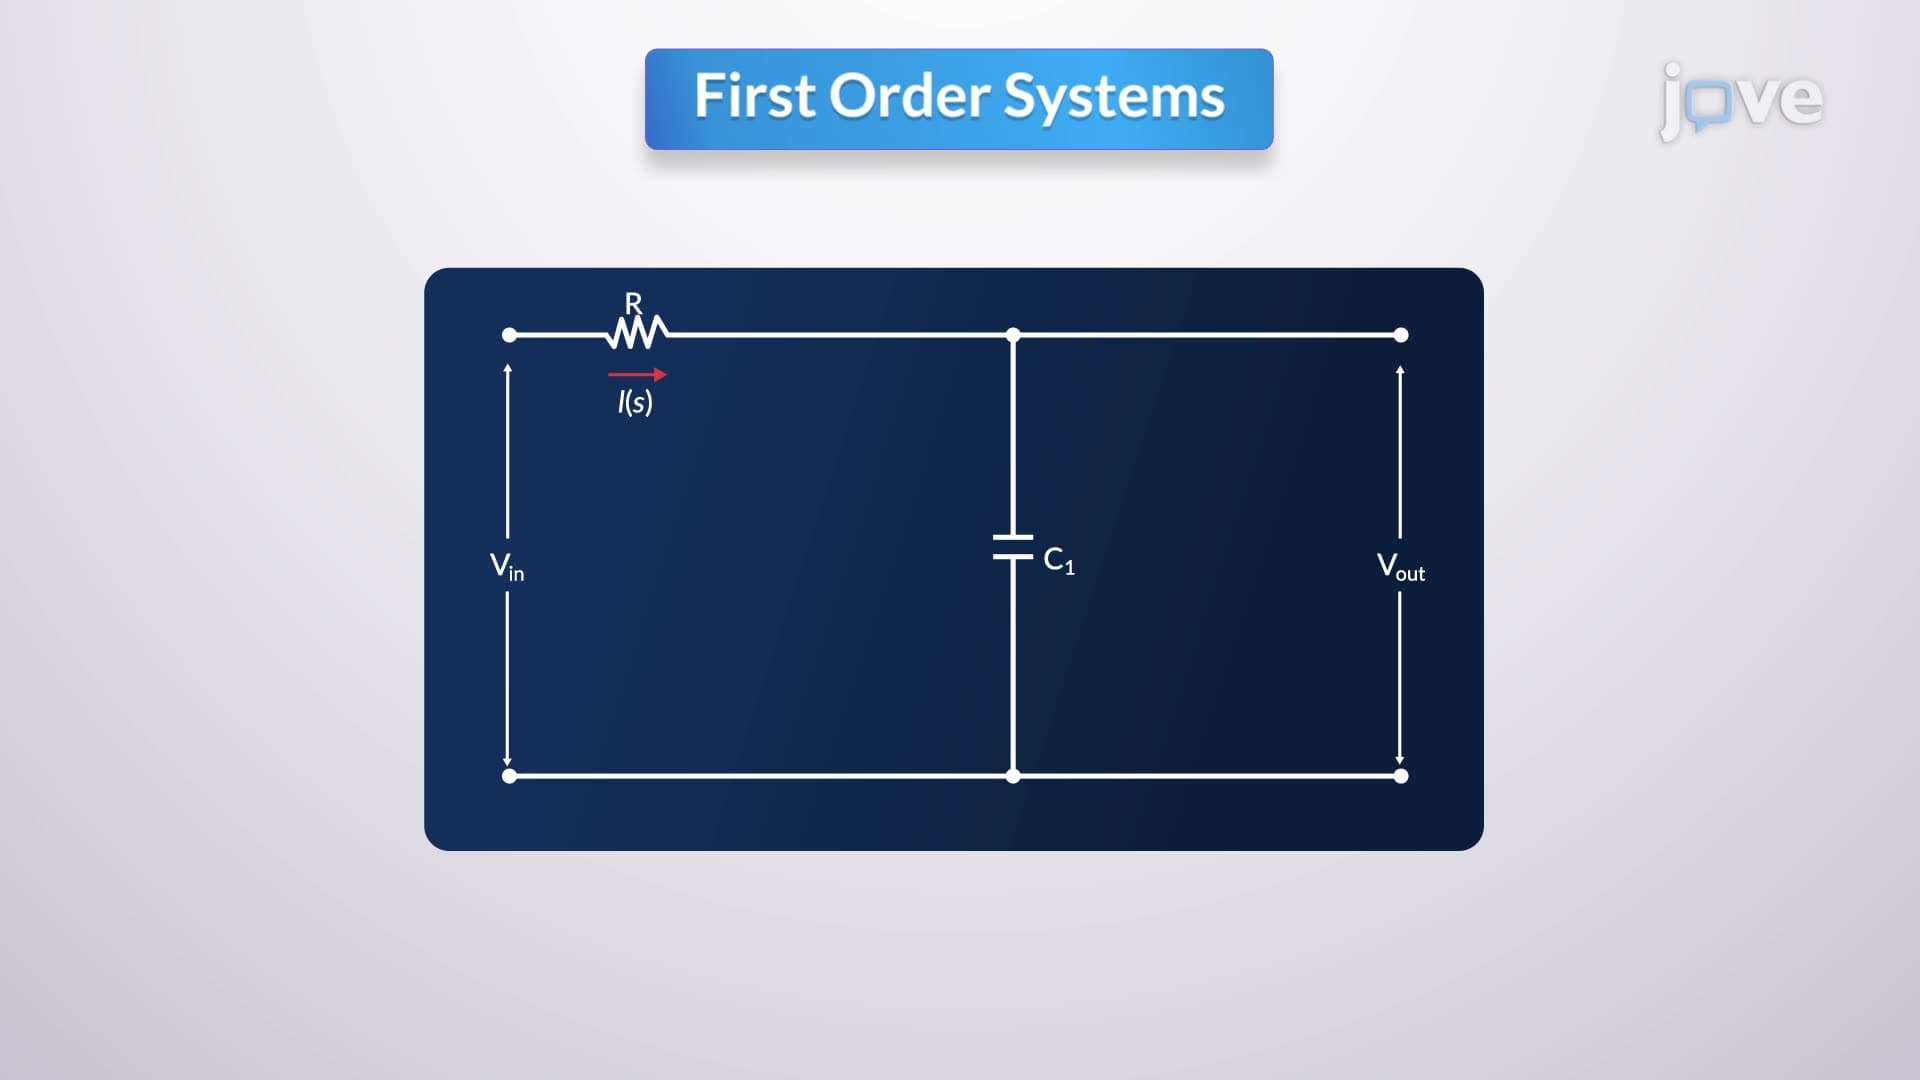
First-order systems, such as RC circuits, are foundational in understanding dynamic systems due to their straightforward input-output relationship. Analyzing their responses to different input functions under zero initial conditions reveals significant insights into system behavior.
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
162
 01:26
PD Controller: Design
349
In automotive engineering, car suspension systems often employ Proportional Derivative (PD) controllers to enhance performance. PD controllers are utilized to adjust the damping force in response to road conditions. A controller, acting as an amplifier with a constant gain, demonstrates proportional control, with output directly mirroring input.
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
349
 01:26
Feedback control systems
419
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
419