関連する実験動画
Updated: Sep 10, 2025
16:14

Trajectory Data Analyses for Pedestrian Space-time Activity Study
Published on: February 25, 2013
13.7K
クロスフォーマーGAN:高度な注意力メカニズムとトランスフォーマーアーキテクチャによる自動運転における歩行者軌道の予測の強化
V Nisha1, G Linda Rose2, Jeffin Gracewell3
1Department of Computer Applications, Faculty of Science and Humanities, SRM Institute of Science and Technology, Kattankulathur, Chennai, Tamil Nadu India.
Cognitive neurodynamics
|August 27, 2025

まとめ
この研究では,自律運転における歩行者の軌道を正確に予測するための新しいモデルであるCrossFormerGANを紹介しています. 先進的な注意メカニズムとトランスフォーマーを使って 歩行者の動きを予測することで 安全性を高めます
科学分野:
- コンピュータ・ビジョン
- 人工知能
- ロボット
背景:
- 歩行者の走行軌道の予測は 自動運転の安全性にとって極めて重要です
- 伝統的な方法は 複雑な人間の行動や環境要因と 闘っています
- 誤った予測は,危険な運転の決定につながります.
研究 の 目的:
- 自動運転車の歩行者軌道の予測を リアルタイムで強化する
- 歩行者の動きを予測する精度と信頼性を向上させる.
- ダイナミックな運転のシナリオでの事故のリスクを減らすために
主な方法:
- 提案されたCrossFormerGenerative Adversarial Network (クロスフォーマーGAN) について
- ジェスチャー・スペース・インタラクティブ・アテンション (スロットと地域注意を組み合わせた) を導入した.
- バイアスモジュール付きの 適応型近隣型CrossFormerトランスフォーマーを組み込みました
- グループ化されたクエリをディスクリミネーターで利用しました.
主要な成果:
- UCYデータセット (ZARA 2シナリオ) の平均移位誤差 (ADE) 0.10で最先端の性能を達成しました.
- ETHデータセットの最終位移誤差 (FDE) が0.18で優れた精度を示した (HOTELシナリオ).
- 歩行者の走行軌跡を予測する 既存の方法を上回った
結論:
- CrossFormerGANは歩行者の軌道の予測の正確性と信頼性を大幅に改善します.
- このモデルは自動運転車の 安全性と信頼性を高めています
- 提案された注意とトランスフォーマーメカニズムは 複雑な歩行者行動と環境の相互作用を 効果的に捉えます
関連する概念動画
 01:10
Relative Motion Analysis - Acceleration
424
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
424
 01:24
Absolute Motion Analysis- General Plane Motion
271
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
271
 02:07
Improving Translational Accuracy
11.9K
Base complementarity between the three base pairs of mRNA codon and the tRNA anticodon is not a failsafe mechanism. Inaccuracies can range from a single mismatch to no correct base pairing at all. The free energy difference between the correct and nearly correct base pairs can be as small as 3 kcal/ mol. With complementarity being the only proofreading step, the estimated error frequency would be one wrong amino acid in every 100 amino acids incorporated. However, error frequencies observed in...
11.9K
 01:17
Rolling Resistance: Problem Solving
449
Rolling resistance, also known as rolling friction, is the force that resists the motion of a rolling object, such as a wheel, tire, or ball, when it moves over a surface. It is caused by the deformation of the object and the surface in contact with each other, as well as other factors like internal friction, hysteresis, and energy losses within the materials. Rolling resistance opposes the object's motion, requiring additional energy to overcome it and maintain movement. In practical...
449
 01:30
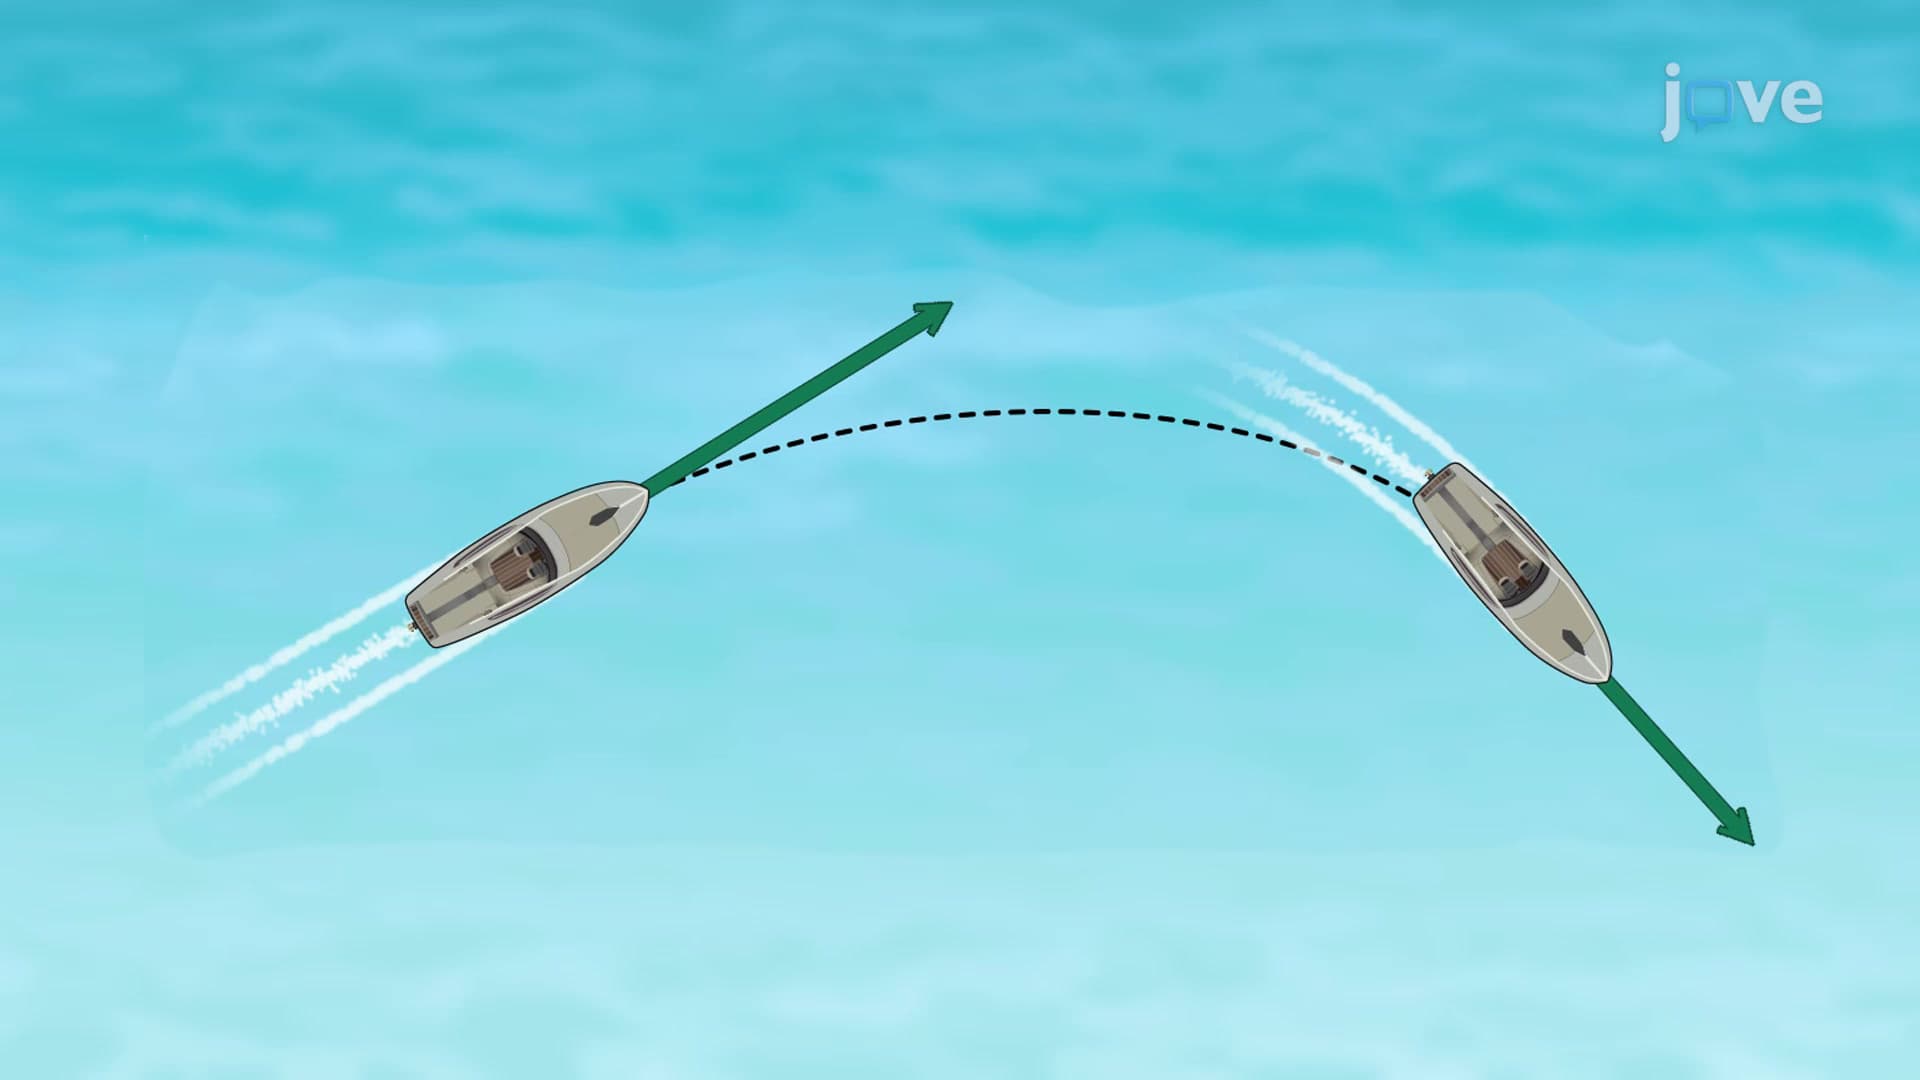
Acceleration Vectors
8.9K
In everyday conversation, accelerating means speeding up. Acceleration is a vector in the same direction as the change in velocity, Δv, therefore the greater the acceleration, the greater the change in velocity over a given time. Since velocity is a vector, it can change in magnitude, direction, or both. Thus acceleration is a change in speed or direction, or both. For example, if a runner traveling at 10 km/h due east slows to a stop, reverses direction, and continues their run at 10 km/h...
8.9K
 01:15
Elastic Collisions: Case Study
14.3K
Elastic collision of a system demands conservation of both momentum and kinetic energy. To solve problems involving one-dimensional elastic collisions between two objects, the equations for conservation of momentum and conservation of internal kinetic energy can be used. For the two objects, the sum of momentum before the collision equals the total momentum after the collision. An elastic collision conserves internal kinetic energy, and so the sum of kinetic energies before the collision equals...
14.3K