
柔らかい空気式グリッパーをロボットシステムに組み込み,生を高速で安定的に処理する
1Graduate School of Science and Engineering, Ritsumeikan University, Kusatsu 525-8577, Japan.
Foods (Basel, Switzerland)
|August 28, 2025

まとめ
生の処理を自動化するには,握り力と安定性のバランスをとる必要があります. この研究では,柔らかい空気式グリッパーを搭載したロボットシステムを開発し,脆弱な水産物を損傷することなく100%の処理成功のために最適なアクチュエーション圧力を発見しました.
科学分野:
- ロボット
- 食品加工の自動化
- ソフトグリッパー技術
背景:
- 生のような水産物の手作業は 食品加工にも続いている
- 既存のソフトロボットグリッパーとロボットシステムは 自動化のための機会を提示しますが,脆弱なアイテムで課題に直面します.
研究 の 目的:
- 柔らかい空気式グリッパーを搭載した ロボットシステムを使って 生の処理を自動化します
- 生の脆弱性に対処し ロボットによる高速処理による損傷を最小限に抑えるため
- 握りしめ安定性と製品の整合性の両方にとって最適な握りしめ操作圧力を特定する.
主な方法:
- 限られた要素分析 (FEA) は,異なるアクチュエーション圧力下でのグリッパー動作をモデル化します.
- 生を扱うロボットシステムの実験評価
- 握り手の指の歪み,握り力の分析,および取扱いの成功率.
主要な成果:
- FEAは,アクチュエーション圧力,安定性,および握り力との間のトレードオフを明らかにしました.
- 最適なアクチュエーション・プレッシャーは,グリッシングの安定性をバランスさせ,ダメージを最小限に抑えるために特定されました.
- ロボットシステムは 100%の処理率で 生を最適の圧力で処理し,大きなダメージを与えませんでした.
結論:
- 柔らかい空気式グリッパーを搭載したロボットシステムは,脆弱な水産物の高速で安定した処理に有効です.
- 握り手の操作圧力を最適化することは,機動操作中の繊細な製品を保護するために不可欠です.
- この研究は,水産物の処理を自動化するための貴重な参考資料を提供します.

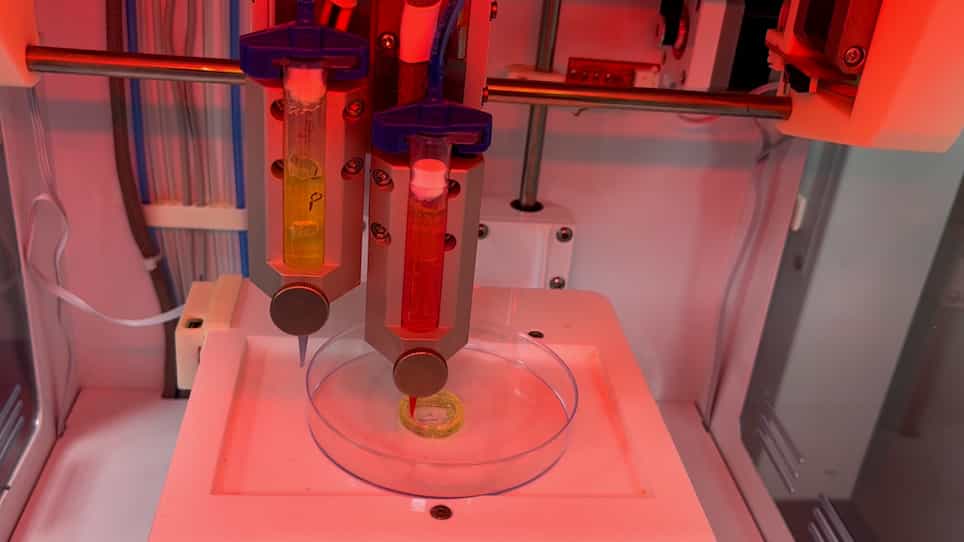
関連する概念動画
 01:25
Suctioning the Oropharyngeal Airway
375
In preparing for oropharyngeal airway suctioning, a nurse must gather all necessary equipment, including a suction unit with tubing, a prepackaged suction kit, sterile gloves, water or saline for irrigation, a water-soluble lubricant, and additional personal protective equipment (such as a gown, mask, and goggles) to control infections.
After assembling the equipment, the nurse should practice hand hygiene and don appropriate PPE according to infection control guidelines to avoid the...
After assembling the equipment, the nurse should practice hand hygiene and don appropriate PPE according to infection control guidelines to avoid the...
375
 01:22
Mechanical Systems
285
Mechanical systems are analogous to to electrical networks where springs and masses play similar roles to inductors and capacitors, respectively. A viscous damper in mechanical systems functions similarly to a resistor in electrical networks, dissipating energy. The forces acting on a mass in such systems include an applied force in the direction of motion, counteracted by forces from the spring, a viscous damper, and the mass's acceleration. This interplay of forces is mathematically...
285