調整可能な解像度を持つ新しい変形剛性トルクセンサ
Zhongyuan Mao1, Yuanchang Zhong1, Xuehui Zhao1
1School of Electrical Engineering, Chongqing University, Chongqing 400044, China.
Micromachines
|August 28, 2025

まとめ
この研究は,回転する機械における解像度と範囲の動的調整のために磁気流体 (MRF) を使用する新しい変形硬度トルクセンサを導入します. 革新的な設計により,高精度で,要求の高いトルク測定アプリケーションに適応できます.
科学分野:
- 機械工学
- センサー技術
- 材料科学
背景:
- 回転する機械におけるトルクセンサの解像度と範囲に対する要求が増加しています.
- ストレージ・ゲージベースの伝統的なトルクセンサの限界は,異なる測定条件に適応することにある.
研究 の 目的:
- 解像度と範囲を動的に調整するための新しい変形剛性トルクセンサを提示します.
- 回転する機械におけるトルク測定の厳格な要求事項に対処するためです.
- 現存するトルクセンサー技術の限界を克服する.
主な方法:
- 扭転スプリングと磁気流体 (MRF) の統合により,硬さが調整できます.
- 磁場を利用して MRF 切断ストレスを変化させることで センサーの硬さも変化します
- 有限要素解析を用いた硬さモデルの開発と検証
- 非接触角度測定のためのスクルーモジュレーションベースの方法の実装.
主要な成果:
- トークセンサの解像度と範囲のダイナミックで継続的な調整の実証.
- 剛性モデルの正確性の検証
- 高度な非接触角度測定の精度を達成し,離心率の問題も解決しました.
- センサプロトタイプの優れた線形性,ヒステリシス,および再現性を示す実験評価.
結論:
- 新しい変形硬度トルクセンサは,回転する機械における適応可能な解像度と範囲の要求を効果的に満たしています.
- MRFとトルション・スプリングの組み合わせは,従来のトルクセンサに比べて重要な進歩をもたらします.
- 提案されたセンサー技術は,高精度のトルク測定アプリケーションに希望を示しています.
さらに関連する動画
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
1.8K
 07:28
A Method for Evaluating Timeliness and Accuracy of Volitional Motor Responses to Vibrotactile Stimuli
Published on: August 2, 2016
7.4K
関連する概念動画
 01:15
Torque Free Motion
564
The torque-free motion refers to the movement of a rigid body in space when no external torques are acting upon it. This type of motion can be observed in environments where there are no external forces or frictions, like in outer space. For example, a rotation of Mars in space is a torque-free motion. Mars is an axisymmetric object, meaning it has an axis of symmetry along which it rotates, designated as the z-axis. The rotating frame of reference is defined such that the center of mass of...
564
 01:10
Residual Stresses in Circular Shafts
233
In materials that exhibit elastic and plastic behavior, known as elastoplastic materials, residual stresses can accumulate when these materials experience plastic deformation. This deformation arises from either high levels of shearing stress or significant strains. Residual stresses are internal stresses that persist within a material after removing the external force causing deformation. This phenomenon is demonstrated when observing the behavior of a shaft under torque; notably, the...
233
 01:18
Stresses in a Shaft
503
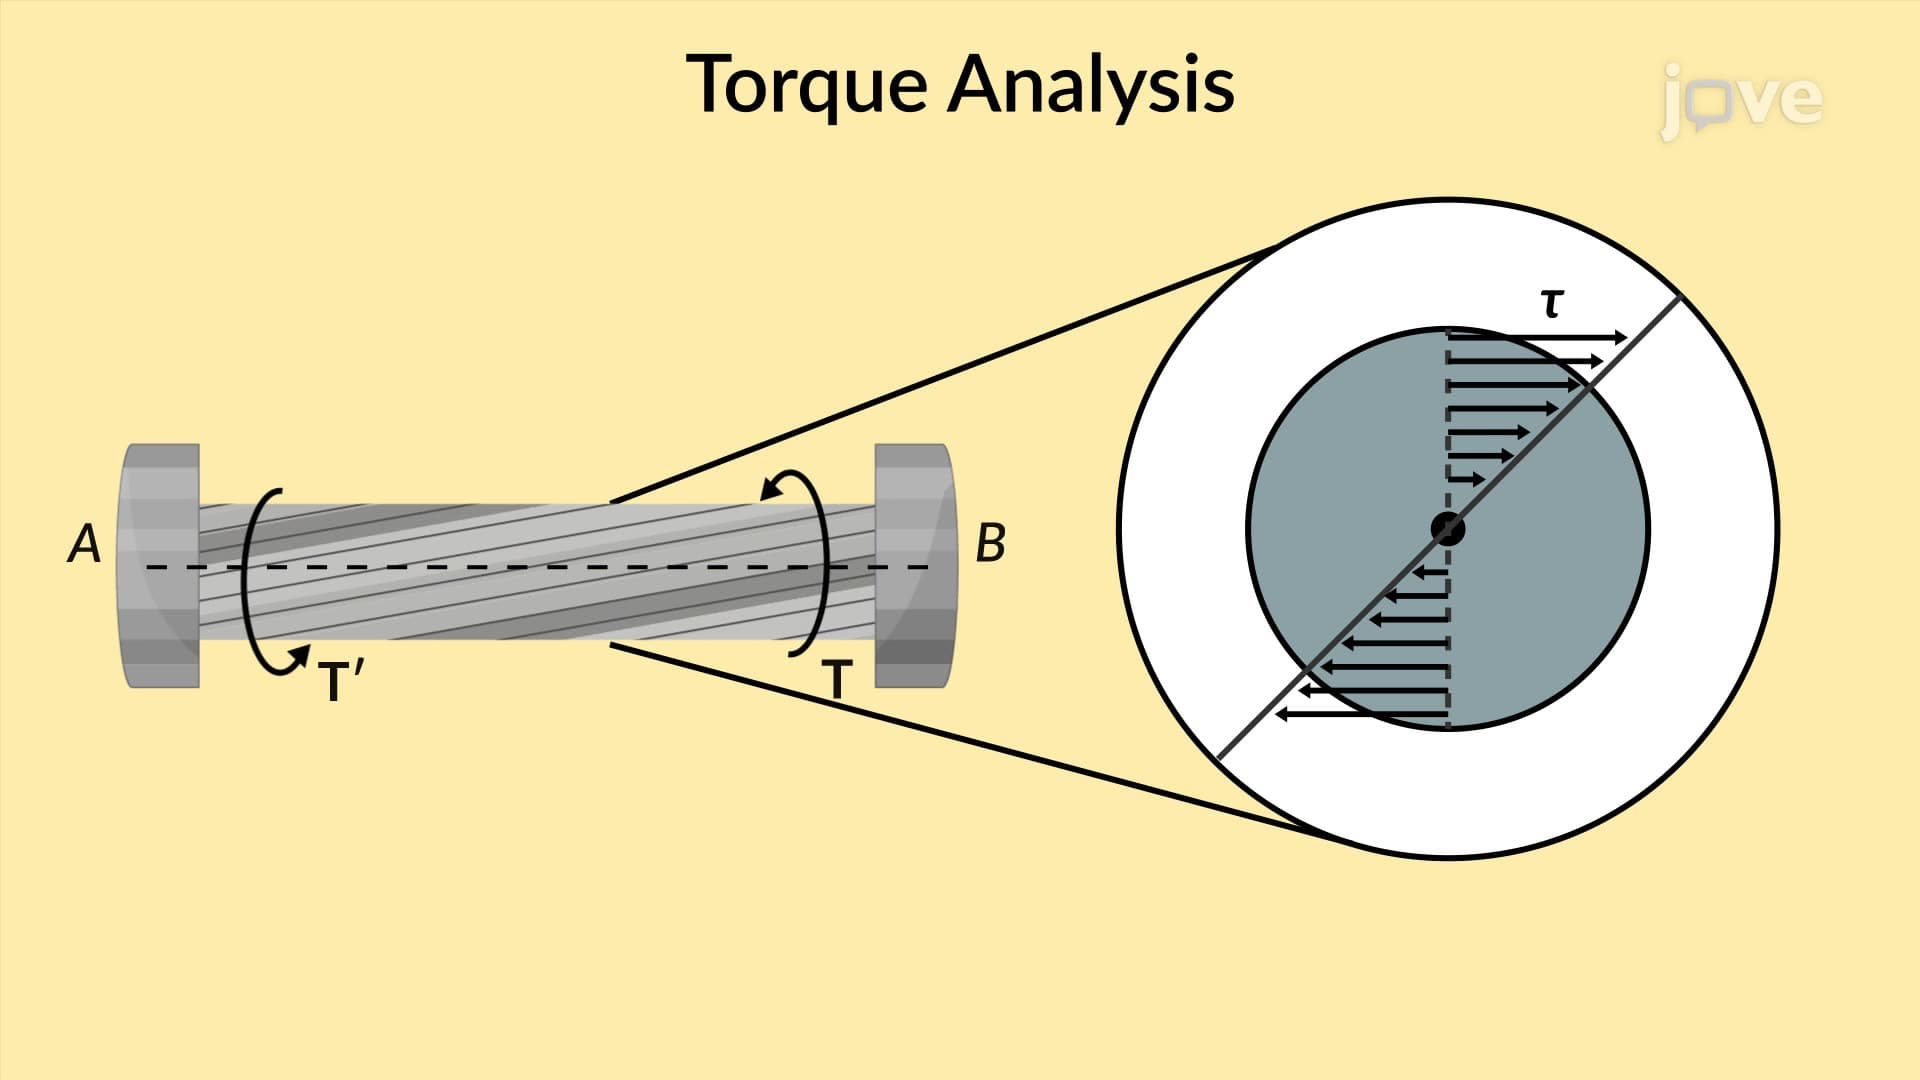
The shaft PQ is subjected to a twisting force when equal and opposite torques are applied on either side. A section that cuts perpendicular to the shaft's axis at any arbitrary point R is examined to understand this. When the free-body diagram of the QR segment is analyzed, it reveals the shearing forces exerted by the PR portion onto the QR segment as the shaft experiences twisting.
Applying equilibrium conditions to the QR segment establishes that the internal shearing forces within the...
Applying equilibrium conditions to the QR segment establishes that the internal shearing forces within the...
503
 01:13
Circular Shaft - Stresses in Linear Range
356
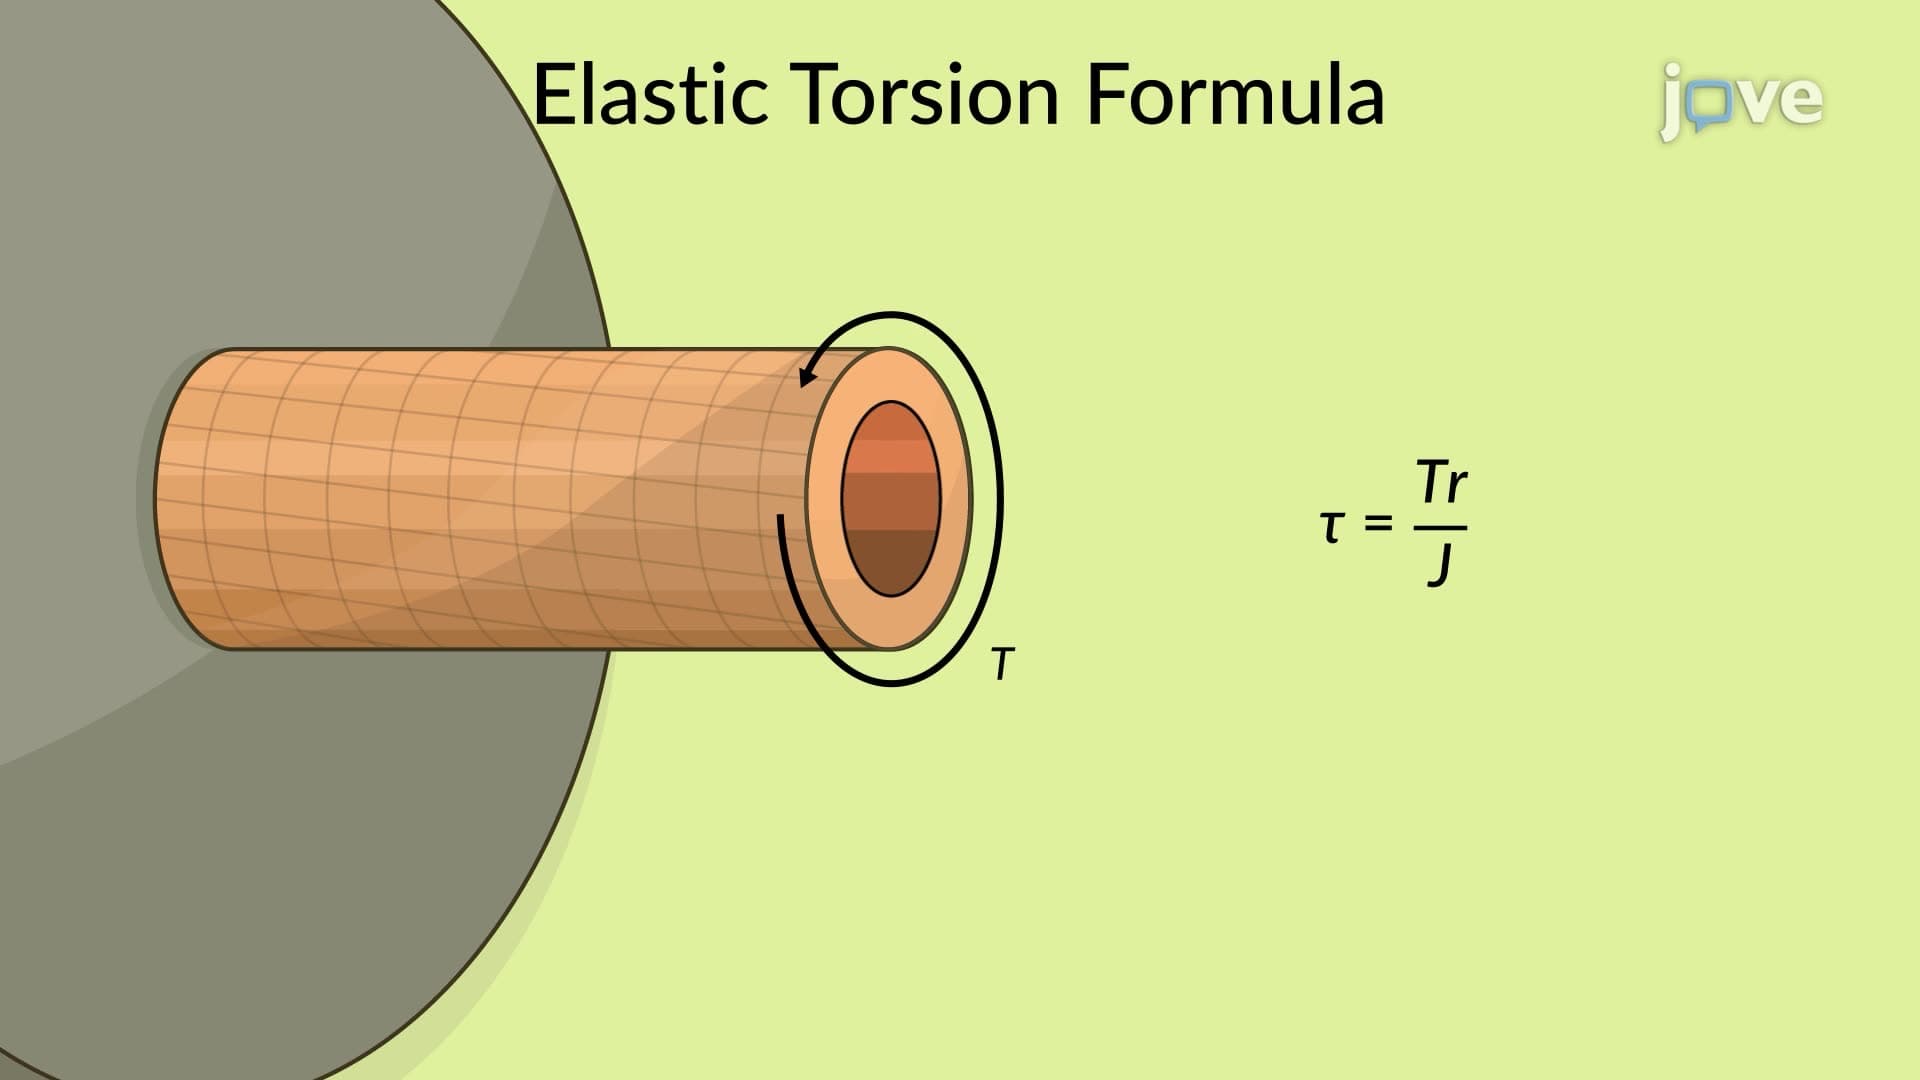
Consider a scenario where a circular shaft is subject to torque that remains within the boundaries of Hooke's Law, avoiding any permanent deformation. So, the formula for shearing strain is revisited. This formula is multiplied by the modulus of rigidity, and then Hooke's Law for the shearing stress and strain is applied. As a result, the equation for shearing stress in a shaft can be derived.
356
 01:10
Deformation in a Circular Shaft
441
One of the distinctive characteristics of circular shafts is their ability to maintain their cross-sectional integrity under torsion. In other words, each cross-section continues to exist as a flat, unaltered entity, simply rotating like a solid, rigid slab. To understand the distribution of shearing stress within such a shaft, consider a cylindrical section inside this circular shaft. This section has a length of L and a radius of R, with one end fixed. The radius of the cylindrical section is...
441
 01:19
Net Torque Calculations
9.6K
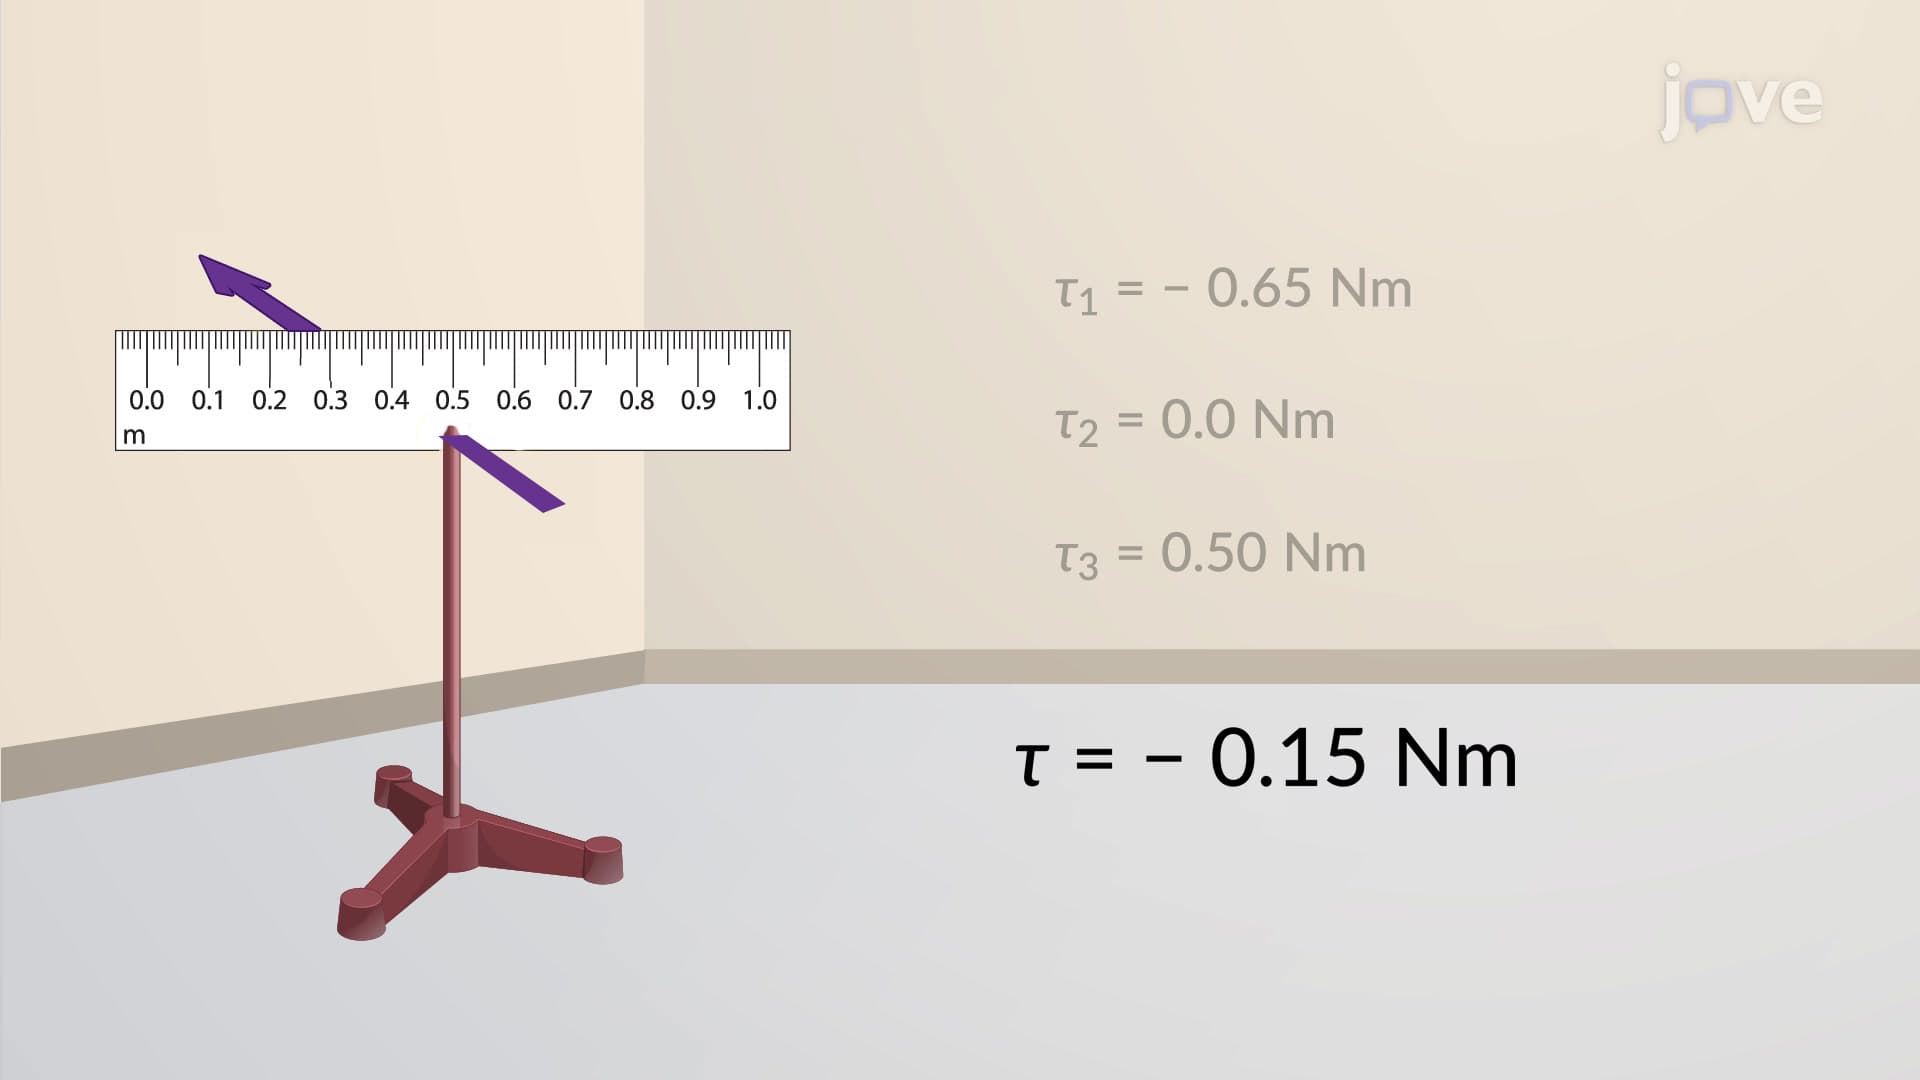
When a mechanic tries to remove a hex nut with a wrench, it is easier if the force is applied at the farthest end of the wrench handle. The lever arm is the distance from the pivot point (the hex nut in this case) to the person’s hand. If this distance is large, the torque is higher. Only the component of the force perpendicular to the lever arm contributes to the torque. Therefore, pushing the wrench perpendicular to the lever arm is more advantageous. If multiple people apply force to...
9.6K